 +1 credit
| Version | Summary | Created by | Modification | Content Size | Created at | Operation |
|---|---|---|---|---|---|---|
| 1 | Ahmed M. Hala | -- | 1044 | 2025-09-18 01:13:50 | | | |
| 2 | Ahmed M. Hala | + 5 word(s) | 1049 | 2025-09-19 18:14:04 | | | | |
| 3 | Ahmed M. Hala | + 260 word(s) | 1309 | 2025-09-22 20:21:52 | | | | |
| 4 | Ahmed M. Hala | -71 word(s) | 1238 | 2025-09-23 09:47:34 | | | | |
| 5 | Catherine Yang | Meta information modification | 1238 | 2025-09-23 10:49:56 | | | | |
| 6 | Ahmed M. Hala | + 165 word(s) | 1403 | 2026-01-03 12:30:05 | | | | |
| 7 | Ahmed M. Hala | + 1 word(s) | 1404 | 2026-02-11 18:03:32 | | | | |
| 8 | Ahmed M. Hala | Meta information modification | 1404 | 2026-03-07 16:12:15 | | | | |
| 9 | Ahmed M. Hala | Meta information modification | 1404 | 2026-03-07 18:06:42 | | | | |
| 10 | Ahmed M. Hala | + 177 word(s) | 1581 | 2026-04-14 12:50:32 | | | | |
| 11 | Ahmed M. Hala | + 11 word(s) | 1592 | 2026-05-08 17:15:25 | | | | |
| 12 | Ahmed M. Hala | + 218 word(s) | 1810 | 2026-05-16 17:07:41 | | | | |
| 13 | Ahmed M. Hala | + 699 word(s) | 2509 | 2026-07-23 16:10:40 | | | | |
| 14 | Ahmed M. Hala | + 741 word(s) | 3250 | 2026-07-28 19:15:13 | | | | |
| 15 | Ahmed M. Hala | + 388 word(s) | 3638 | 2026-07-30 01:12:33 | | | | |
| 16 | Ahmed M. Hala | Meta information modification | 3638 | 2026-07-30 21:05:09 | | | | |
| 17 | Ahmed M. Hala | + 820 word(s) | 4458 | 2026-07-31 19:52:46 | | | | |
| 18 | Ahmed M. Hala | + 552 word(s) | 5010 | 2026-07-31 21:13:50 | | | | |
| 19 | Ahmed M. Hala | + 51 word(s) | 5061 | 2026-09-07 11:37:57 | | | | |
| 20 | Ahmed M. Hala | + 11 word(s) | 5072 | 2026-10-05 03:16:14 | | | | |
| 21 | Ahmed M. Hala | + 91 word(s) | 4108 | 2026-11-14 16:38:40 | | | | |
| 22 | Ahmed M. Hala | Meta information modification | 4108 | 2026-11-14 17:33:38 | | | | |
| 23 | Ahmed M. Hala | + 277 word(s) | 4385 | 2026-11-14 23:04:49 | | | | |
| 24 | Ahmed M. Hala | Meta information modification | 4385 | 2026-11-14 23:39:10 | | | | |
| 25 | Ahmed M. Hala | Meta information modification | 4385 | 2026-11-14 23:42:14 | | |
Video Upload Options
The Hala Attractor Chaotic System
EditThe Hala Attractor Chaotic System is a Lorenz-type flow whose z-equation carries a state-dependent cubic feedback term, the Hala operator H = −γ(x² + y²)z. The operator acts from inside the vector field. A single quench factor γ takes the system from chaos to a stable fixed point and then, past a fold at γ = 1/54, to unbounded growth. Lifted out of its Lorenz host, the same operator has been applied to eleven benchmark chaotic systems, where the outcome depends on the host: fixed point, limit cycle, or loss of boundedness. Three control protocols are built on it. Successive Controlled Collapse discretises a trajectory irreversibly. Deferral by periodic modulation (“topological braiding”) postpones collapse. Collapse-and-release returns the Lorenz host to its attractor. This entry gives the definitions, the threshold structure in closed form, recomputed reference figures, the host survey, and the current limits of the evidence in plasma physics and gaseous electronics. The Hala Attractor Chaotic System was developed by Dr. Ahmed M. Hala (الدكتور أحمد معتوق حلا) of Gaseous electronics LLC (www.gaselco.com).
1. Introduction
The Hala attractor was introduced in August 2025 as a Lorenz-like system in which the degree of chaos is a tunable quantity, not a fixed property [1]. Two companion studies followed in the same month. One adds a dissipation parameter and periodic forcing to connect dissipative and volume-preserving regimes [2]. The other relates the model to Langmuir-probe current–voltage traces from a quiescent multidipole plasma [3].
The plasma motivation is older than the model. A 2020 letter read chaos from probe I–V characteristics through a discrete recurrence fitted to the electron-saturation region [4], and a 2025 preprint developed the electric probe as an instrument for that purpose [5]. A recurrence obtained by discretising a one-dimensional I–V curve is a property of the chosen discretisation. It is not by itself evidence of chaos in the plasma, and the entry treats it as motivation only.
Since January 2026 the feedback term has been studied as an operator in its own right, separate from the Lorenz host. The body of work now has seven layers: precursors, the attractor, the operator, control protocols, a log-frequency extension, applications, and methods for auditing claims. This entry covers the first four in detail and summarises the rest.
2. Definition of the system
The host is the Lorenz system [6] with the Hala operator added to the z-equation:
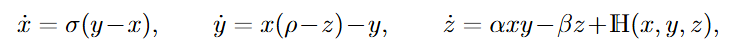
Where the Hala operator is defined as:
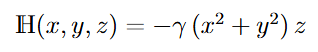
The reference parameters are σ = 10, ρ = 28, α = 1, β = 8/3, and γ ≥ 0 is the quench factor. Three properties follow directly [7].
- The origin is untouched. The operator is cubic, so the linearisation at the origin is that of the Lorenz system for every γ.
- Contraction depends on the state. The divergence of the flow is −(σ + 1 + β) − γ(x² + y²), which is negative everywhere and largest in magnitude far from the z-axis.
- The nontrivial equilibria move outward. The equilibria C± keep y = x and z* = ρ − 1 = 27, with
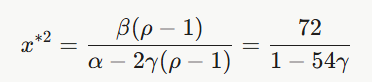
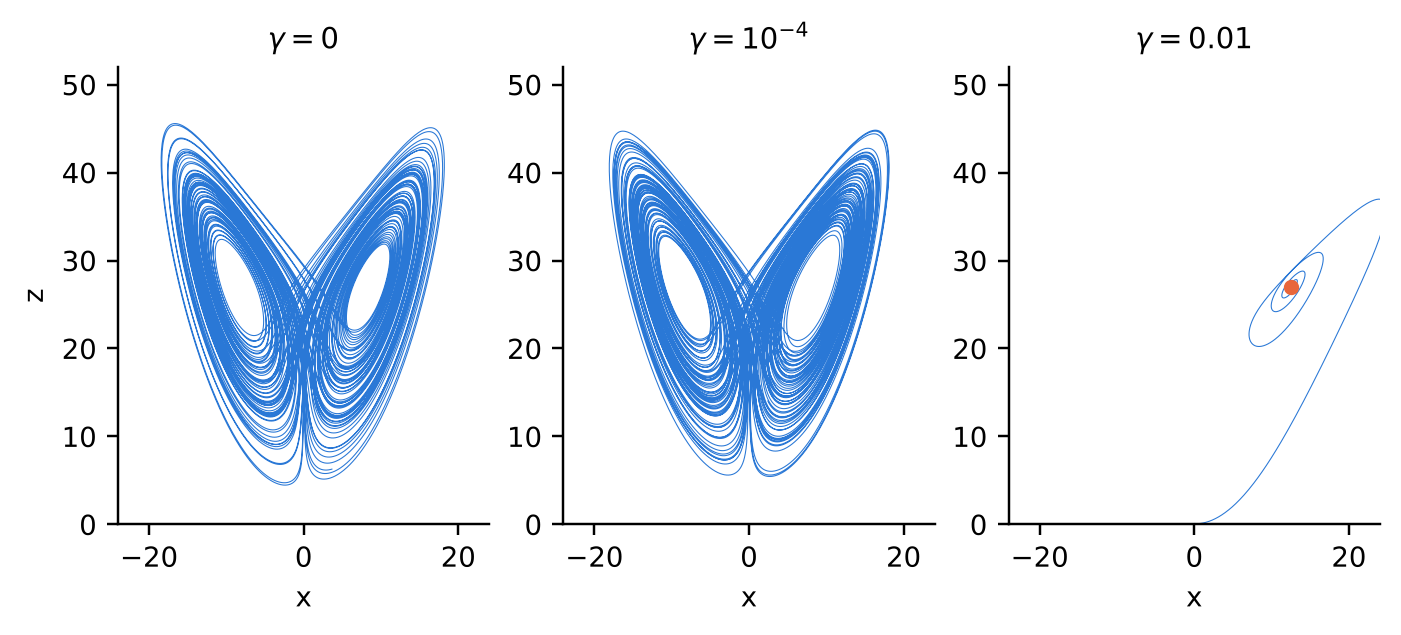
Figure 1. Phase-space projections (x, z) of the Hala attractor at three quench factors, from the initial condition (0.1, 0.1, 0.1). At γ = 0 the Lorenz attractor is recovered. At γ = 10⁻⁴ the attractor is visually unchanged. At γ = 0.01 the trajectory spirals into the stable equilibrium C+ (marked), where the largest Lyapunov exponent is −1.23.
A modified formulation adds a dissipation parameter δ and external periodic forcing [2]. As δ tends to zero the phase-space volume is preserved while the largest Lyapunov exponent stays positive. “Hamiltonian-like” is used for that system only in this restricted sense: it means volume preservation, and no Hamiltonian structure is claimed.
3. Threshold structure
Three thresholds organise the reference system, in the order γ_H < γ_cr < γ_c. Two are known in closed form.
3.1. Hopf threshold γ_H
The equilibria C± are unstable saddle-foci at γ = 0 and become stable through a Hopf bifurcation at
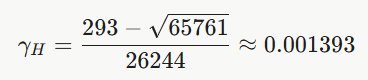
This follows from the Routh–Hurwitz condition on the Jacobian at C± [8]. At γ_H the leading eigenvalue pair is ±10.18i. Above γ_H the real part is negative: −0.027 at γ = -0.00176, −0.57 at γ = 0.0068 and −1.23 at γ = 0.01.
3.2. Boundary crisis γ_cr
Stable C± do not end the chaos at once. Between γ_H and about 0.0016 the chaotic attractor coexists with the two stable equilibria, and the largest Lyapunov exponent λ₁ stays near 0.85 (Figure 2). The attractor is then destroyed in a boundary crisis [9] [10]. Beyond it, chaos survives only as a transient whose lifetime shortens as γ grows. In an ensemble of eight initial conditions, all remained chaotic after 6000 time units at γ = 0.00164, three at γ = 0.00184, and none at γ ≥ 0.00196. A gated analysis places the canonical quench at γ_cr ≈ 0.00198 [9].
Past the crisis, λ₁ equals the real part of the leading eigenvalue at C±. A Lyapunov estimate taken without discarding the transient, or over a short window, reports a positive value well past γ_cr. The estimate must therefore state its discard time [11].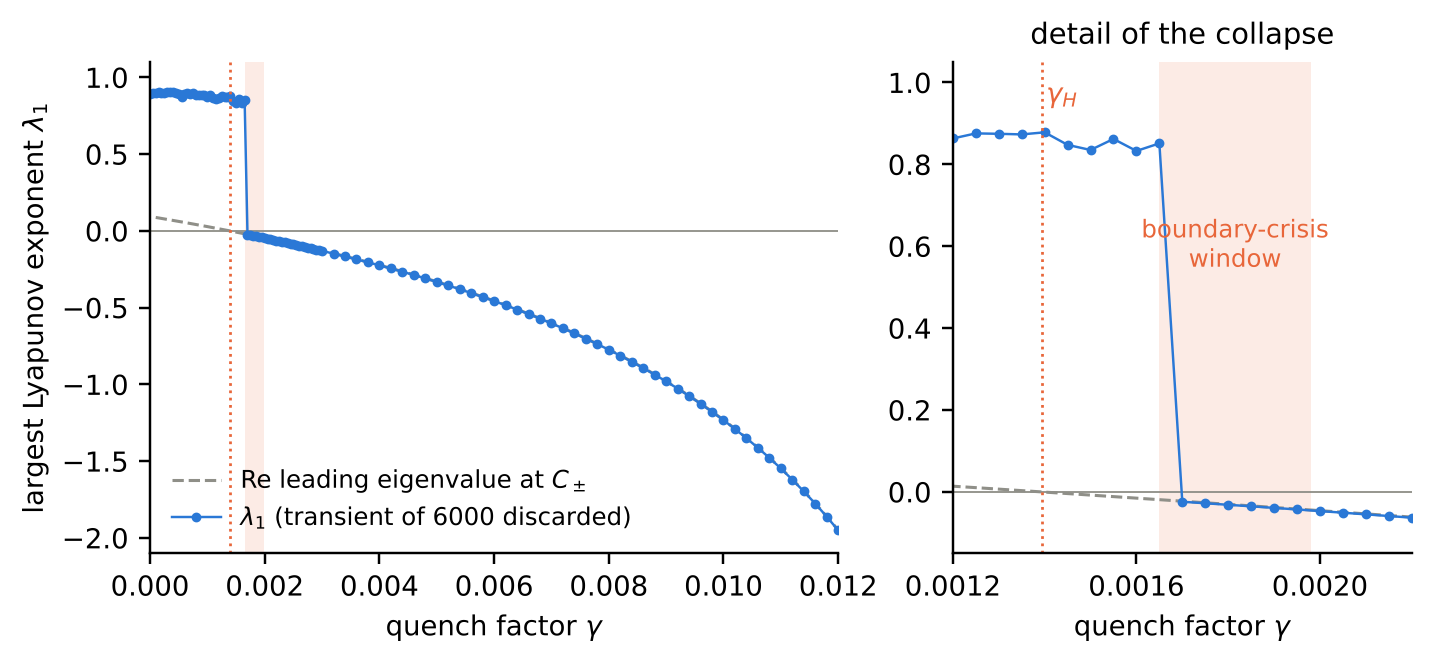
Figure 2. Largest Lyapunov exponent λ₁ against the quench factor γ for the reference system, after discarding a transient of 6000 time units and averaging over 600. Dashed line: real part of the leading eigenvalue at C±. Dotted line: Hopf threshold γ_H ≈ 0.001393. Shaded band: boundary-crisis window, 0.00165 to 0.00198, in which chaos persists only as a long transient. Right panel: detail of the collapse.
3.3. Fold γ_c
The equilibria C± recede to infinity and cease to exist at
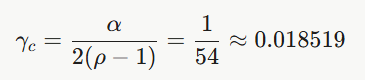
The value is independent of σ and β (Figure 3) [7]. The same construction gives γ_c = 1/(2z*) for other Lorenz-family hosts: 1/42 for the Chen system and 1/40 for the Lü system at their standard parameters.
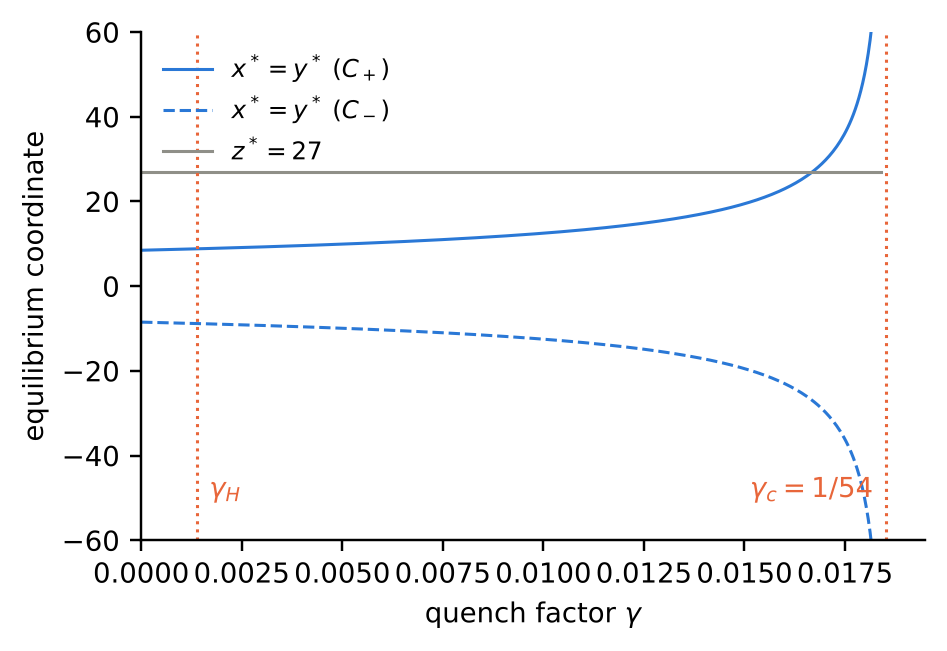
Figure 3. Continuation of the equilibria C± in the quench factor. The coordinate z* = 27 does not change. The coordinates x* = y* diverge as γ approaches the fold γ_c = 1/54. Dotted lines mark γ_H and γ_c.
3.4. Over-driving
For γ > γ_c no attracting equilibrium remains and the trajectory is unbounded. The escape is in x and y, not in z. The operator pins z to a small constant, z∞ ≈ 2.77 at γ = 0.14, so the term x(ρ − z) no longer saturates and x and y grow exponentially at a rate of about 11 per time unit (Figure 4). The calibration rule for any pulse is therefore γ_on < γ_c.
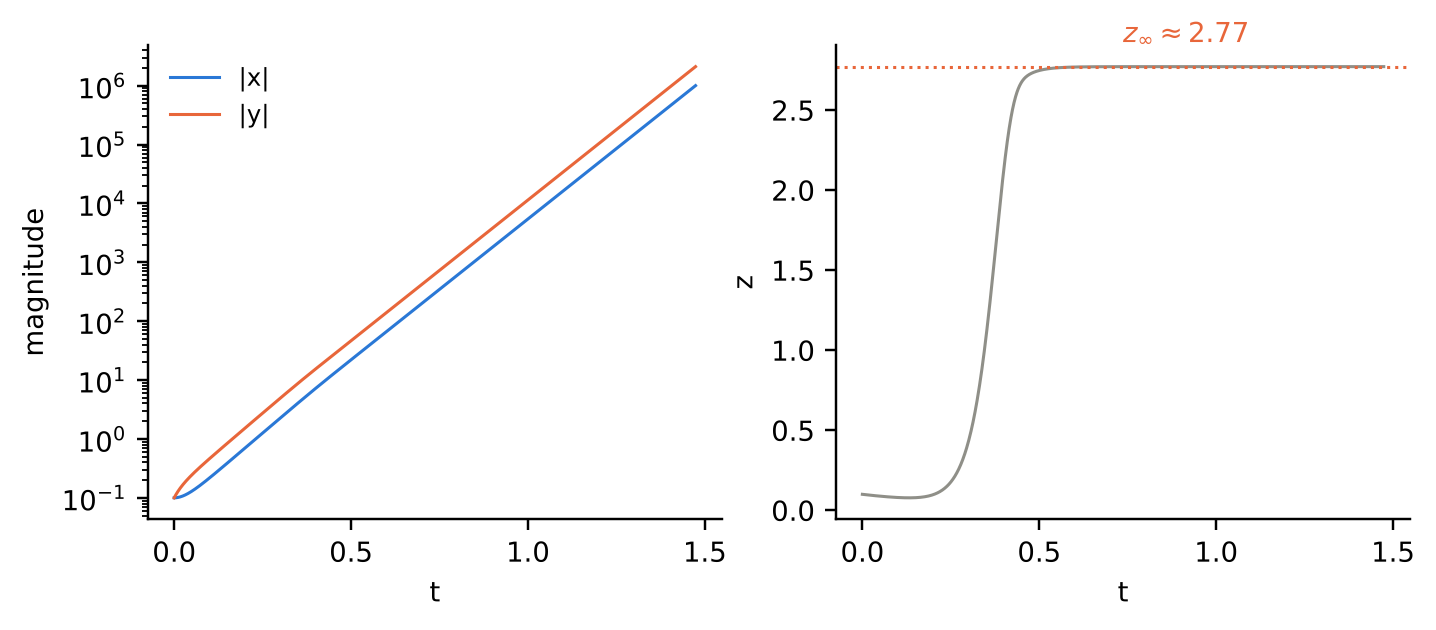
Figure 4. Over-driven case, γ = 0.14, well above γ_c. Left: |x| and |y| grow exponentially, reaching 10⁶ by t ≈ 1.5. Right: z settles on the constant z∞ ≈ 2.77.
4. The Hala operator on other hosts
In January 2026 the feedback term was separated from the Lorenz system and applied to the Sprott A flow [12]. For a three-dimensional autonomous host with state (x₁, x₂, x₃), the operator on axis k is
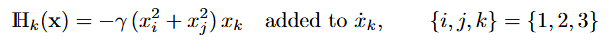
Here “host” means the mathematical system that carries the operator; it does not mean a physical device. The operator has been surveyed on eleven benchmark hosts [13] [14] : Lorenz, Chen [15], Lü [16], Dadras, Thomas, Lorenz-84, Sprott A [17] (the Nosé–Hoover oscillator [18] [19]), Aizawa, Halvorsen, Rössler and Rabinovich–Fabrikant.
The outcome is specific to the host (Figures 5 and 6, Table 1). With the operator on the z-equation, four patterns appear.
- Fixed point, then loss of boundedness. Lorenz, Chen, Lü and Dadras reach a stable equilibrium in a finite window of γ and become unbounded above it. For the Lorenz family the window closes at γ_c = 1/(2z*).
- Fixed point at large γ only. Thomas and Lorenz-84 pass through periodic states and reach a fixed point only for γ of order 0.2 to 0.6. They stayed bounded up to γ = 1000.
- Limit cycle. Sprott A and Aizawa settle on periodic orbits and never reach a fixed point. Sprott A has no equilibria, so none can be stabilised. Halvorsen becomes periodic and then unbounded.
- No bounded quench. Rössler shows narrow periodic windows before it becomes unbounded. Rabinovich–Fabrikant stays chaotic until it becomes unbounded.
A negative largest Lyapunov exponent is therefore necessary for quenching but does not guarantee a fixed point. The operator's axis matters as well: the z-axis is a poor match for hosts whose instability is carried by another variable, and axis choice for Rössler, Rabinovich–Fabrikant and Halvorsen remains open.
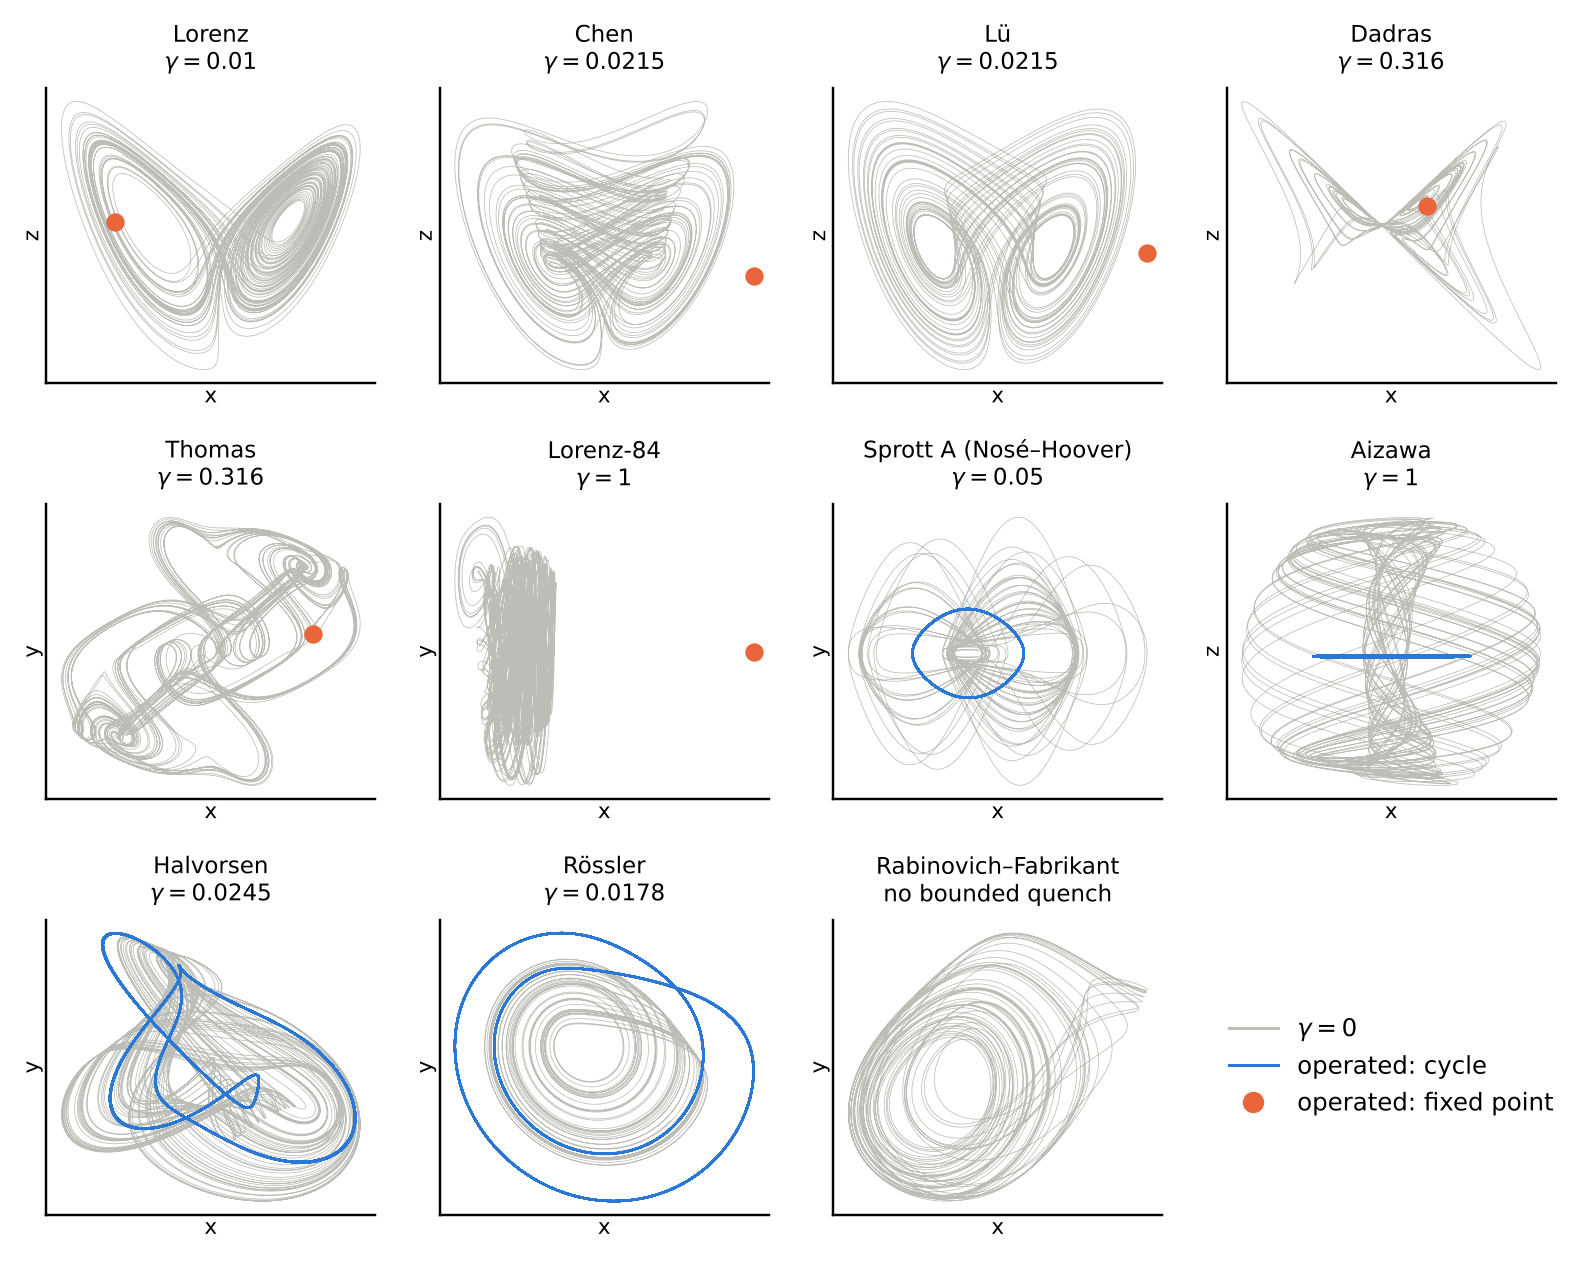
Figure 5. The Hala operator on eleven benchmark hosts. Grey: chaotic attractor at γ = 0. Blue: periodic orbit under the operator. Orange dot: fixed point under the operator. The quench factor used is given above each panel. The Aizawa cycle lies at constant z and is seen edge-on. Rabinovich–Fabrikant has no bounded quenched state with the operator on z.
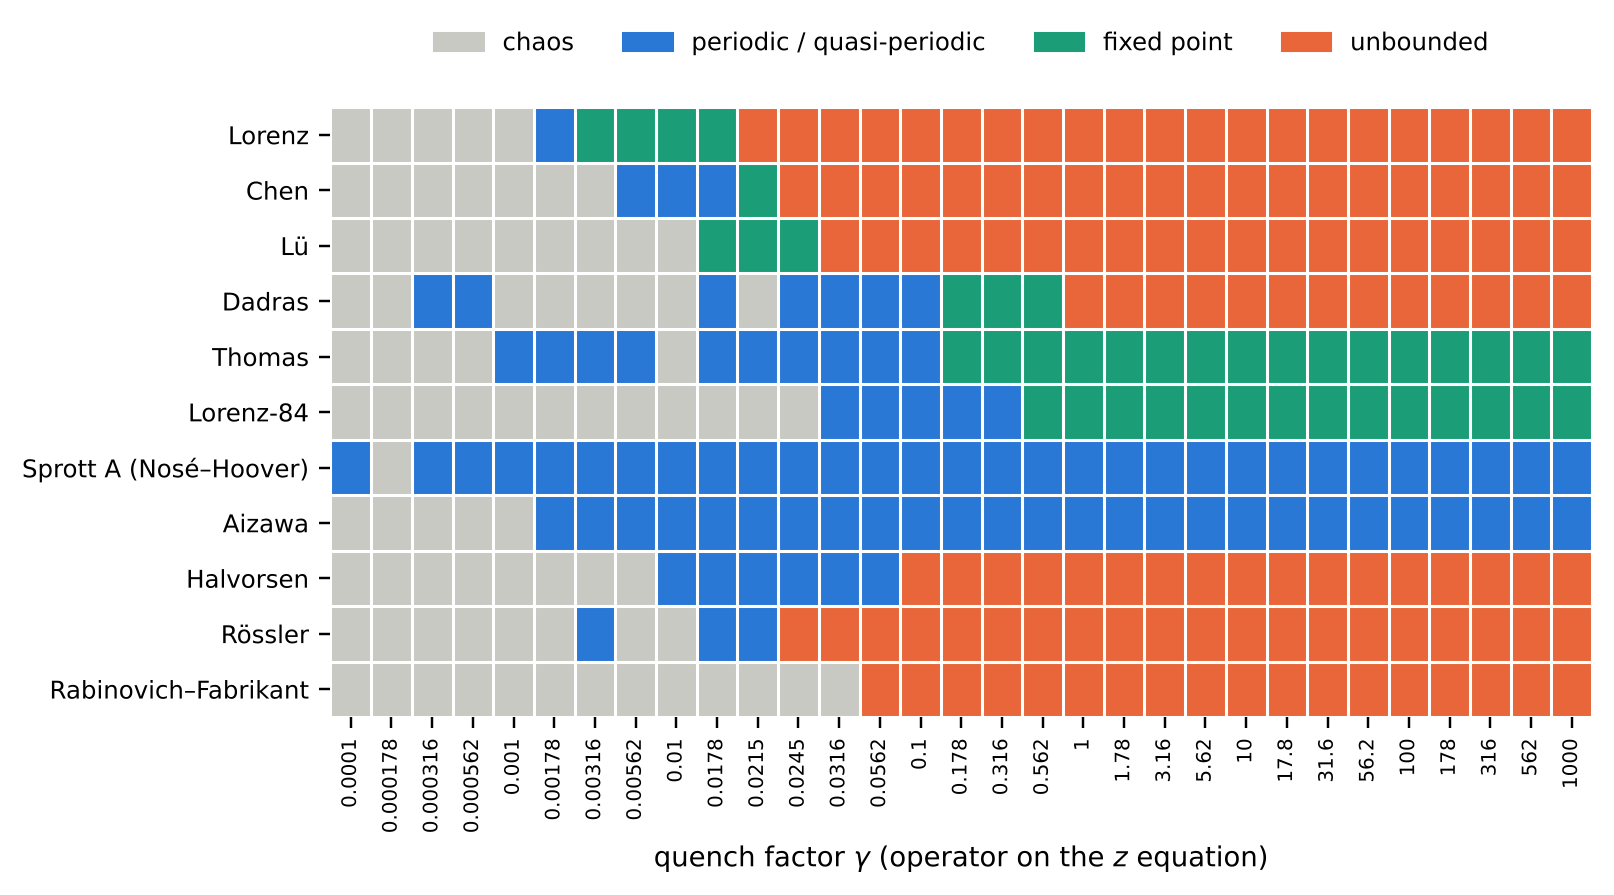
Figure 6. Long-time outcome on each host against the quench factor, operator on the z-equation, from 31 values of γ between 10⁻⁴ and 10³. Grey: chaos. Blue: periodic or quasi-periodic. Green: fixed point. Orange: unbounded.
Table 1. Outcome of the Hala operator on the z-equation of each host. Ranges are read from the grid of Figure 6 and are accurate to about a quarter of a decade.
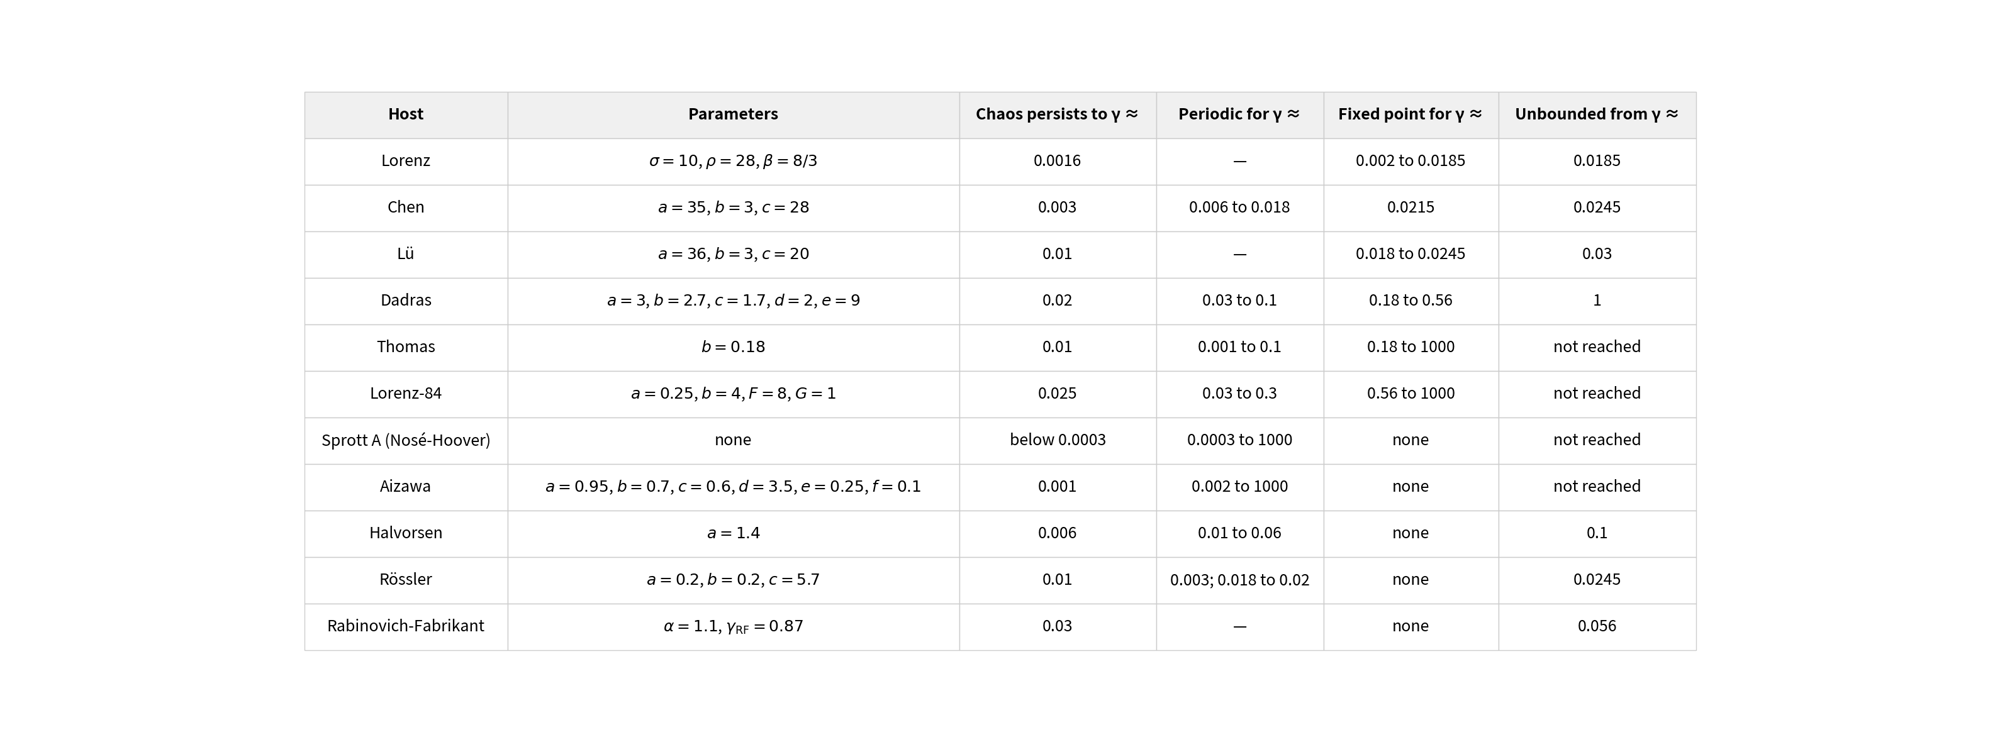
Periodic windows inside the chaotic range (Dadras, Thomas, Rössler) are listed where the grid resolved them.
5. Control protocols
Three protocols use the operator. They differ in what happens to the information carried by the trajectory: collapse discards it, deferral postpones the loss, and release returns the system to its attractor without restoring the earlier trajectory.
5.1. Irreversible: Successive Controlled Collapse (SCC)
SCC switches the operator on in pulses [20] [21] [22]. Each pulse raises γ smoothly to an amplitude γ_on < γ_c, holds it, and returns it to zero. Pulses are separated by a free-evolution interval T_free. During a pulse the trajectory contracts towards C±(γ_on); the state at the end of the pulse is the landing point.
The collapse is irreversible in a practical sense. A smooth flow is invertible at every finite time, so the map is non-injective only in the limit of long pulses or below numerical resolution. On the reference system, 50 initial conditions spread over ten units per axis converge to within 2.5 × 10⁻⁹ of C± under γ = 0.005, and backward integration from the collapsed state diverges.
Two features set the landing-point distribution (Figure 7).
- Pulse length. A pulse long enough for full collapse erases the history, so every cycle then starts from the same point and the protocol becomes exactly periodic. A spread of landing points requires incomplete collapse or non-identical timing.
- Free interval. With T_free = 5 the released trajectory has not left the neighbourhood of the equilibrium when the next pulse arrives, and every landing falls on the same point. With T_free = 50 the trajectory returns to the full attractor, and landings divide between C+ and C− (102 and 98 of 200).
As γ_on approaches γ_c the equilibria recede and the plane z = 27 becomes a slow region, because ẏ = 0 wherever y = x on it. Trajectories then linger without landing (a ghost bottleneck), which is a second reason to keep γ_on well below γ_c.
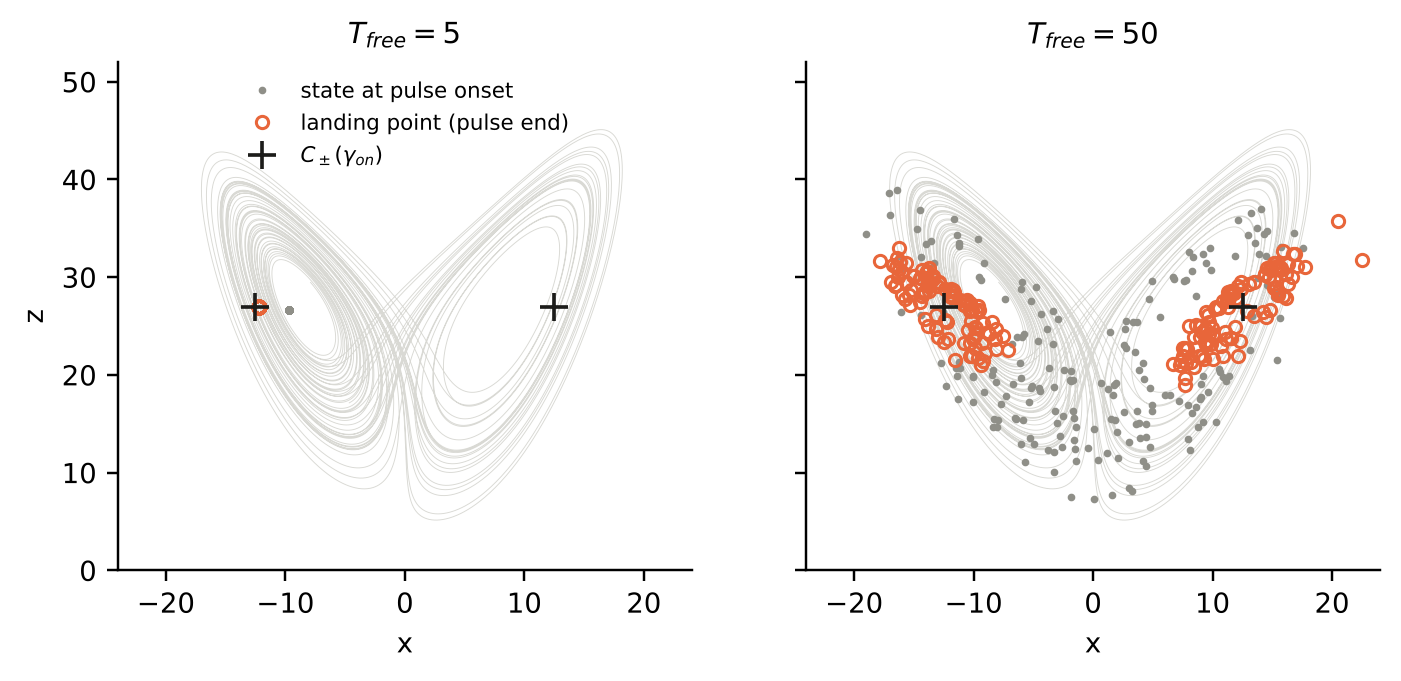
Figure 7. SCC landing points on the reference system for two free intervals, with γ_on = 0.01, pulse length 3 and sigmoid ramp width 0.25, over 200 pulses. Grey dots: state at pulse onset. Orange circles: landing point at pulse end. Crosses: C±(γ_on). Light grey: the Lorenz attractor.
The pulse ramp can be generated autonomously by making γ a fourth state variable that obeys a logistic equation, γ̇ = kγ(1 − γ/γ_target), decoupled from (x, y, z). The local growth rate lags the threshold: with k = 0.3 and γ_target = 0.01, γ crosses γ_H at t ≈ 25.6 but the growth rate stays negative only from t ≈ 32, when γ ≈ 0.006 (Figure 8).
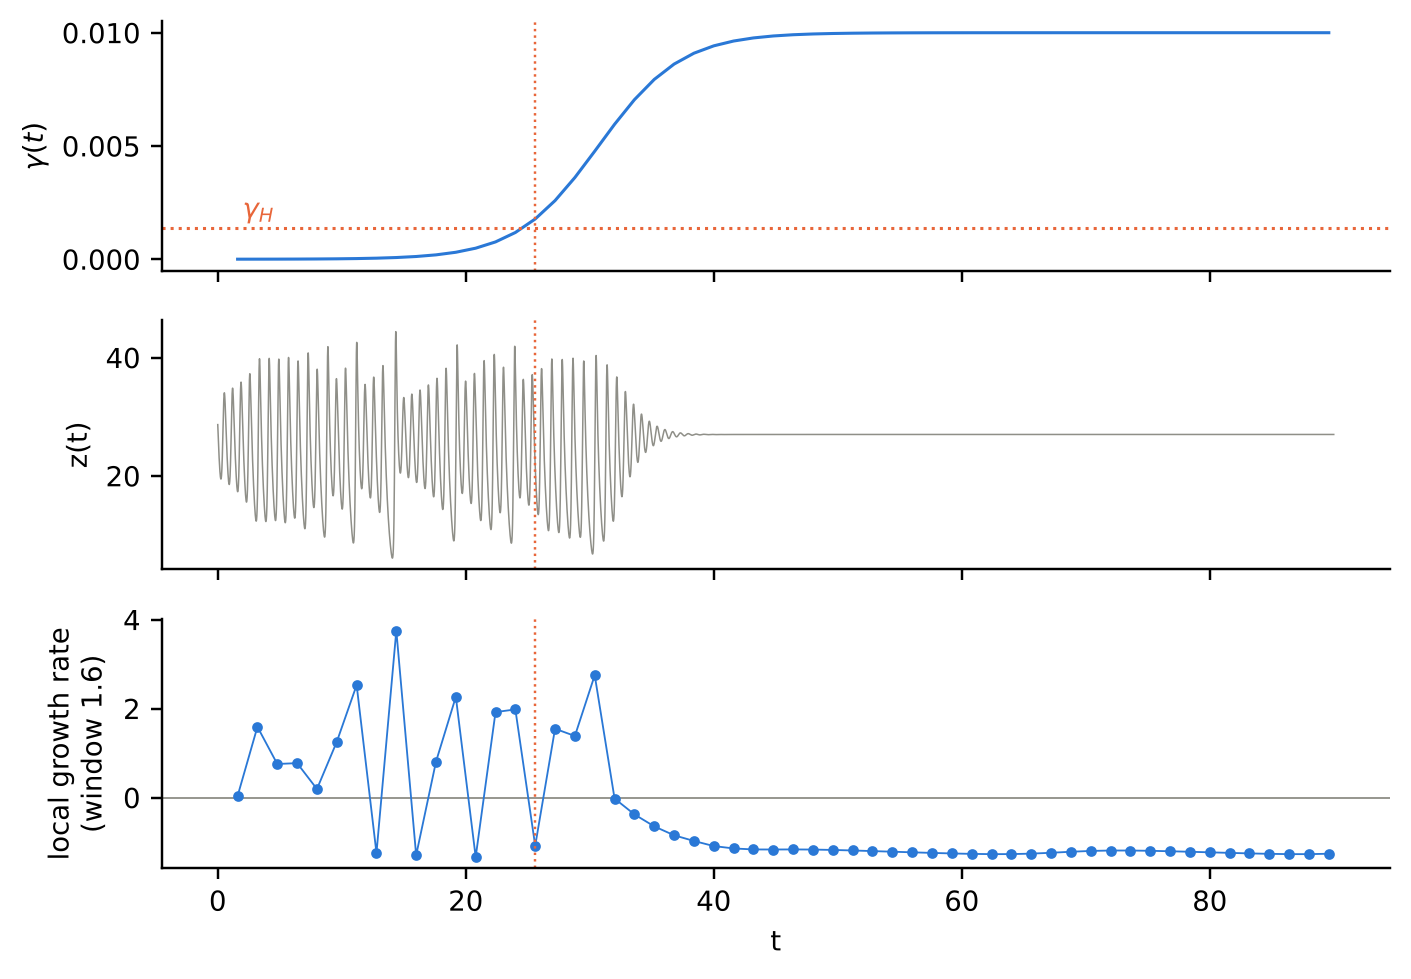
Figure 8. Autonomous logistic ramp of the quench factor on the Lorenz host: k = 0.3, γ_target = 0.01, seed γ(0) = 10⁻⁶. Top: γ(t), with γ_H marked. Middle: z(t). Bottom: local growth rate of a tangent vector over windows of 1.6 time units.
5.2. Regime reversal: collapse and release
Withdrawing the operator after a collapse lets the trajectory leave the equilibrium and return to the chaotic attractor [23]. On the Lorenz host the recovered attractor matches the original statistically: mean z of 23.4 against 23.6, and standard deviation of x of 7.85 against 7.91 (Figure 9).
The reversal applies to the regime. The trajectory after release is not the trajectory before collapse, because all initial conditions that landed on the same equilibrium share one future. The operator also removes the time-reversal symmetry of the Nosé–Hoover host: under (x, y, z, t) → (x, −y, −z, −t) the host is invariant and the operator leaves a residual 2γz(x² + y²).
On Sprott A, plain release does not restore chaos. The operator drives the trajectory onto a limit cycle that lies in a regular region of the conservative host. After release the trajectory stays on a regular orbit there, with λ₁ ≈ 0.0004 against 0.018 for the original chaotic orbit (Figure 10). Recovery on this host needs an additional expansion step, as in the Adaptive Reversible Expansion and Harmonic Anchoring scheme, which reports recovery with moderate phase slip [23].
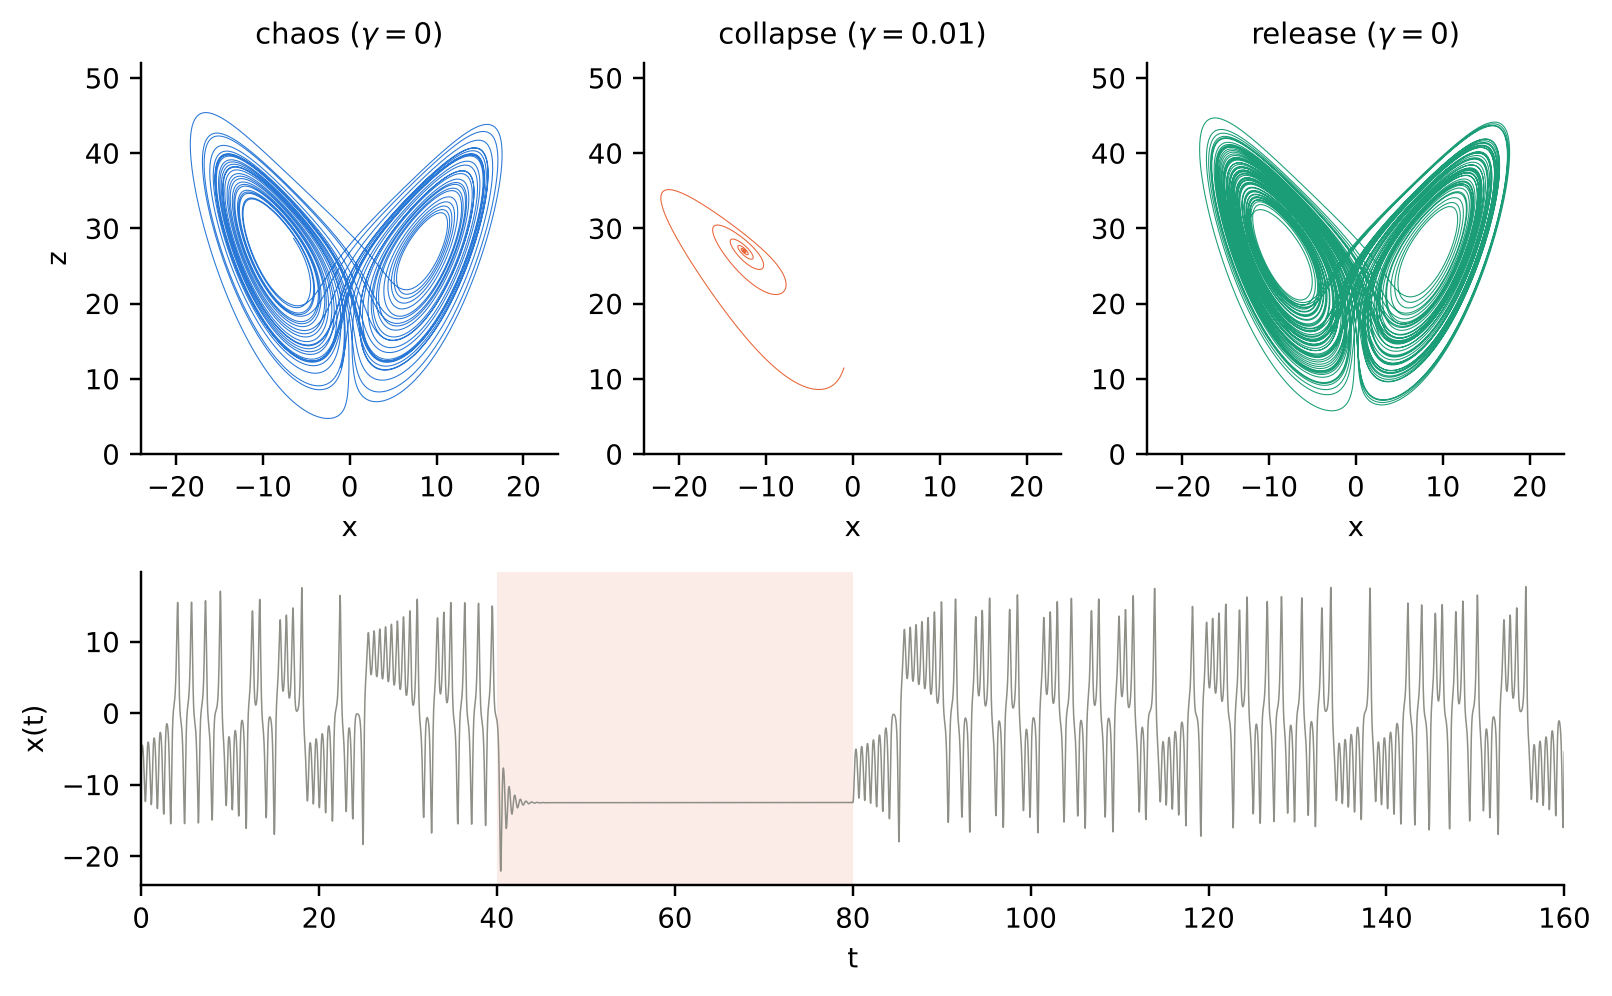
Figure 9. Collapse and release on the Lorenz host. Top: (x, z) projections during chaos (γ = 0, t < 40), collapse (γ = 0.01, 40 ≤ t < 80) and after release (γ = 0, t ≥ 80). Bottom: x(t), with the collapse interval shaded.
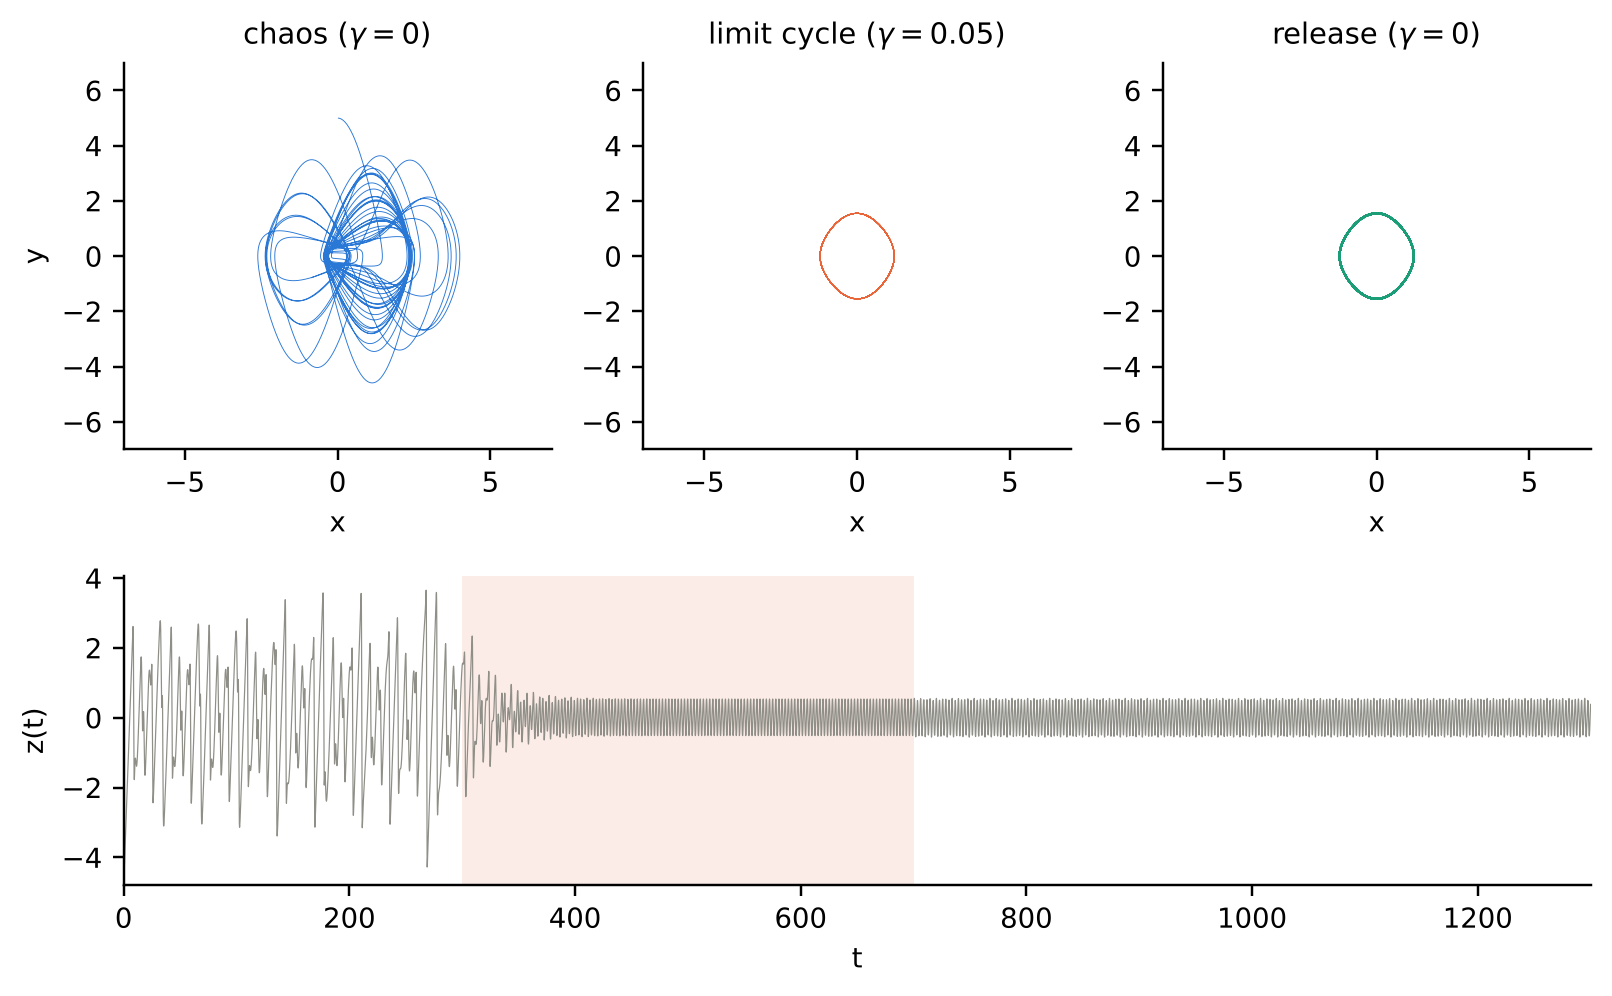
Figure 10. Collapse and release on the Sprott A host from the initial condition (0, 5, 0). Top: (x, y) projections during chaos (γ = 0, t < 300), on the limit cycle (γ = 0.05, 300 ≤ t < 700) and after release (γ = 0, t ≥ 700). Bottom: z(t), with the operator interval shaded. The released trajectory stays on a regular orbit.
5.3. Deferral: topological braiding
Deferral adds a periodic modulation that keeps restoring local instability as the operator's dissipation grows, so that collapse occurs at a larger γ [24] . The figures here use one explicit realisation, a resonant modulation of the drive parameter:
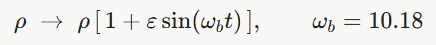
The frequency ω_b is the rotation frequency about C± at the Hopf threshold. Modulation at that frequency pumps the weakly damped spiral and ejects the trajectory from the neighbourhood of the equilibrium. The last γ with sustained chaos rises from 0.00165 at ε = 0 to 0.00235, 0.00295 and 0.0034 at ε = 0.02, 0.04 and 0.06, an extension of 42%, 79% and 106% (Figure 11).
Near the deferred collapse the chaos is intermittent. At ε = 0.04 and γ = 0.0029 the trajectory stays on one wing for up to 84 time units between bursts, against 20 for unmodulated chaos at γ = 0.0015. Past the collapse it locks onto a forced oscillation about one equilibrium (Figures 12 and 13).
On Sprott A the unmodulated operator gives a limit cycle of period 5.58 (Figure 14). Modulating the constant drive, 1 → 1 + ε sin(ω_b t) with ε = 0.3 and ω_b = 0.41, turns the cycle into a two-frequency torus with λ₁ ≈ 0 (Figure 15). Its Poincaré section is a closed curve traversed once in about 5.2 crossings (Figure 16). The modulation here restores quasi-periodicity; it does not restore chaos.
“Braiding” is used in a descriptive sense for these orbits. The braid types of periodic orbits of the Lorenz equations were classified by Birman and Williams [25]; braid words for the modulated orbits have not yet been computed.
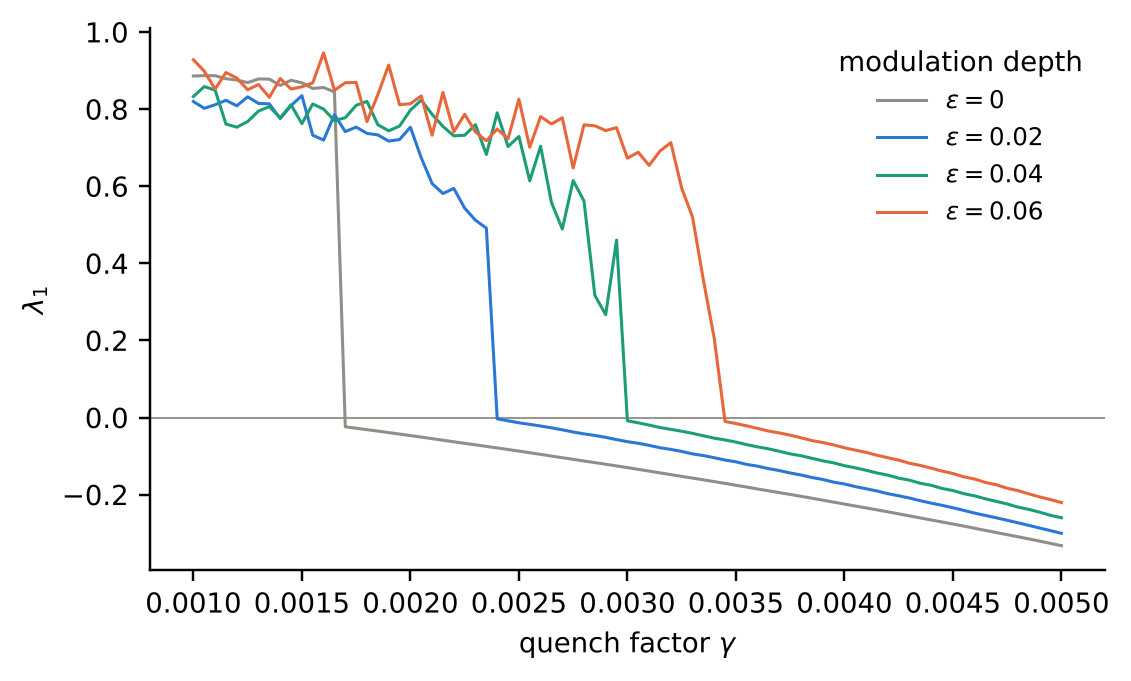
Figure 11. Largest Lyapunov exponent against the quench factor for four modulation depths ε on the Lorenz host (ω_b = 10.18; transient of 4000 discarded). The collapse moves to larger γ as ε increases.
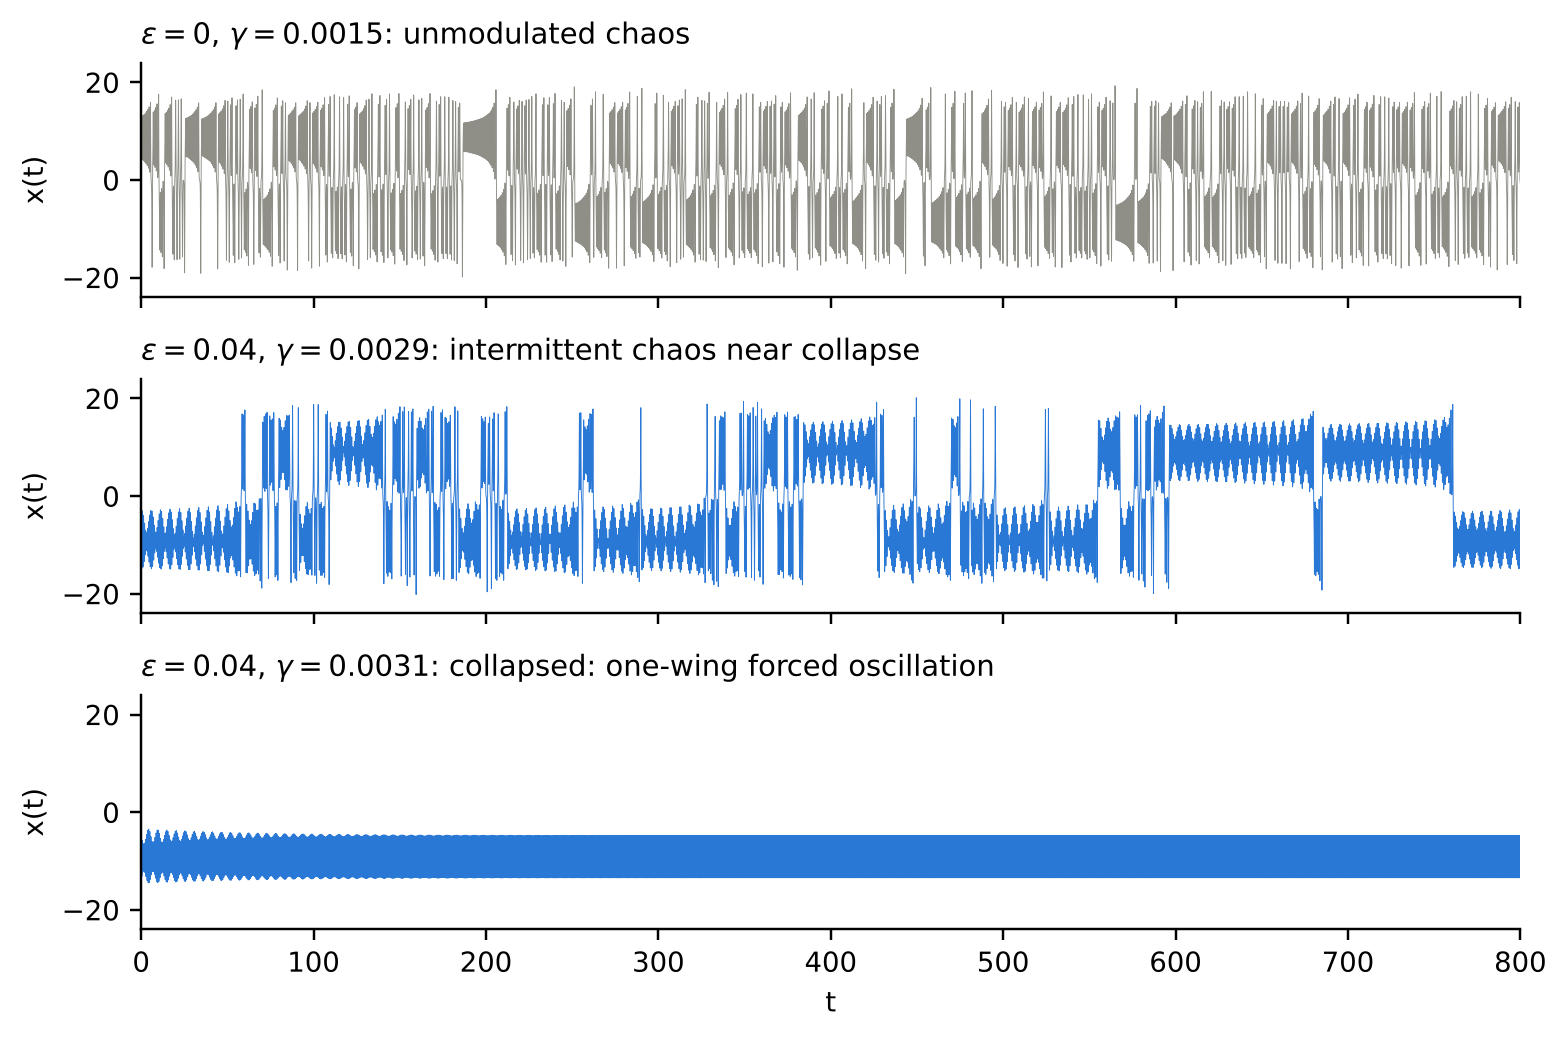
Figure 12. Time series x(t) on the Lorenz host. Top: unmodulated chaos, ε = 0, γ = 0.0015. Middle: intermittent chaos near the deferred collapse, ε = 0.04, γ = 0.0029. Bottom: past the collapse, ε = 0.04, γ = 0.0031, a forced oscillation on one wing.
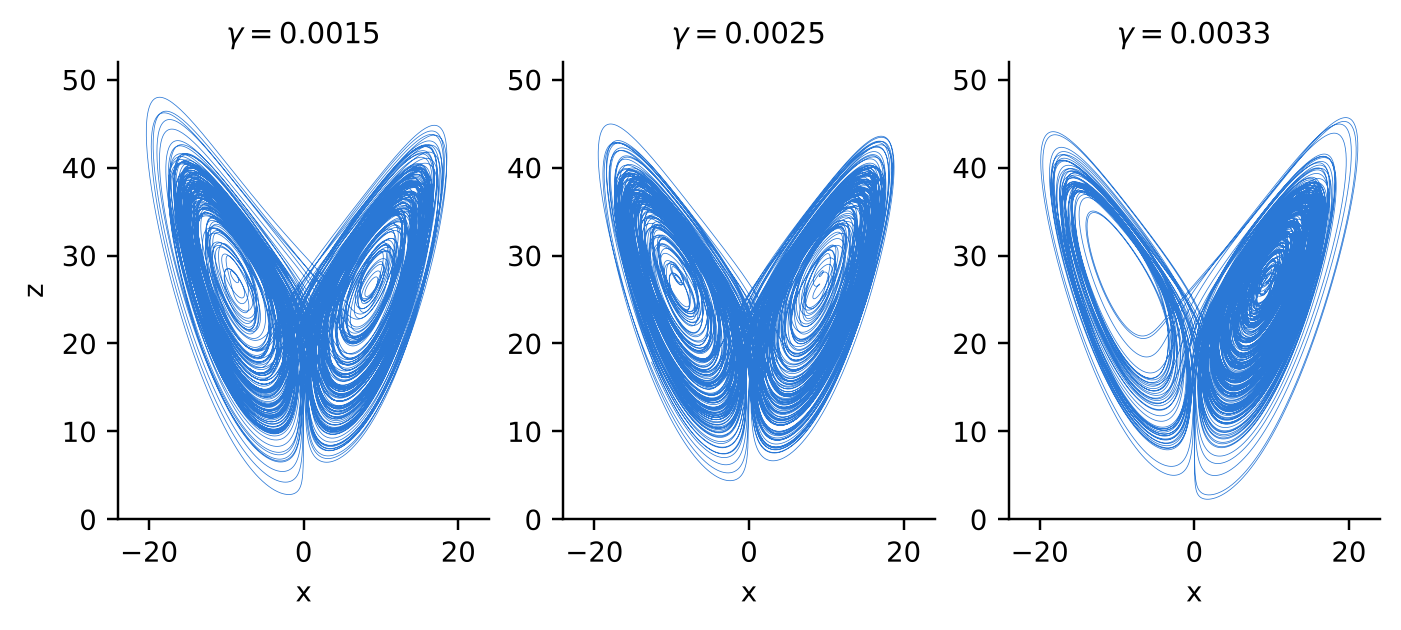
Figure 13. Modulated Lorenz host at ε = 0.06 under increasing dissipation: (x, z) projections at γ = 0.0015, 0.0025 and 0.0033, with λ₁ = 0.86, 0.83 and 0.52.
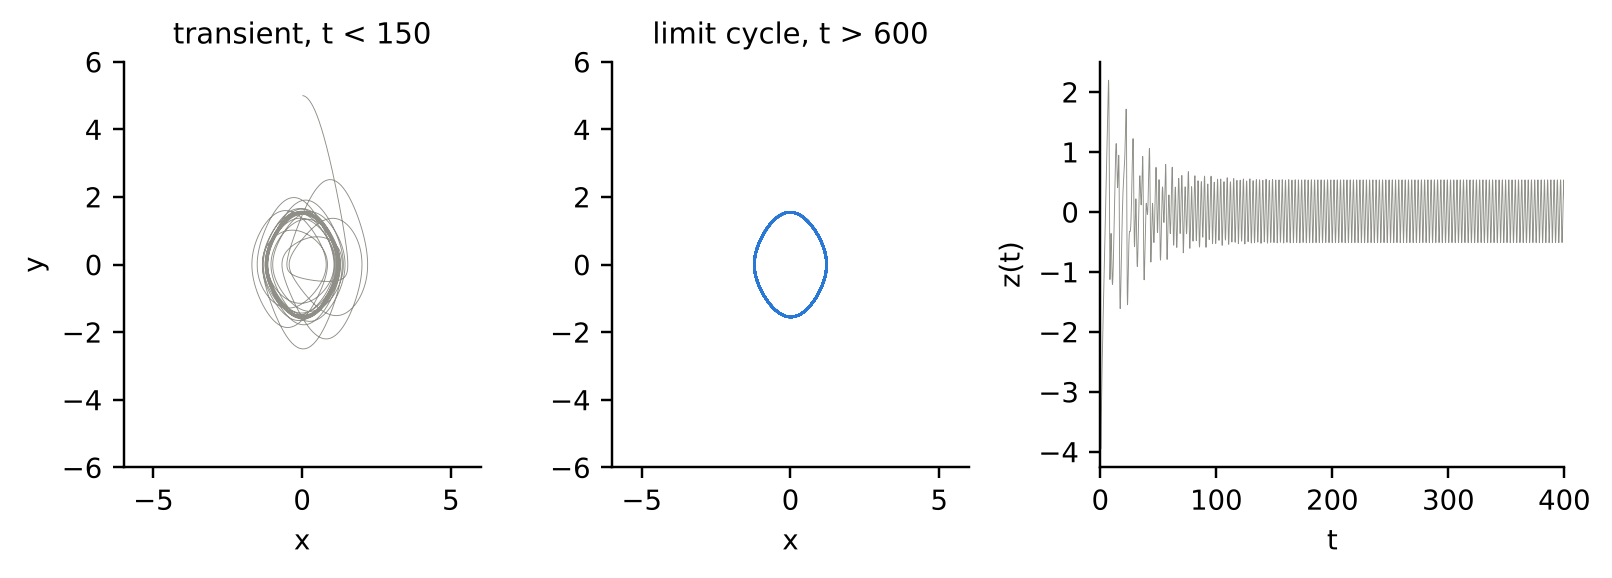
Figure 14. Sprott A under the operator alone, γ = 0.05. Left: transient in the (x, y) plane. Centre: the limit cycle. Right: z(t).
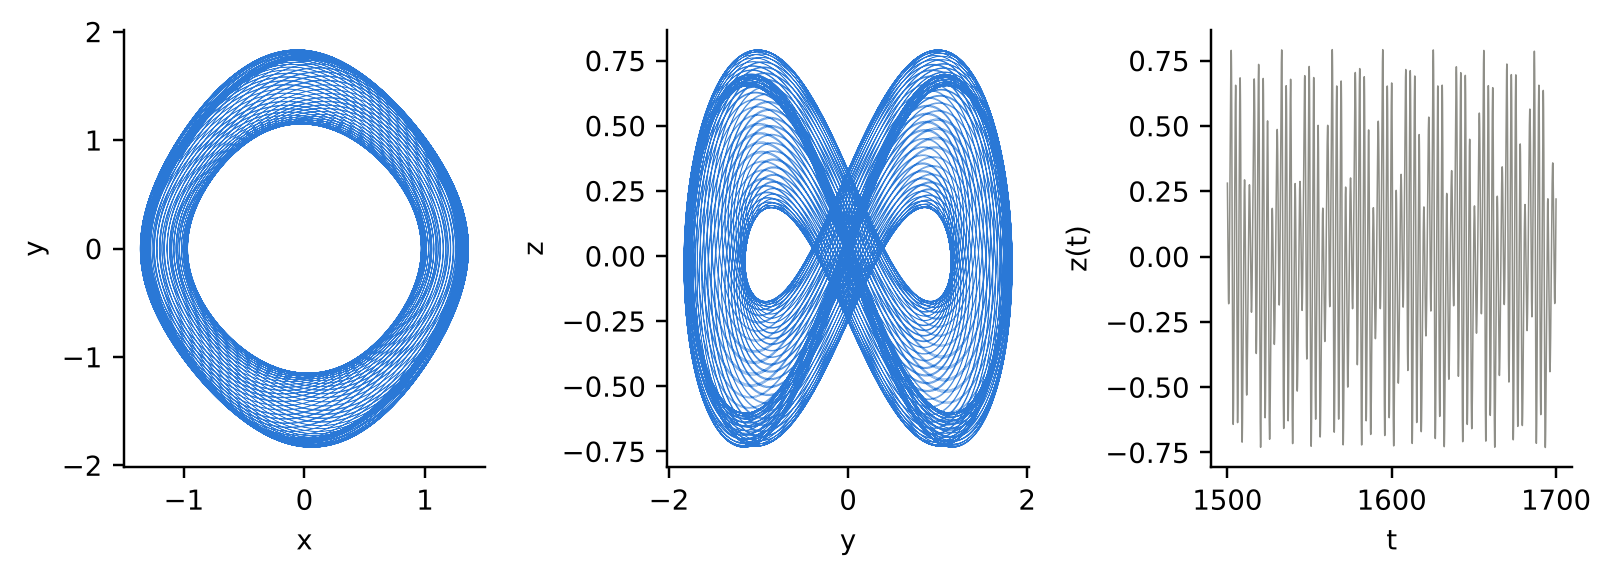 Figure 15. Sprott A under the operator and drive modulation, γ = 0.05, ε = 0.3, ω_b = 0.41: (x, y) and (y, z) projections of the torus and a segment of z(t).
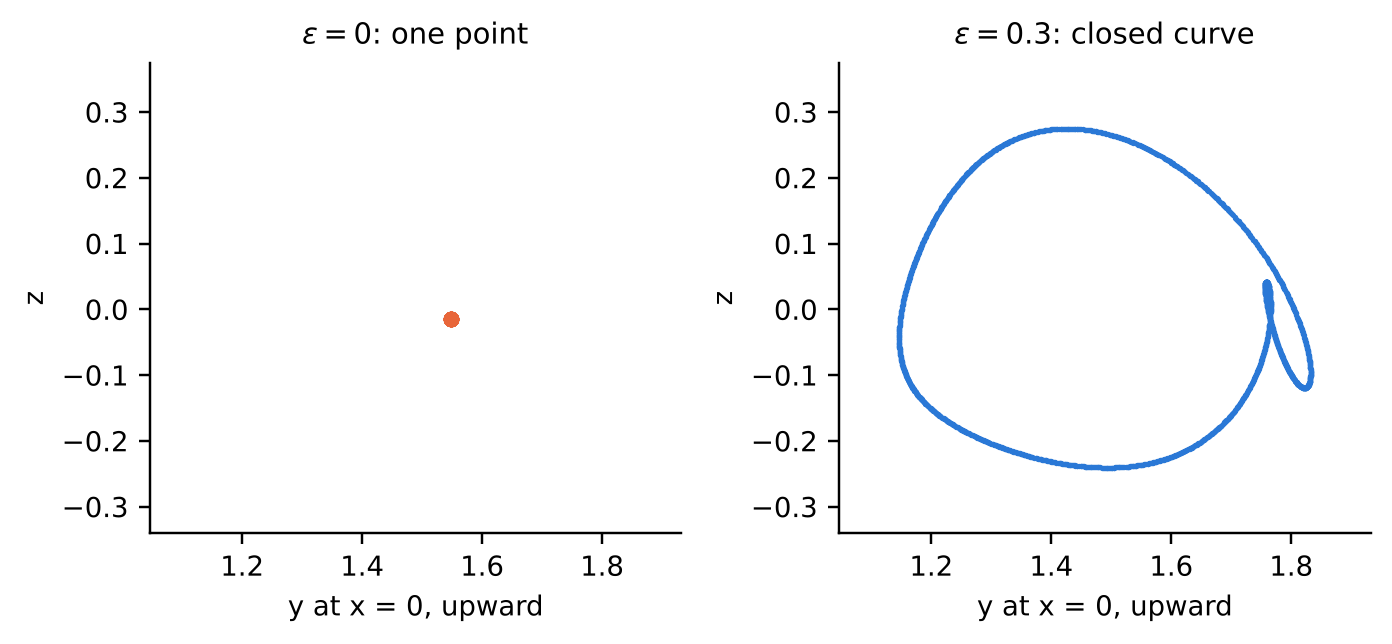
Figure 16. Poincaré sections at x = 0 with ẋ > 0 for Sprott A at γ = 0.05. Left: without modulation the limit cycle gives one point. Right: with modulation the 1878 crossings fill a closed curve.
6. Extensions
Fractional order. Replacing the time derivatives by Caputo derivatives of order q gives the fractional-order Hala system. Its equilibria are those of the integer-order system, so the Matignon stability boundary q_c(γ) is known in closed form from the Hopf thresholds: (293 − √65761)/26244 for the Lorenz host and (181 − √631)/7938 for the Chen host. Chaos has been mapped over the (γ, q) plane with a full-memory predictor–corrector scheme [8].
- Time-dependent quench factor. The quench factor may follow a waveform γ(t): linear, exponential, sigmoidal or oscillating. The landing points of SCC are reported to be insensitive to the waveform as long as the plateau stays below γ_c [21].
- Multi-axis operator. The operator can act on all three equations with separate factors (γx, γy, γz). A response-surface study on the Lorenz and Sprott A hosts found the z-direction dominant [24].
- Other lines. Later work carries the operator into a continuum analogue (a state-dependent bulk viscosity), a Nosé–Hoover–Hala host for a Lawson stability manifold, and a log-frequency reformulation of wave dispersion. These lie outside the scope of this entry.
7. Context and applications
7.1. Relation to established chaos control
The OGY method [26] and delayed feedback [27] stabilise unstable periodic orbits that already exist in the uncontrolled flow, using small perturbations that vanish on the target orbit. The Hala operator changes the vector field: it creates stability at C± and moves them. Its control effort does not vanish at the target.
Nonlinear state feedback that drives the Lorenz system to fixed points or limit cycles is an established class [28] [29] [30]. The specific contribution here is the cubic form −γ(x² + y²)z, which leaves the origin's linearisation unchanged, makes the contraction state-dependent, and yields closed-form thresholds.
7.2. Plasma physics and gaseous electronics
Chaos control in discharges has been demonstrated experimentally without a model, by small modulation of the discharge voltage in a thermionic argon discharge [31] and by feedback and synchronisation in plasma diodes, ionisation waves and drift waves [32]. A host model carrying the operator adds predicted thresholds, end states and margins before hardware is built.
To realise the operator in a device, z must be a slow, controllable variable, such as discharge current or anode bias, and x² + y² a measured fluctuation power. As an external loop this is a feedback multiplier. An internal realisation requires a physical loss channel with the same algebraic form, and that channel has to be identified for each device.
The Hala_Operator_Skill [33] packages this procedure as a method with no built-in numbers. It selects hosts by structural match to the experiment, rechecks the operator on all three axes, separates conclusions that hold on every host from host-specific ones, offers the three protocols of Section 5, and closes with a reliability audit. A pre-registered null-model study sets the acceptance rule: a result counts only if it is host-invariant, and no result on a surrogate host is claimed for a device [34]. In that study power-matched linear feedback outperformed the operator at 7 of 9 registered gains on the decisive host.
7.3. Other proposed uses
SCC has been proposed for the parametric control of fission reactors [35], for logic primitives built from Sprott A and Rössler hosts (a clock and a switch), and for secure communication and random-number generation. These proposals rest on numerical models.
8. Limitations and open questions
- Evidence is numerical. All results are from low-dimensional ordinary differential equations. No experiment has yet realised the operator in a plasma device.
- The crisis value is not closed-form. γ_H and γ_c are exact; γ_cr is numerical and depends on how long a transient is tolerated.
- Reversal is regime reversal. Collapse-and-release recovers the attractor on the Lorenz host and fails on Sprott A without an added expansion step. No protocol recovers the pre-collapse trajectory.
- Deferral is realisation-dependent. The size of the shift depends on the modulation form and frequency; at ω_b = 8 the same depths gave little or no shift.
- Braid invariants are missing. The topological description of the modulated orbits is qualitative.
- Axis selection is unresolved for Rössler, Rabinovich–Fabrikant and Halvorsen.
- Full Lyapunov spectra have not been computed for all hosts.
- A linear baseline can win. Any claim of advantage needs a power-matched linear-feedback comparison.
9. Conclusion
-
Definition. The Hala attractor is the Lorenz system with one term added to its third equation: the Hala operator H = −γ(x² + y²)z. The term is a damping on z whose strength grows with the squared distance of the state from the z-axis. A single non-negative number, the quench factor γ, sets how strong it is. At γ = 0 the system is the ordinary Lorenz system; every regime described in this entry is reached by raising γ alone.
-
What the operator does to the flow. Three structural effects follow from the form of the term. Because it is cubic in the state, it vanishes to first order at the origin, so the origin keeps exactly the stability it has in the Lorenz system. Because it multiplies z by x² + y², the rate at which phase-space volume shrinks is no longer constant: it is −(σ + 1 + β) − γ(x² + y²), fastest far from the z-axis. And the two nontrivial equilibria C± keep their height z* = ρ − 1 = 27 but move outward along the line y = x as γ grows, with x*² = 72/(1 − 54γ).
-
Threshold sequence. Raising γ takes the reference system (σ = 10, ρ = 28, β = 8/3) through four regimes in a fixed order. Below the Hopf threshold γ_H ≈ 0.001393 the equilibria C± are unstable and the motion is chaotic. Between γ_H and roughly 0.0016 the equilibria are stable but the chaotic attractor still exists alongside them. Near γ_cr ≈ 0.002 the attractor is destroyed in a boundary crisis and every trajectory eventually settles on C+ or C−. At the fold γ_c = 1/54 ≈ 0.0185 the equilibria recede to infinity, and above it trajectories are unbounded.
-
Exact and numerical results. Two of the three thresholds are exact. The Hopf threshold is γ_H = (293 − √65761)/26244, obtained from the Routh–Hurwitz condition at C±, and the fold is γ_c = α/[2(ρ − 1)] = 1/54, obtained from the condition that C± exist. The crisis value γ_cr has no closed form. Just past the crisis, chaos persists as a transient that can last thousands of time units, so the measured value depends on how long a transient the observer discards. A Lyapunov exponent computed without discarding that transient stays positive well past the true end of chaos, which is why any reported value must state its discard time.
-
Calibration rule. The quench factor must always stay below γ_c. Above the fold there is no equilibrium for the trajectory to settle on. The operator then holds z at a small constant value (about 2.77 at γ = 0.14), which removes the saturation that normally limits x and y in the Lorenz system, and x and y grow exponentially at a rate of about 11 per time unit. Applying the operator too strongly therefore produces divergence, not stronger quenching.
-
Host dependence. The term can be added to any three-dimensional chaotic system, called a host, and the result depends on the host. With the operator on the z-equation of eleven benchmark systems, four (Lorenz, Chen, Lü, Dadras) reach a stable fixed point over a bounded range of γ and diverge above it. Two (Thomas, Lorenz-84) reach a fixed point only at γ of order 0.2 to 0.6. Three (Sprott A, Aizawa, Halvorsen) settle on a periodic orbit and never reach a fixed point; Sprott A cannot, since it has no equilibria. Two (Rössler, Rabinovich–Fabrikant) have no bounded quenched state. For the Lorenz family the upper end of the fixed-point range is γ_c = 1/(2z*), where z* is the height of the host's equilibria. The operator is therefore a general construction but not a universal quench: a suppressed Lyapunov exponent does not guarantee a fixed point.
-
Irreversible collapse. Successive Controlled Collapse applies the operator in pulses separated by intervals of free chaotic motion. Each pulse contracts the trajectory onto one of the two equilibria, and the state at the end of the pulse is a landing point. The collapse discards the trajectory's history, but only in a practical sense: a smooth flow can in principle be run backward at any finite time, so the information is lost only for long pulses or below numerical precision. One consequence is that a pulse long enough for complete collapse makes every cycle start from the same point, so the protocol repeats exactly. A varied set of landing points requires incomplete collapse or irregular timing, together with a free interval long enough for the trajectory to return to the whole attractor.
-
Deferral. Deferral, called topological braiding in the source papers, adds a small periodic modulation that repeatedly pushes the trajectory away from the equilibria, so that collapse happens at a larger γ than it otherwise would. In the realisation used here the drive parameter ρ is modulated at the frequency with which trajectories spiral around C±. With modulation depths of 2%, 4% and 6% the last γ with sustained chaos rose by 42%, 79% and 106%. Just before the deferred collapse the chaos becomes intermittent, with long stretches on one wing between bursts. The effect depends on the form and frequency of the modulation; at a frequency away from the spiral frequency the same depths gave little or no shift.
-
Regime reversal. If the operator is switched off after a collapse, the Lorenz host leaves the equilibrium and returns to its chaotic attractor, with the same statistics as before. What comes back is the regime, not the earlier motion: every trajectory that collapsed onto the same equilibrium follows the same path afterward, so the state before collapse cannot be recovered. The result is also host-specific. On Sprott A the operator leaves the trajectory on a regular orbit of the underlying conservative system, and switching the operator off does not return it to chaos; an additional expansion step is needed.
-
Relation to prior work. Nonlinear state feedback that drives the Lorenz system to a fixed point or a limit cycle has been studied since the late 1990s, and the established OGY and delayed-feedback methods control chaos by stabilising orbits that already exist in the uncontrolled system. The Hala operator differs from the latter in that it changes the system itself and its control effort does not vanish at the target. Its specific contribution within the former class is the cubic form, which preserves the origin, gives closed-form thresholds, and supports the three protocols above.
-
Status in plasma physics and gaseous electronics. The system was motivated by chaos observed in discharge plasmas, where control has been demonstrated experimentally without a model. A host model carrying the operator offers predicted thresholds, end states and safety margins before hardware is built. No experiment has yet realised the operator in a device. Doing so requires three things: a slow variable the experimenter can act on, such as discharge current or anode bias, to play the role of z; a measured fluctuation power to play the role of x² + y²; and either an external feedback multiplier or an identified physical loss channel with the same algebraic form.
-
What a valid claim requires. Because outcomes differ from host to host, a result is claimable only if it holds on every host that plausibly represents the device, and a result on a surrogate model is not a result for a device. Any claim that the operator outperforms conventional control also needs a comparison against linear feedback using the same actuator power. In the one pre-registered test so far, linear feedback outperformed the operator at 7 of 9 gains on the decisive host.
-
Open work. Four items remain. A device-level test against a linear baseline would establish whether the operator has practical value in a plasma. Computing braid invariants for the modulated orbits would turn the topological description from qualitative to exact. Choosing the operator's axis for the Rössler, Rabinovich–Fabrikant and Halvorsen hosts may yield bounded quenched states that the z-axis does not. Full Lyapunov spectra across all hosts would complete the dimensional picture.
References
- Hala, A.M. The Hala Attractor: A Self-Regulating Chaotic System. HAL Open Science 2025, hal-05202097. https://hal.science/hal-05202097
- Hala, A.M. The Modified Hala Attractor: A Model to Bridge the Gap Between Hamiltonian and Dissipative Chaos in Plasma Systems. HAL Open Science 2025, hal-05203110; Preprints 2025. https://doi.org/10.20944/preprints202508.1192.v1
- Hala, A.M. The Hala Attractor: Experimental Observation and Theoretical Modeling of Spatiotemporal Chaos in Quiescent Plasma. HAL Open Science 2025, hal-05202098; Preprints 2025. https://doi.org/10.20944/preprints202508.0552.v1
- Ahmed Matouq Ahmed Hala. Qualitative Analysis of Chaotic Behaviour in a Plasma System. International Journal of Science and Qualitative Analysis. Vol. 6, No. 2, 2020, pp. 16-18. doi: https://doi.org/10.11648/j.ijsqa.20200602.11
- Hala, A.M. Electric Probes as Instruments to Examine the Chaotic Behavior in a Physical Plasma System. TechRxiv 2025. https://doi.org/10.36227/techrxiv.174063128.81289212/v1
- Lorenz, E.N. Deterministic Nonperiodic Flow. J. Atmos. Sci. 1963, 20, 130–141. https://doi.org/10.1175/1520-0469%281963%29020%3C0130:DNF%3E2.0.CO%3B2
- Hala, A.M. The Hala Attractor Revisited: Eigenstructure, Lyapunov Spectrum, and Dimension Collapse under Intrinsic Nonlinear Feedback. Zenodo 2025. https://doi.org/10.5281/zenodo.17925160
- Hala, A.M. Chaos in the Fractional-Order Hala System: Closed-Form Stability Thresholds and a Quench–Order Chaos Map. Zenodo 2026. https://doi.org/10.5281/zenodo.24085697
- Hala, A.M. Boundary Crisis, Chaotic Saddles, and Measure Constraints in State-Dependent Feedback Control of Chaotic Flows: A Gated Analysis of the Hala Operator. Zenodo 2026. https://doi.org/10.5281/zenodo.21782855
- Grebogi, C.; Ott, E.; Yorke, J.A. Crises, Sudden Changes in Chaotic Attractors, and Transient Chaos. Physica D 1983, 7, 181–200. https://doi.org/10.1016/0167-2789%2883%2990126-4
- Benettin, G.; Galgani, L.; Giorgilli, A.; Strelcyn, J.-M. Lyapunov Characteristic Exponents for Smooth Dynamical Systems and for Hamiltonian Systems; a Method for Computing All of Them. Part 1: Theory. Meccanica 1980, 15, 9–20. https://doi.org/10.1007/BF02128236
- Hala, A.M. Nonlinear Feedback Regulation of Hidden Attractors: The Hala Operator as a Deterministic Chaos Compressor for Sprott A Dynamics. Zenodo 2026. https://doi.org/10.5281/zenodo.18142550
- Hala, A.M. State-Dependent Feedback Dynamic Systems Operator: Mechanisms of Intrinsic Quenching, Dimension Reduction, and Global Universality in Chaotic Manifolds. Eur. J. Comput. Sci. Inform. 2026, 3, 195. https://doi.org/10.5455/EJCSI.20260218042427
- Hala, A.M. State-Dependent Feedback Dynamic Systems Operator (revised, with direct evidence on eleven hosts). Zenodo 2026. https://doi.org/10.5281/zenodo.21704708
- Chen, G.; Ueta, T. Yet Another Chaotic Attractor. Int. J. Bifurc. Chaos 1999, 9, 1465–1466. https://doi.org/10.1142/S0218127499001024
- Lü, J.; Chen, G. A New Chaotic Attractor Coined. Int. J. Bifurc. Chaos 2002, 12, 659–661. https://doi.org/10.1142/S0218127402004620
- Sprott, J.C. Some Simple Chaotic Flows. Phys. Rev. E 1994, 50, R647–R650. https://doi.org/10.1103/PhysRevE.50.R647
- Nosé, S. A Unified Formulation of the Constant Temperature Molecular Dynamics Methods. J. Chem. Phys. 1984, 81, 511–519. https://doi.org/10.1063/1.447334
- Hoover, W.G. Canonical Dynamics: Equilibrium Phase-Space Distributions. Phys. Rev. A 1985, 31, 1695–1697. https://doi.org/10.1103/PhysRevA.31.1695
- Hala, A.M. Successive Controlled Collapse (SCC) in the Hala Attractor Chaotic System: A Formal Proof of Dimension Compression and the Emergence of Invariant Surprise Basins. Zenodo 2026. https://doi.org/10.5281/zenodo.18368832
- Hala, A.M. The Hala-SCC Protocol: Universal Discrete Control and Time-Dependent Modulation of Autonomous Chaotic Systems. Zenodo 2026. https://doi.org/10.5281/zenodo.19683870
- Hala, A.M. Successive Controlled Collapse (SCC) Protocol within Simulated Plasma-Like Manifolds: The Urban Explorer (UrbEx) Paradigm and its Well-Posed Theorem. Zenodo 2026. https://doi.org/10.5281/zenodo.18370593
- Hala, A.M. Hybrid Reversible Chaos Control: Triple Hala Operator with Adaptive Reversible Expansion and Harmonic Anchoring for Lorenz and Sprott A Attractors. Zenodo 2026. https://doi.org/10.5281/zenodo.20261696
- Hala, A.M. Multi-Dimensional Control and Topological Braiding of Chaotic Attractors: Extending the Hala Operator with Design of Experiments and Hybrid Feedback. Zenodo 2026. https://doi.org/10.5281/zenodo.20255928
- Birman, J.S.; Williams, R.F. Knotted Periodic Orbits in Dynamical Systems—I: Lorenz’s Equations. Topology 1983, 22, 47–82. https://doi.org/10.1016/0040-9383%2883%2990045-9
- Ott, E.; Grebogi, C.; Yorke, J.A. Controlling Chaos. Phys. Rev. Lett. 1990, 64, 1196–1199. https://doi.org/10.1103/PhysRevLett.64.1196
- Pyragas, K. Continuous Control of Chaos by Self-Controlling Feedback. Phys. Lett. A 1992, 170, 421–428. https://doi.org/10.1016/0375-9601%2892%2990745-8
- Hwang, C.-C.; Fung, R.-F.; Hsieh, J.-Y.; Li, W.-J. A Nonlinear Feedback Control of the Lorenz Equation. Int. J. Eng. Sci. 1999, 37, 1893–1900. https://doi.org/10.1016/S0020-7225%2898%2900150-5
- Gao, F.; Liu, W.Q.; Sreeram, V.; Teo, K.L. Nonlinear Feedback Control for the Lorenz System. Dyn. Control 2001, 11, 57–69. https://doi.org/10.1023/A:1017956102238
- Chen, M.; Zhou, D.; Shang, Y. Nonlinear Feedback Control of Lorenz System. Chaos Solitons Fractals 2004, 21, 295–304. https://doi.org/10.1016/j.chaos.2003.12.066
- Ding, W.X.; She, H.Q.; Huang, W.; Yu, C.X. Controlling Chaos in a Discharge Plasma. Phys. Rev. Lett. 1994, 72, 96–99. https://doi.org/10.1103/PhysRevLett.72.96
- Klinger, T.; Schröder, C.; Block, D.; Greiner, F.; Piel, A.; Bonhomme, G.; Naulin, V. Chaos Control and Taming of Turbulence in Plasma Devices. Phys. Plasmas 2001, 8, 1961–1968. https://doi.org/10.1063/1.1350960
- Hala, A.M. Hala_Operator_Skill: A Claude Skill for Chaos Control in Physical Plasma and Gaseous Electronics via the Hala Operator (v1.0). Zenodo 2026 (software). https://doi.org/10.5281/zenodo.23143552
- Hala, A.M. Host-Invariance as the Acceptance Criterion for Plasma Chaos Control: A Pre-Registered Null-Model Study. Zenodo 2026. https://doi.org/10.5281/zenodo.23204696
- Hala, A.M. Non-Linear Manifold Engineering Stability Framework for Nuclear Fission Energy Reactor Parametric Control. J. Nucl. Radiat. Sci. 2025. https://doi.org/10.5455/jnrs.2025.02.001