
The Hala attractor is a Lorenz-type chaotic system augmented by a state-dependent nonlinear feedback term, the Hala (حلا) operator, which acts as an internal quenching mechanism rather than as an externally applied control signal. The system is named after its originator, Dr. Ahmed M. Hala (الدكتور أحمد معتوق حلا). A modified formulation bridges dissipative and Hamiltonian-like chaos, and a hybrid spatiotemporal formulation is interpreted against experimental Langmuir probe current–voltage characteristics obtained in quiescent physical plasma. Applied beyond its original Lorenz host to include eleven canonical chaotic systems, the operator drives the largest Lyapunov exponent negative in ten and produces sustained convergence to a fixed point in four, the remaining hosts terminating on one-dimensional invariant sets or diverging. Three control protocols are described: Successive Controlled Collapse (SCC), an irreversible discretization that replaces the continuous flow with a programmable discrete point set; reversible control, which restores the original attractor geometry after temporary stabilization; and topological braiding, which defers the onset of collapse by periodically restoring local instability. Further, the Hala operator was produced as an Anthropic Claude AI search agent coding skill named: hala-operator-skill [1] [2].
The Hala Attractor Chaotic System is a Lorenz-type flow whose z-equation carries a state-dependent cubic feedback term, the Hala operator H = −γ(x² + y²)z. The operator acts from inside the vector field. A single quench factor γ takes the system from chaos to a stable fixed point and then, past a fold at γ = 1/54, to unbounded growth. Lifted out of its Lorenz host, the same operator has been applied to eleven benchmark chaotic systems, where the outcome depends on the host: fixed point, limit cycle, or loss of boundedness. Three control protocols are built on it. Successive Controlled Collapse discretises a trajectory irreversibly. Deferral by periodic modulation (“topological braiding”) postpones collapse. Collapse-and-release returns the Lorenz host to its attractor. This entry gives the definitions, the threshold structure in closed form, recomputed reference figures, the host survey, and the current limits of the evidence in plasma physics and gaseous electronics. The Hala Attractor Chaotic System was developed by Dr. Ahmed M. Hala (الدكتور أحمد معتوق حلا) of Gaseous electronics LLC (www.gaselco.com).
- chaos theory
- Hala attractor
- Hala operator
- fixed-point theory
- bifurcation
- plasma physics
- discretization
- reversible control
- topological braiding
- chaos compression
- chaos control
- state-dependent feedback
- successive controlled collapse
- fractional-order chaos
- gaseous electronics
1. Introduction
1. Introduction
The Hala attractor was introduced in August 2025 as a Lorenz-like system in which the degree of chaos is a tunable quantity, not a fixed property [1]. Two companion studies followed in the same month. One adds a dissipation parameter and periodic forcing to connect dissipative and volume-preserving regimes [2]. The other relates the model to Langmuir-probe current–voltage traces from a quiescent multidipole plasma [3].
The body of replasearch on the Hala attractor addresses the treatment of chaos in nonlinear dynamical systems. It departs from the conventional view of ma motivation is older than the model. A 2020 letter read chaos as an intrinsic and uncontrollable feature of certain systems, reframing it instead as a tunable property accessiblefrom probe I–V characteristics through internal feedback. This research direction, now spanning more than six studies, indicates that chaoticity is not a binary state but a gradient that can be systematically regulated. Through successive theoretical refinements and empirical comparison in plasma physics, the work shows that chaotic behaviour responds to specific parameters, to external forcing, to spatial context, and to measurement perturbation. The framework also connects dissipative and Hamiltonian descriptions of chaotic systems, providing a route to interpret and control complex dynamical behaviour.
2. History and Theoretical Development
The progrea discrete recurrence fitted to the electron-saturation region [4], and a 2025 preprint developed the electric probe as an instrument for that purpose [5]. A recurrence obtained by discretising a one-dimensional I–V curve is a property of the chosen discretissation of the Hala attractor framework is marked by a series of cumulative theoretical advances. The initial study [3]. It is not by itself evidence of chaos introduced the Hala operator by modifying a classical Lorenz-type ordinary differential equation system. The key innovation is the incorporplasma, and the entry treats it as motivation of a state-dependent nonlnly.
Sincear January 2026 the feedback term, quantified by a quenching fac has been studied as an operator γ.in The equaitions of the original Hala attractor are represented by a standard s own right, separate from the Lorenz host where the Hala operator acting along the z direction and is defined as
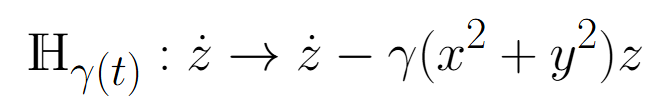
Throughout this . The body of work now has seven layentry article the classical parameter values of the Lorenz system were σ = 10, ρ = 28, α = 1, β = 8/3 are assumed unless stated otherwise. Ts: precursors, the attractor, the operator is quadratic in the transverse coordinates and linear in z, control protocols, a log-frequency extension, so applit is negligible near the origin and dominant at large phase-space excursioncations, and methods for auditing claims. This is the property that allows it to stabilize the unstable saddle-foci of the host system without altering the local behaviour near tentry covers the first four in detail and summarises the rest.
2. Definition of the system
The host is the Lorenz system [6] with the Hala operator added to the z-equation:
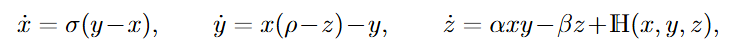
Where the Hala operator is defined as:
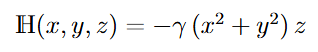
The reference parameters are σ = 10, ρ = 28, α = 1, β = 8/3, and γ ≥ 0 is the quench factor. Three properties follow directly [7].
- The origin is untouched. The operator is cubic, so the linearisation at the origin is that of the Lorenz system for every γ.
- Contraction depends on the state. The divergence of the flow is −(σ + 1 + β) − γ(x² + y²), which is negative everywhere and largest in magnitude far from the z-axis.
- The nontrivial equilibria move outward. The equilibria C± keep y = x and z* = ρ − 1 = 27, with
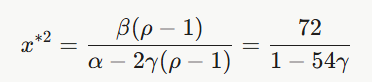
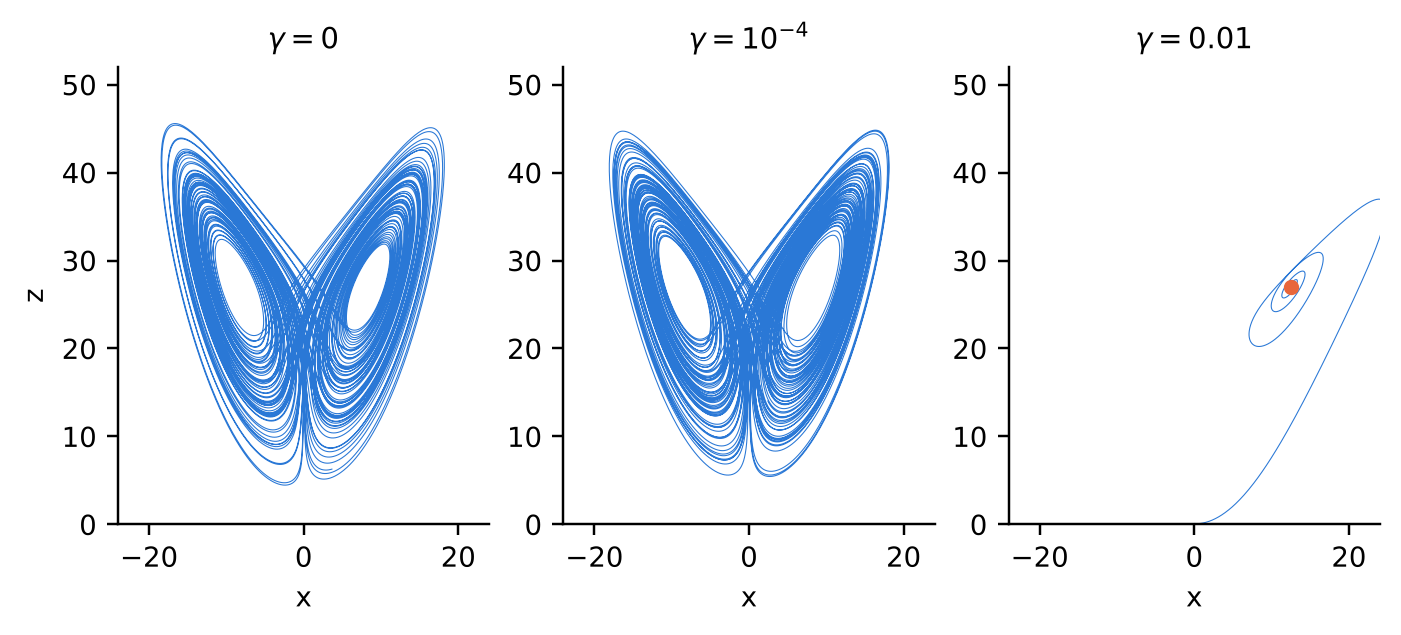
Figure 1. Phase-space projections (x, z) of the Hala attractor at three quench factors, from the initial condition (0.1, 0.1, 0.1). At γ = 0 the Lorenz attractor is recovered. At γ = 10⁻⁴ the attractor is visually unchanged. At γ = 0.01 the trajectory spirals into the stable equilibrium C+ (marked), where the largest Lyapunov exponent is −1.23.
A modified formulation adds a dissipation parameter δ and external periodic forcing [2]. As δ tends to zero the phase-space volume is preserved while the largest Lyapunov exponent stays positive. “Hamiltonian-like” is used for that system only in this restricted sense: it means volume preservation, and no Hamiltonian structure is claimed.
3. Threshold structure
Three thresholds organise the reference system, in the order γ_H < γ_cr < γ_c. Two are known in closed form.
3.1. Hopf threshold γ_H
The origin.
Nequmerical simulation and analysis of the largest Lyapunov exponent revealed that aslibria C± are unstable saddle-foci at γ = γ0 increases the system undergoes a continuous transition,nd become stable through a series oHopf bifurcations, from chaotic s at
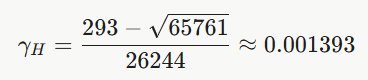
This follows from the Routh–Hurwitz condition on the Jacobian at C± [8]. At γ_H the leading eigenvalue pair is ±10.18i. Above γ_H the real part is negative: −0.027 at γ = -0.00176, −0.57 at γ = 0.0068 and −1.23 at γ = 0.01.
3.2. Boundary crisis γ_cr
Strange-attractor behaviour to stable fixed points. Tble C± do not end the chaotic regime collapses under small changes in a single parameter, establishing thats at once. Between γ_H and about 0.0016 the chaoticity is not an intractable attribute but a gradient property.
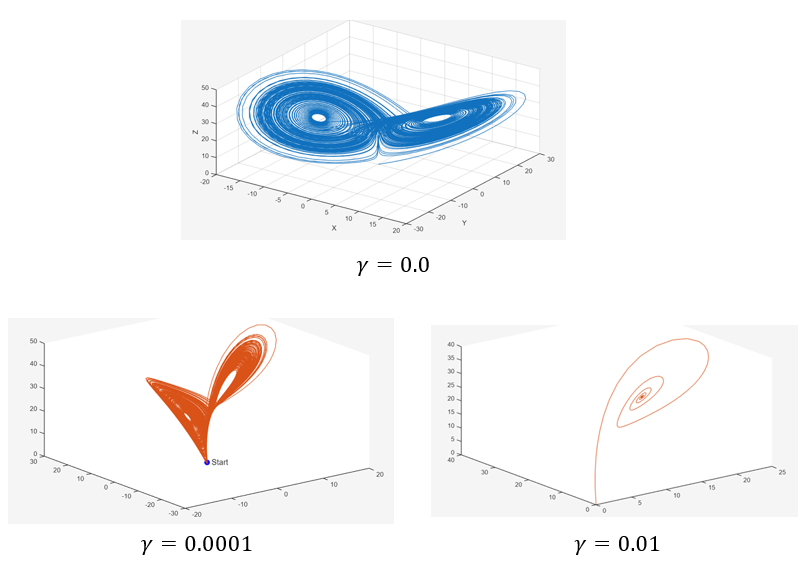
Figure 1. Symmetry breaking and manifold collapse. Phase-space projections of the Hala attractor at three operating points. γ = 0.0: the fully developed chaotic attractor; while superficially resembling classical dual-lobe flows, it lacks rotational symmetry and exhibits localized state-dependent phase compression. γ = 0.0001: micro-feedback initiation; the operator breaks the spatial topology, pinching trajectories along a directional vector and compressing the multi-layered manifold toward a dense nodal origin. γ = 0.01: operating within the negative Lyapunov regime (λ₁ ≈ −0.73), the operator has reduced the effective dimensionality; the chaotic attractor is suppressed and trajectories map onto a single stable focus.
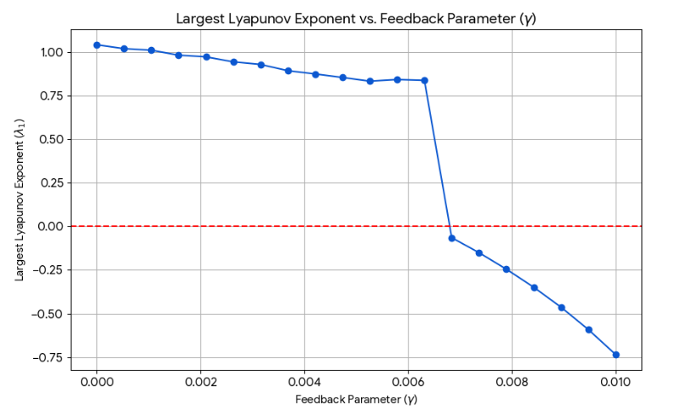
Figure 2. Quantification of phase-space stabilization via the Hala operator. The largest Lyapunov exponent λ₁ as a function of the internal control feedback parameter γ. For γ ∈ [0.0, 0.0065] the system maintains a robust chaotic regime (λ₁ > 0), exhibiting a slow, controlled degradation of structural divergence. At the critical threshold γλ ≈ 0.0068 the exponent drops sharply and discontinuously across the zero boundary (red dashed line). For γ > γλ it is strictly negative, marking the loss of chaotic stretching and the convergence of trajectories onto a stable invariant set.
Three distin attract thresholds govern the controlled system and should be distinguished. The reverse-Hopf stabilization of the non-trivial r coexists with the two stable equilibria C± occurs at γH ≈ 0.00176, and (Table 1); the largest Lyapunov exponent crosses zero at γλ ≈ λ₁ stays near 0.00685 (Figure 2); and the equilibrium branch itself terminates at the fold threshold γc. The attractor is then destroyed in =a 1/54 ≈ 0.018519, derived in Section 3.1. These satisfy γH < γλ < γcboundary crisis [9][10]. ThBe intermediate interval, in which the equilibria are already linearly stable while a chaotic attractor persists, is directly analogous to the coexistence window of the classical Lorenz system near ρ ≈ 24.06 – 24.74.
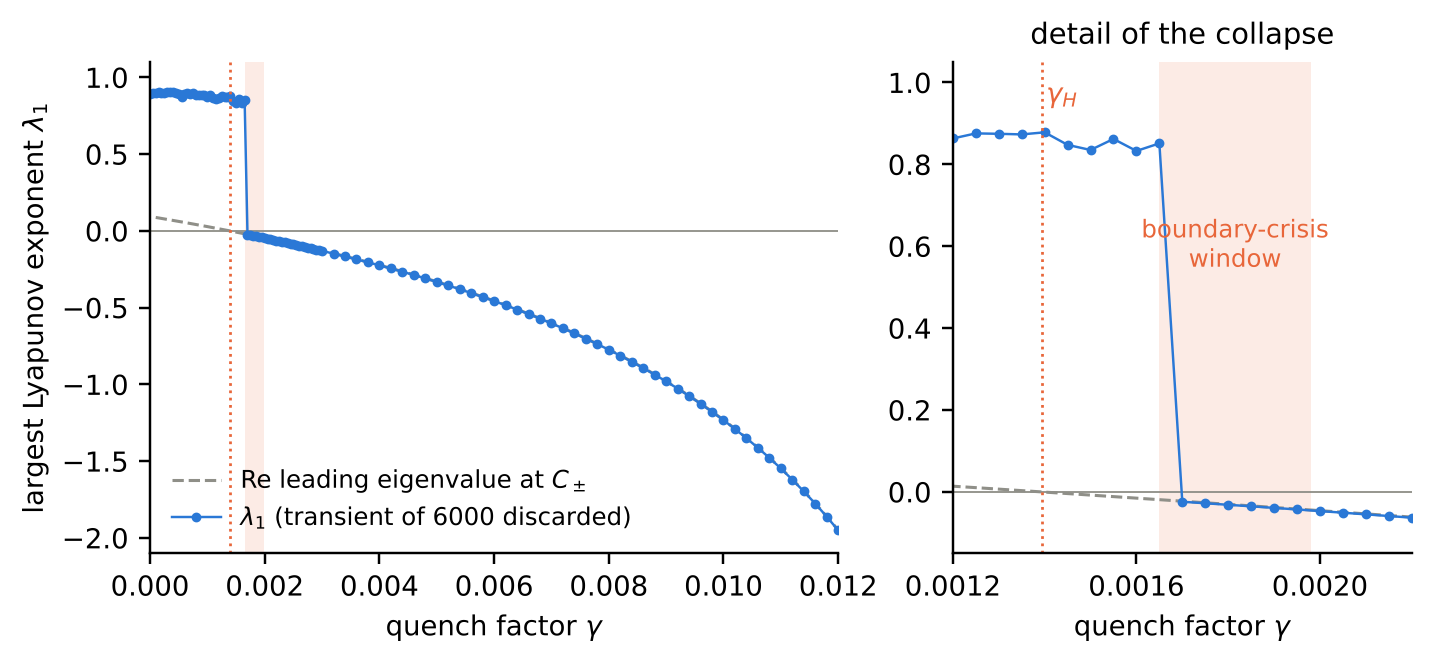
The secyond it, chaos survives only as a transient whose lifetime shortens as γ grond work [4] expanded this. foundation by adding a dissipation parameter δ and an external periodic forcing term of adjustable amplitude and frequency, in order to explore the interplay among dissipation, resonance, anIn an ensemble of eight initial conditions, all remained chaos. The parameter δ scales the linear damping of the host, allowing the system to be tuned continuously between a strongly dissipative regime and a conservative one. Two quantities must be distinguished in this tic after 6000 time units at γ = 0.00164, three at γ = 0.00184, and none at γ ≥ 0.00196. A gated analysis. The sum of the Lyapunov exponents equals the time-averaged divergence of the vector field, Σλᵢ = ⟨∇·F⟩, places the canonical quench at γ_cr ≈ 0.00198 [9].
Pand governs the evolution of phase-space volume; the largest exponent λ₁ measurest the crisis, λ₁ equals the rate of separation along the unstable direction. For the unmodified host the divergence is the constant −σ − 1 − β, fixed by the linear damping coefficients alone, whereas λ₁ is a dynamical property that those coefficients do not directly set. The two can therefore be varied independently, and the analysis of the Lyapunov spectra, phase-space trajectories, and volume contraction established that they areeal part of the leading eigenvalue at C±. A Lyapunov estimate taken without discarding the transient, or over a short window, reports a positive value well past γ_cr. The estimate must therefore state its discard time [11].
As δ was reduced toward zero the phase-space contraction vanished, Σλᵢ → 0, while the largest Lyapunov exponent remained positive. In three dimensions, with the exponent along the flow direction vanishing, this forces λ₃ = −λ₁: stretching along the unstable direction is balanced exactly by contraction along the stable one, with no net loss of volume. Chaotic behaviour therefore persists in the conservative limit, in which Liouville phase-space volume is preserved. The term Hamiltonian-like is used here in that restricted sense — the flow becomes volume-preserving rather than derived from a Hamiltonian function, since the host admits no natural energy function or symplectic structure. The distinction matters because the two limits support chaos of qualitatively different kinds. In the dissipative regime volumes contract to zero and trajectories collapse onto a measure-zero strange attractor with a well-defined basin, so that initial conditions are forgotten. In the conservative limit no attracting set can exist, and chaos instead occupies a positive-measure region of phase space, typically interleaved with regular islands, in which initial conditions are never forgotten. The largest Lyapunov exponent remains positive across the transition while the geometric object supporting the chaos changes entirely, and it is this passage between the two descriptions that the modified formulation was constructed to bridge. The Hala operator occupies a specific place in this picture. Its contribution to the divergence is −γ(x² + y²), so that
∇·F = −σ − 1 − β − γ(x² + y²)igure 2.
Largest Lyapunov exponent λ₁ against the quench factor γ for the reference system, after discarding a transient of 6000 time units and averaging over 600. Dashed line: real part of the leading eigenvalue at C±. Dotted line: Hopf threshold γ_H ≈ 0.001393. Shaded band: boundary-crisis window, 0.00165 to 0.00198, in which chaos persists only as a long transient. Right panel: detail of the collapse.
Unlike the linear damping, which contributes a constant, the operator supplies contraction that vanishes on the z-axis and grows quadratically with distance from it. The controlled flow is accordingly near-conservative close to the axis and increasingly dissipative at large excursions — neither uniformly dissipative nor uniformly volume-preserving, but a state-dependent combination of the two. A consequence follows for the framework as a whole: in the limit δ → 0 the operator becomes the only remaining source of volume contraction, so that γ alone carries the system from conservative chaos to a quenched state. The quenching mechanism described throughout this entry does not depend on background dissipation for its action. External forcing yielded distinct resonant phenomena. In a strongly damped system a periodic drive produces a bounded response set by the balance between energy input and dissipation; as δ → 0 that balance is removed, and a drive tuned near a natural frequency of the flow accumulates energy limited only by the nonlinearity. This regime is directly relevant to radio-frequency plasma heating, where a nearly collisionless plasma is close to conservative on the heating timescale and energy is deposited through wave–particle resonance rather than through collisional dissipation.
3.3. Fold γ_c
The thequilird studybria C± [5] connrected these advancese to infinity and cease to experiment. Cuist at
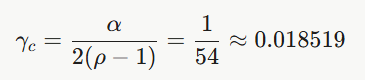
The value is independent of σ and β (Figure 3) [7]. The same construction gives γ_c = 1/(2z*) for other Lorenz-family hosts: 1/42 for the Chen system and 1/40 for the Lü system at their standard parameters.
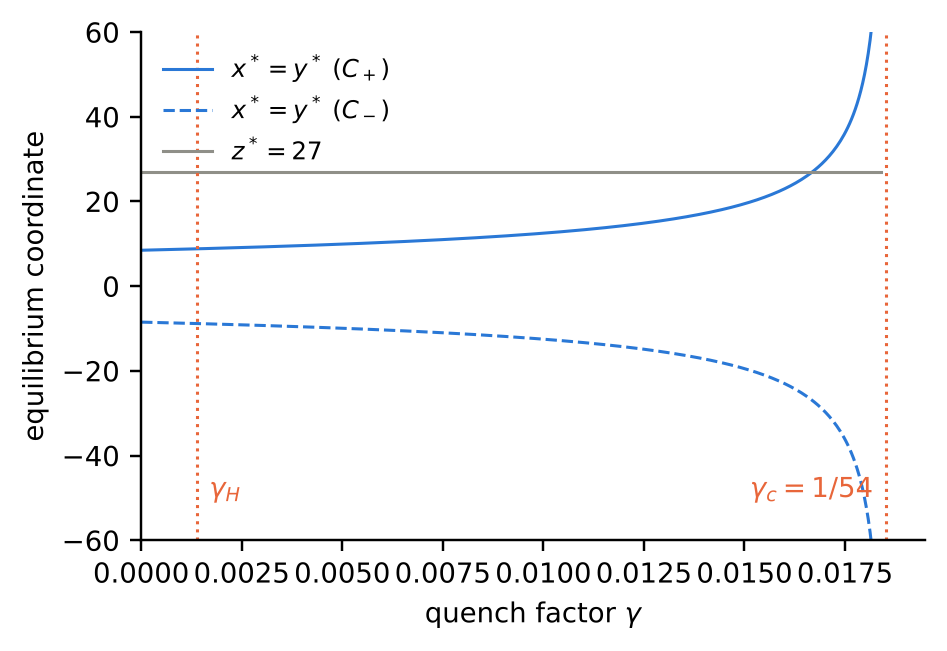
Figure 3. Continuation of the equilibria C± in the quench factor. The coordinate z* = 27 does not change. The coordinates x* = y* diverge as γ approaches the fold γ_c = 1/54. Dotted lines mark γ_H and γ_c.
3.4. Over-driving
Forre γ > γ_c nt–voltage traces obtained from Langmuir probes in quiescent plasma were analysed in the electron saturation region. Quadratic fitting of that region yielded a discrete recurrence relation whose bifurcation diagram displayed a classic period-doubling cascado attracting equilibrium remains and the trajectory is unbounded. The escape is in x and y, not in z. The operator pins z to a small constant, z∞ ≈ 2.77 at γ = 0.14, so the terminating in a chaotic regime. A spatial dependence was observed, with chaos manifesting more strong x(ρ − z) no longer saturates and x and y grow exponentially at the magnetically confined plasma boundary and greater regularity in the quiescent bulk, and temporal transitions appeared when the diagnostic probe actively perturbed the system, a form of measuremea rate of about 11 per time unit (Figure 4). The calibration rule for any pulse is therefore γ_on < γ_c.
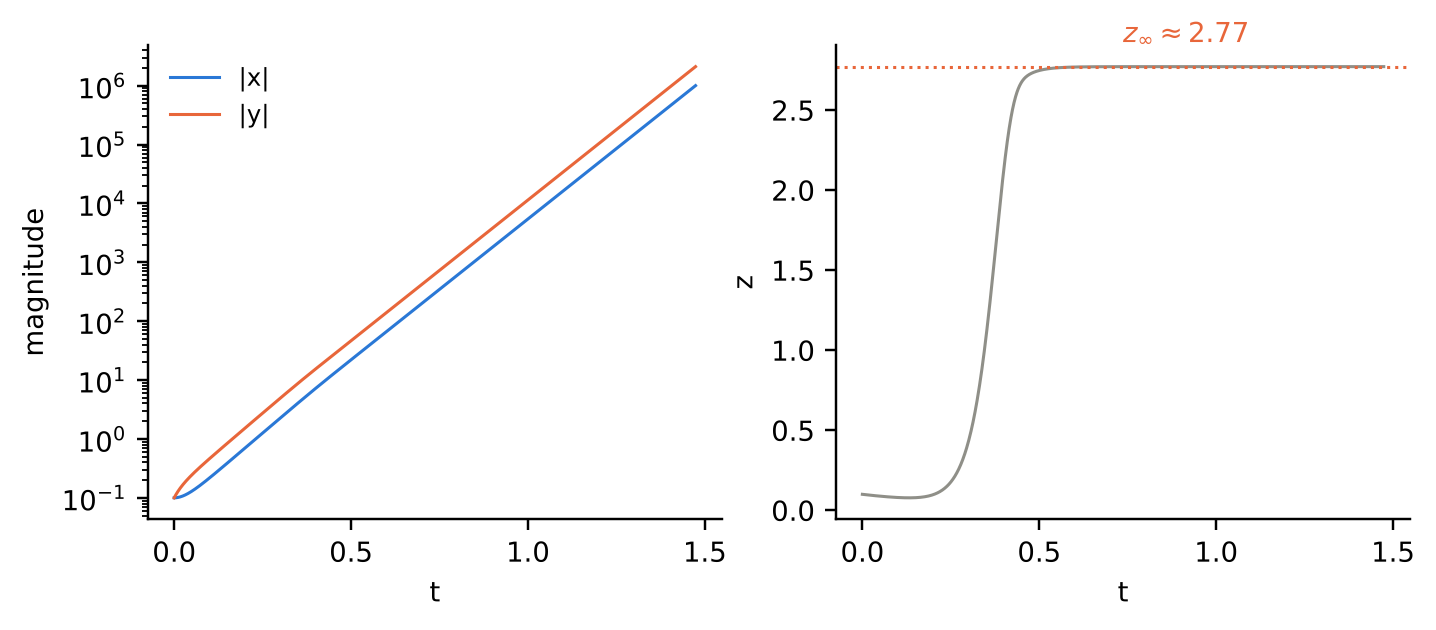
Figure 4. Over-driven case, γ = 0.14, well above γ_c. Left: |x| and |y| grow exponentially, reaching 10⁶ by t ≈ 1.5. Right: z settles on the constant z∞ ≈ 2.77.
4. The Hala operator on other hosts
Int intrusion. A suitably parameterized Hala attractor model reproduced these behaviours, including the fixed point → limit cycle → period-doubling → chaos route and the hysteresis observed in the plasma I–V characteristics curves, providing evidence for the model’s ability to interpret and predict real physical plaJanuary 2026 the feedback term was separated from the Lorenz system and applied to the Sprott A flow [12]. For a three-dimensional autonomous host with state (x₁, x₂, x₃), the operator on axis k isma phenomena.
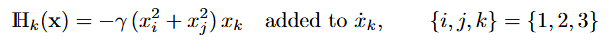
3. Deterministic Control and Discretization via Successive Controlled Collapse
Here “host” means the mathematical system that carries the operator; it does not mean a physical device. The operator has been surveyed on eleven benchmark hosts [13][14]: Lorenz, Chen [15], Lü [16], Dadras, Thomas, Lorenz-84, Sprott A [17] (the Nosé–Hoover oscillator [18][19]), Aizawa, Halvorsen, Rössler and Rabinovich–Fabrikant.
The Hala aouttractor admits a deterministic control protocol termed Successive Controlled Collapse (SCC). Brief activation of the feedback factor γ > 0 through a smooth sigmoidal ramp of amplitudecome is specific to the host (Figures 5 and 6, Table 1). With the operator on the z-equation, four patterns appear.
- - Fixed point, then loss of boundedness. Lorenz, Chen, Lü and Dadras reach a stable equilibrium in a finite window of γ and become unbounded above it. For the Lorenz family the window closes at γ_c = 1/(2z*).
- - Fixed point at large γ only. Thomas and Lorenz-84 pass through periodic states and reach a fixed point only for γ of order 0.2 to 0.6. They stayed bounded up to γ = 1000.
- Limit cycle. Sprott A and Aizawa settle on periodic orbits and never reach a fixed point. Sprott A has no equilibria, so none can be stabilised. Halvorsen becomes periodic and then unbounded.
- - No bounded quench. Rössler shows narrow periodic windows before it becomes unbounded. Rabinovich–Fabrikant stays chaotic until it becomes unbounded.
A γon forcnes chgaotic trajectories to collapse onto the stable equilibria of the controlled flow in a globally contracting manner. Repeating this pulse, separated by a free-evolution interval Tfree dtive largest Lyapunov exponent is therefore necessary for qurenching which γ returns to zero, generates families of discrete landingbut does not guarantee a fixed points whose distribution traces the geometry of the underlying strange attractor. Because the collapse phase is globally contracting, distinct pre-collapse states are . The operator's axis matters as well: the z-axis is a poor match for hosts whose instability is carried onto common landing points, and the pre-image of a landing point cannot be recovered from the point itself. SCC is therefore an irreversible protocol, in contrast with the reversible and partially reversible mechanisms of Section 5by another variable, and axis choice for Rössler, Rabinovich–Fabrikant and Halvorsen remains open.
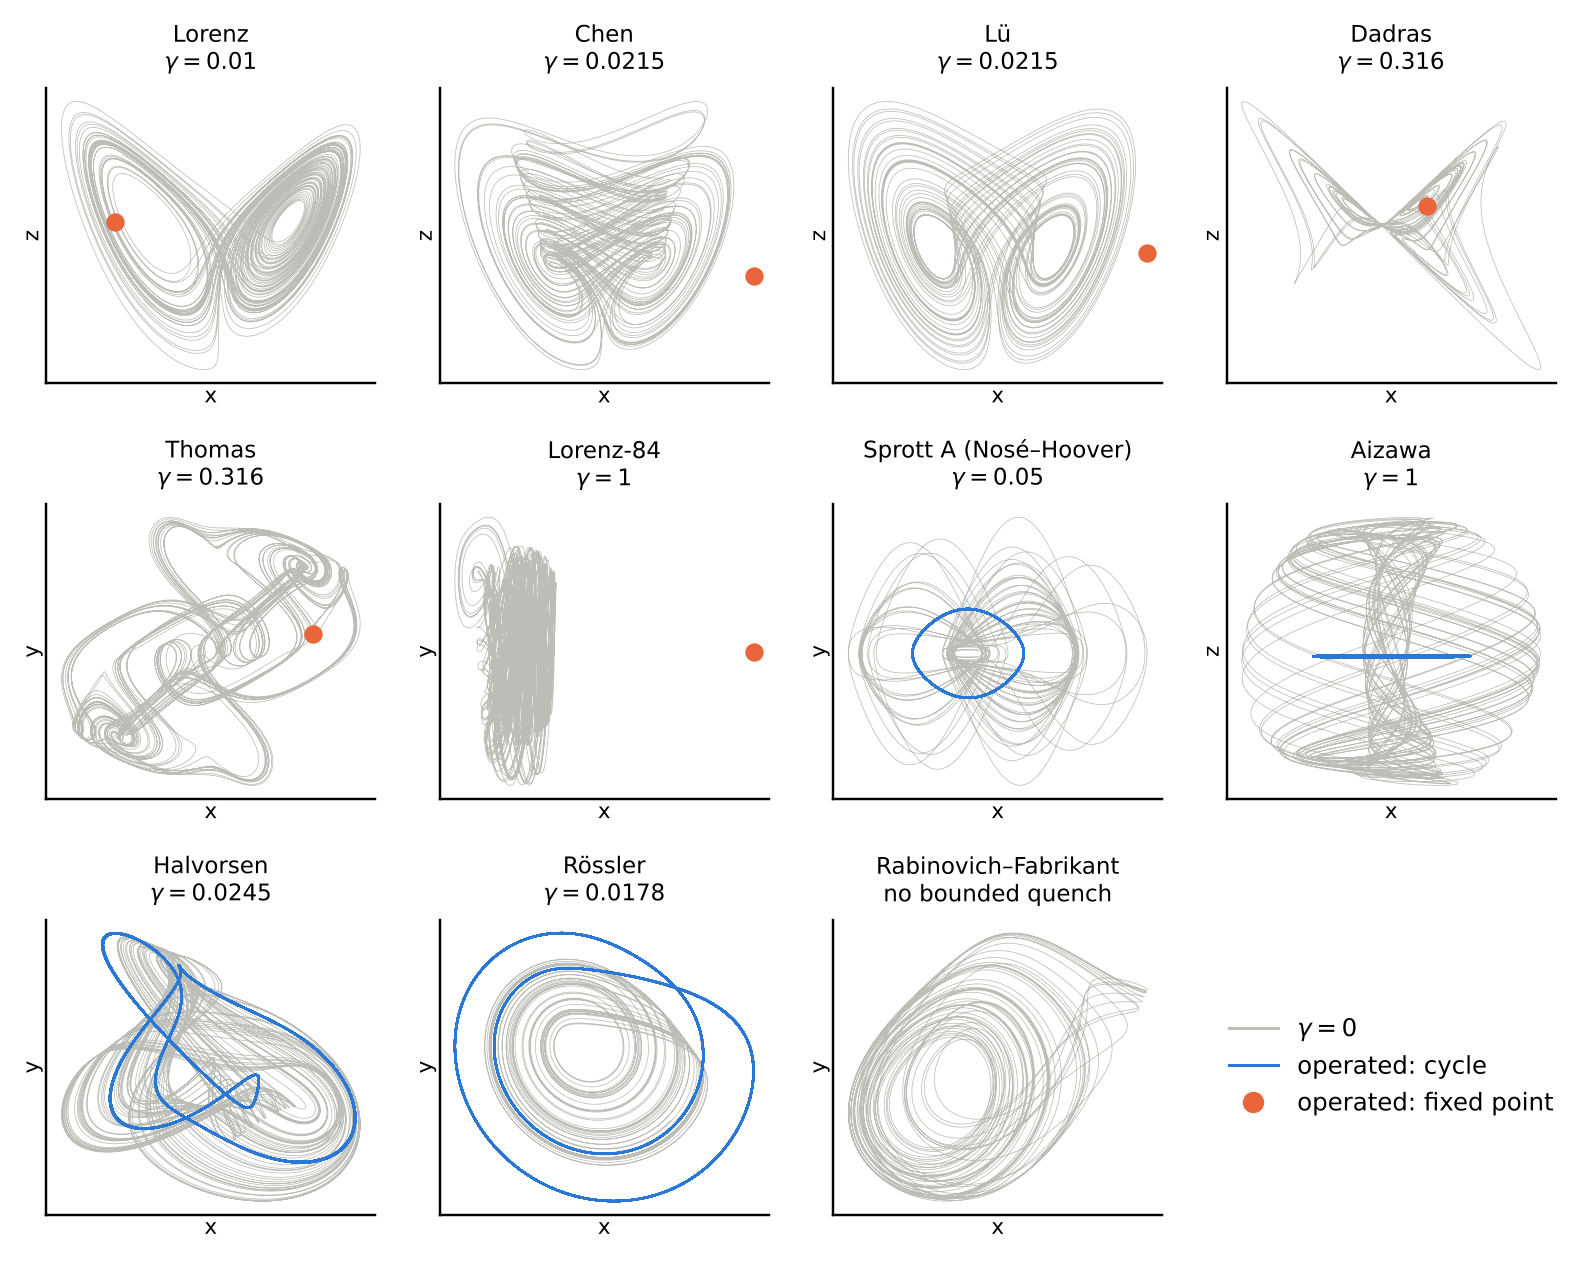
Figure 5. The Hala operator on eleven benchmark hosts. Grey: chaotic attractor at γ = 0. Blue: periodic orbit under the operator. Orange dot: fixed point under the operator. The quench factor used is given above each panel. The Aizawa cycle lies at constant z and is seen edge-on. Rabinovich–Fabrikant has no bounded quenched state with the operator on z.
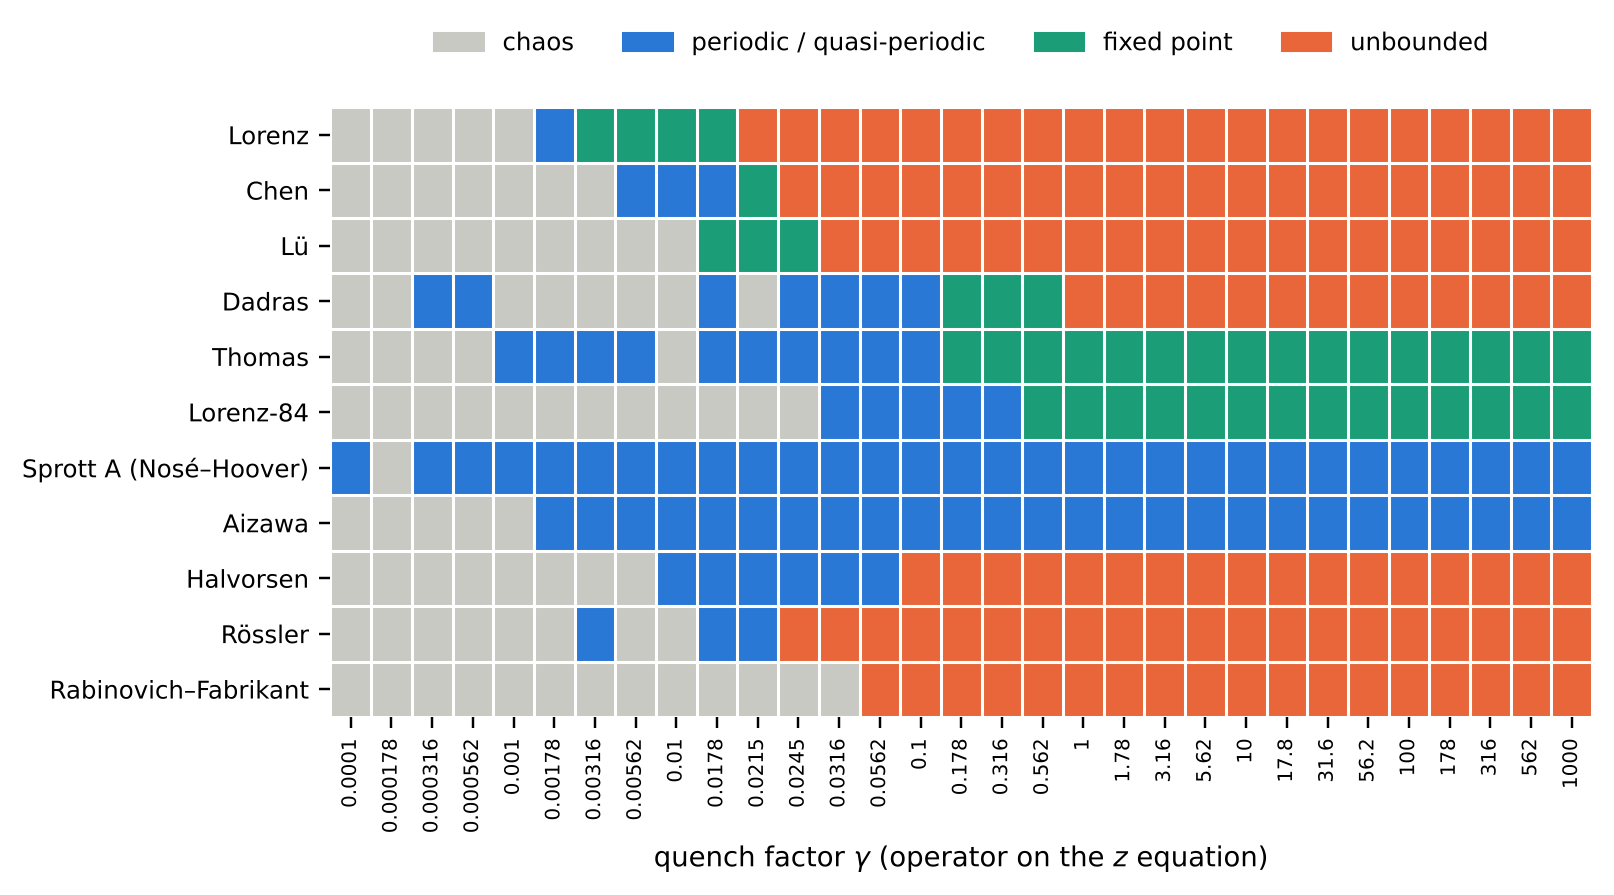
Figure 6. Long-time outcome on each host against the quench factor, operator on the z-equation, from 31 values of γ between 10⁻⁴ and 10³. Grey: chaos. Blue: periodic or quasi-periodic. Green: fixed point. Orange: unbounded.
Table 1. A Ouniqueness argument establishes that no two landing points coincide under non-identical pulse timing sequences, so that the protocol replaces the continuous chaotic flow with a programmable discrete set that remains faithful to the geometry of the original attractortcome of the Hala operator on the z-equation of each host. Ranges are read from the grid of Figure 6 and are accurate to about a quarter of a decade.
3.1 Equilibrium structure and the calibration threshold
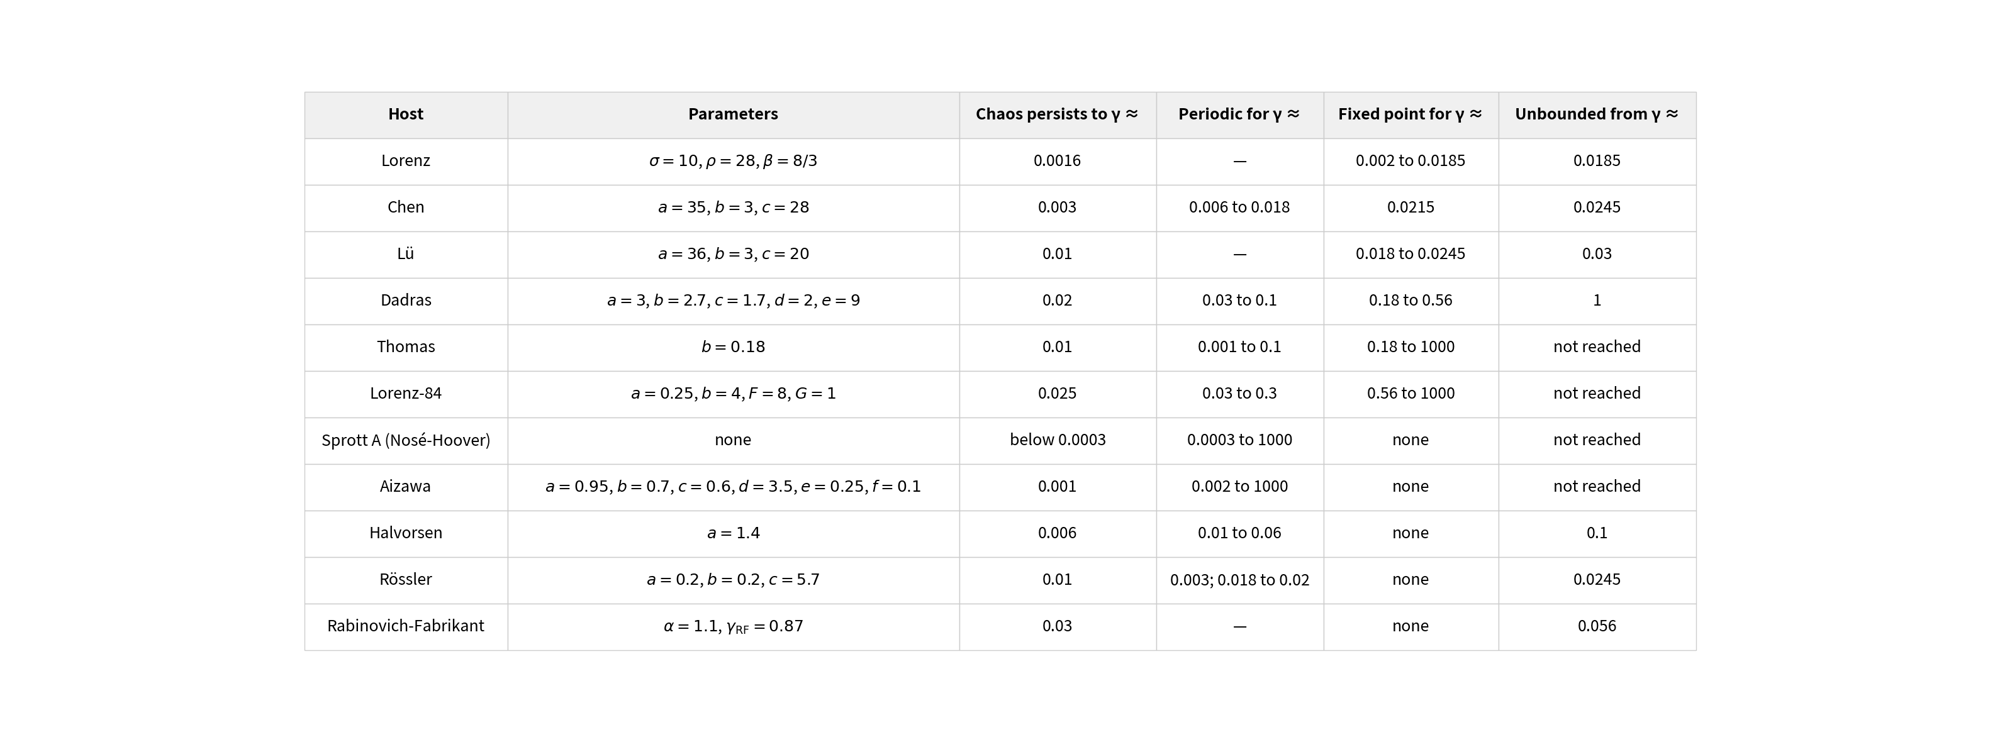
Periodic windows inside the chaotic range (Dadras, Thomas, Rössler) are listed where the grid resolved them.
5. Control protocols
Thre equilibria onto which the collapse occurs follow in closed form. Settinge protocols use the operator. They ẋ = 0 gdivffesr y = x, and substituting into ẏ = 0 yields x(ρ − z − 1) = 0, so t what either x = 0, correappensponding to the origin, infor
z* = ρ − 1 = 27
The vermation cal coordinate of the non-trivial equilibria is therefore independent of γ. Subrried by the trajectory: collapse distituting y = x canrd z = z*s into ż = 0 gives x*²(α − 2γz*) = βz*, hdencfe
x*² = βz* / (α − 2γz*) = 72 / (1 − 54γ)
At γ = 0 this returns x* = ±6√2 ≈ ±8.485, the classical Lorenz equilibria C±. As γ increases the branch grows monotonically and diverges when the denominator vanishes, giving the closed-form fold threshold
γc = α / [2(ρ − 1)] = 1/54 ≈ 0.018519
independent of σpostpones the loss, and release returns the system to its and β. Beyond γc no ttreal non-trivial equilibrium exists within the symmetric ansatz, and tctor without restoring the earlier trajectory.
5.1. Irreversible: Successive Controlled Collapse (SCC)
SCC switches no longer relax to static equilibria but are governed by transient dynamics. This value bounds the admissible pulse the operator on in pulses [20][21][22]. Each pulse raises γ smoothly to an amplitude for the protocol, as developed in Section 3.3.
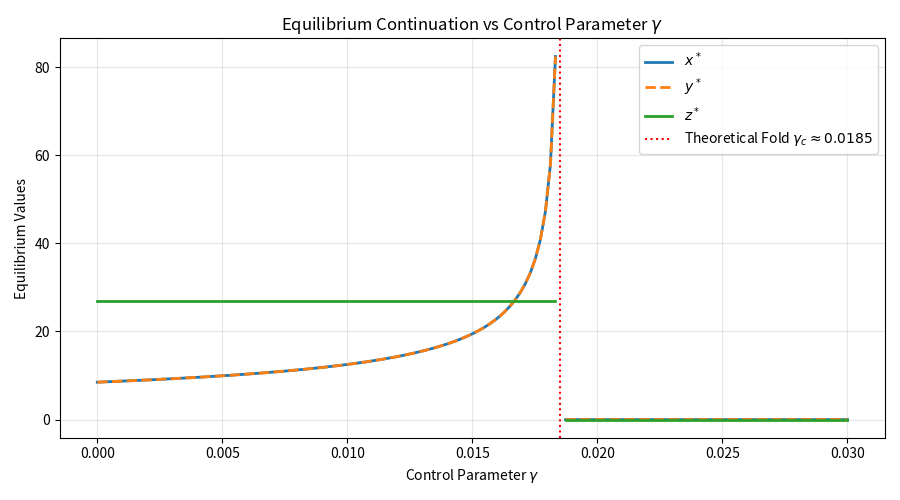
Figure 3. Equilibrium continuation of the Hala–Lorenz system as a function of the control parameter γ. The fixed-point branches (x*, y*, z*) preserve the structural symmetry x* = y*, with z* = 27 remaining invariant across the sweep. As the control parameter approaches the fold threshold γc = 1/54 ≈ 0.0185 (red dotted line), x* and y* asymptote toward infinity, marking the critical limit past which real non-trivial equilibrium branches cease to exist within the symmetric ansatz.
3.2 Free-evolution interval and the landing-point distribution
Thγ_on < γ_c, holds it, and re continuous trajectory evolution during the uncontrolled phase is evaluurns it to zero. Pulses are separated by varying the a free-evolution interval, which reveals the intrinsic dissipative properties of the flow under periodic switching:
- Short evolution interval (Tfree = 5.0). Trajectories retain residual displacement from the preceding parameter pulse, resulting in a broader spatial dispersion of landing points that reflects transient manifold structure.
- Extended evolution interval (Tfree = 50.0). Trajectories undergo prolonged phase-space volume contraction, drawing landing points into significantly tighter clusters along the local manifold.
This T_free. During a pulse the trajectory contracts towards C±(γ_on); the sptatial condensation at larger T_free represents physical relaxation along the stable manifold, confirming that longer evolution times allow te at the end of the pulse is the landing point.
The controlled system to settle closer to its asymptotic invariant setsapse is irreversible in a practical sense.
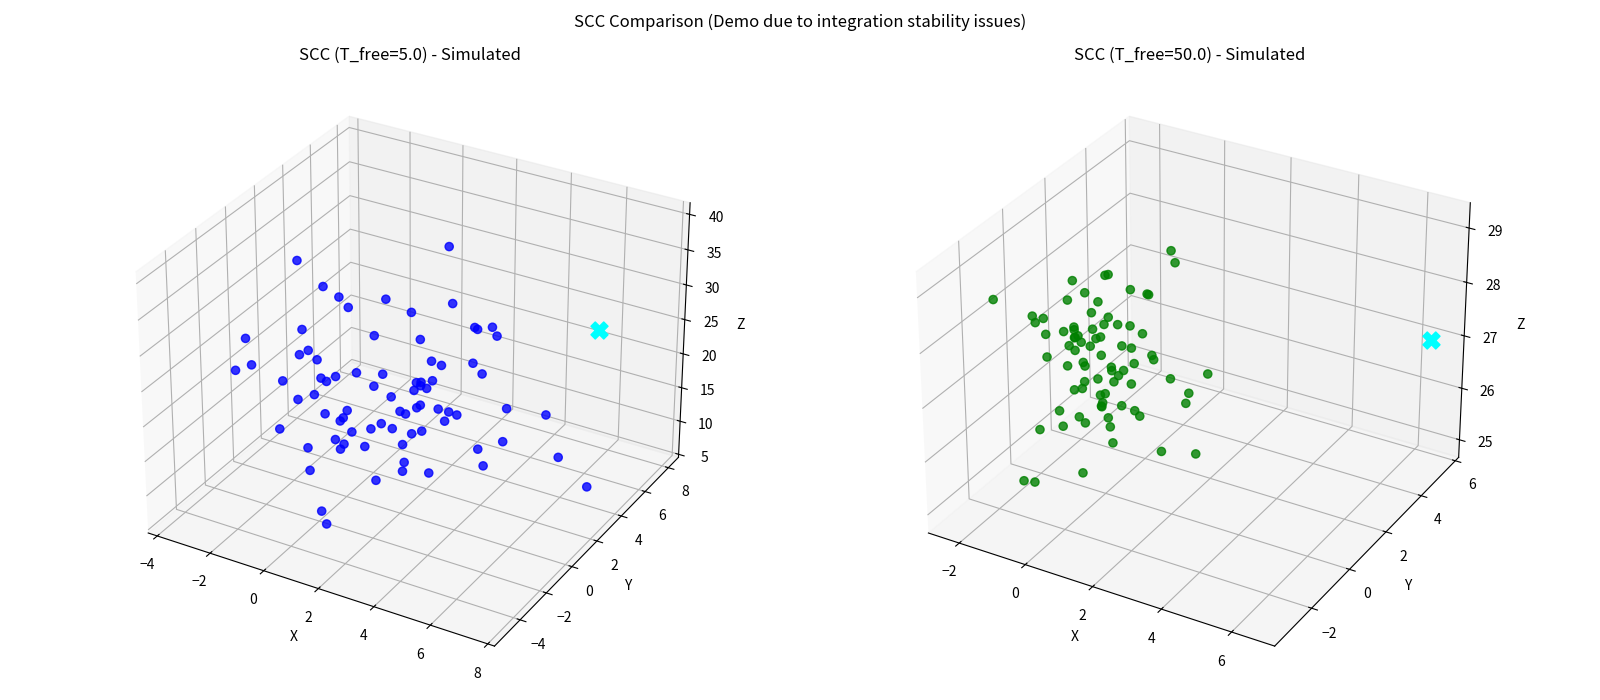
Figure 4. Phase-space volume contraction under the Successive Controlled Collapse protocol. Side-by-side comparison of landing-point constellations evaluated at short (T_free = 5.0, left) and extended (Tfree = 50.0, right) free-evolution intervals, alongside the target region (cyan marker). Shorter evolution intervals capture transient dispersion caused by residual displacement after the pulse, whereas prolonged free evolution permits phase-space volume contraction, drawing trajectories into tighter clusters along the invariant manifold.
3.3 Pulse calibration
The A pulse amplitude must satisfy γ_on < γ_c. When this condition is violated the protocol has no target: at γ_on = 0.14, far beyond γ_c = 1/54, the equilibrium relation of Section 3.1 gives x*² = 72/(1 − 7.56) < 0, so no real equilibrium exists for the trajectory to collapse onto. The resulting unbounded vertical excursion, in which the coordinate z exceeds 10⁵, is the correct behaviour of the vector field under an over-driven pulse rather than an artifact of the integrator; imposing state clipping or domain bounding would conceal a genuine dynamical escape rather than correct a numerical fault. The opemooth flow is invertible at every finite time, so the map is non-injective only in the limit of long pulses or below numerical resolution. On the reference system, 50 initial conditions spread over ten units per axis converge to within 2.5 × 10⁻⁹ of C± under γ = 0.005, and backward integrational requirement for maintaining bounded discretization across successive switching cycles is acc from the collapsed state diverges.
Twordingly a calibration constraint on the pulse amplitude, γ_on < γ_c, and not a solver setting.
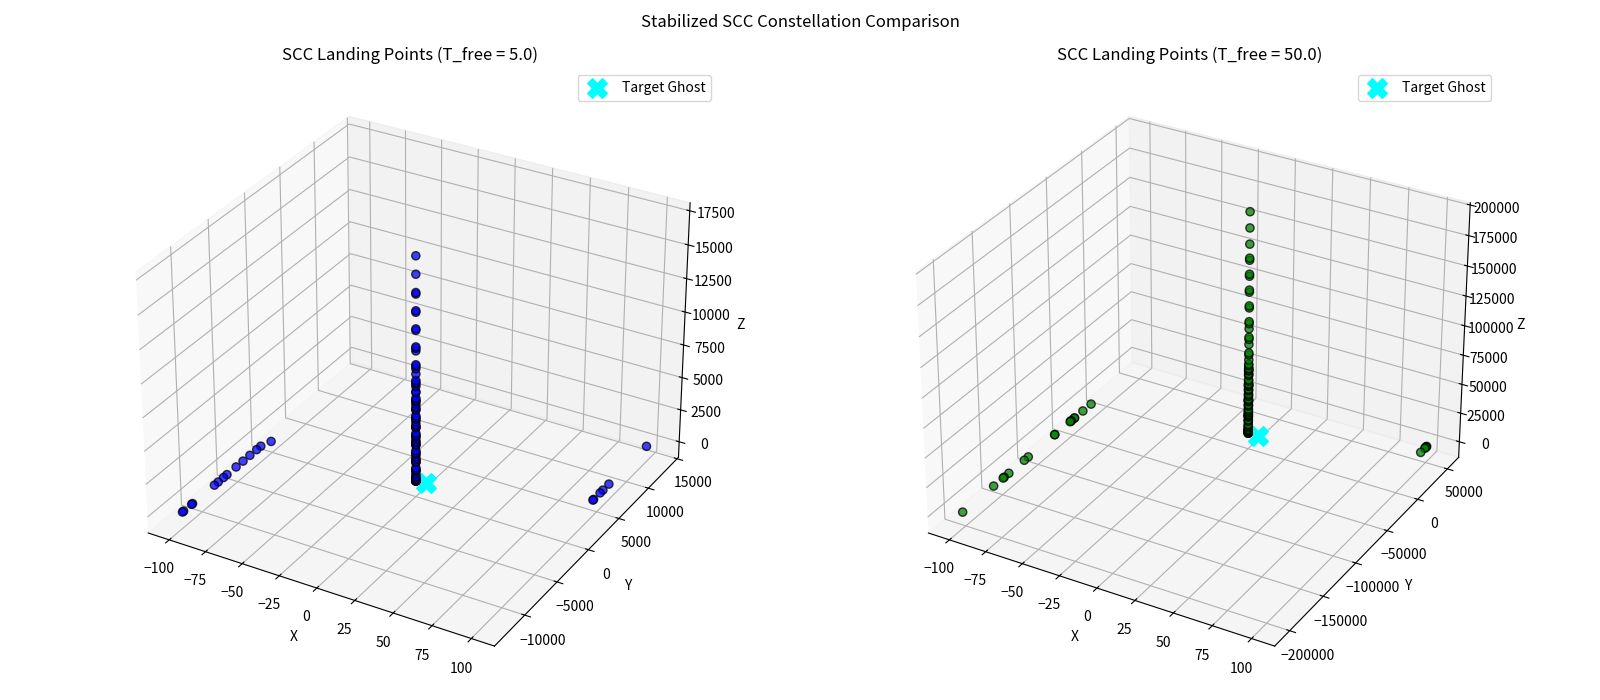
Figure 5. Trajectory escape under an over-driven control pulse, γon = 0.14 ≫ γc, across Tfree = 5.0 (left) and Tfree = 50.0 (right). With the pulse amplitude driven far beyond the fold boundary, no real equilibrium exists within the symmetric ansatz, and the nonlinear feedback term −γ(x² + y²)z drives trajectories out of the bounded phase space along vertical manifold towers (z > 10⁵), demonstrating the necessity of pulse calibration.
3.4 Transient trapping and the ghost bottleneck
Lfeatures set the landing -points recorded at short free-evol distribution intervals form a tight cluster near z = 27,(Figure 7).
- Pulse length. A pulse long enough for full collapse erases the history, so every cycle then starts from the same point and the protocol becomes exactly periodic. A spread of landing points requires incomplete collapse or non-identical timing.
- Free interval. With T_free = 5 the released trajectory has not left the neighbourhood of the equilibrium when the next pulse arrives, and every landing falls on the same point. With T_free = 50 the trajectory returns to the full attractor, and landings divide between C+ and C− (102 and 98 of 200).
As well iγ_onside the region vacated by approaches γ_c the equilibrium branch. This clustering is a ghost bottleneck: a localizeda recede and the plane z = 27 becomes a slow region of phase space in which the flow retains the slow character of a nearby equilibrium structure that the t, because ẏ = 0 wherever y = x on it. Trajectory can no longer reach, so that passing trajectories stall as though an attractor were still present. The mechanism has two components in the Hala–Lorenz system.
First, thies then linger without landing (a ghost bottleneck), which is a second reason to keep planeγ_on z = ρ − 1 = 27 carriwes the equillibrium branch for every value of γ, and on below γ_c.
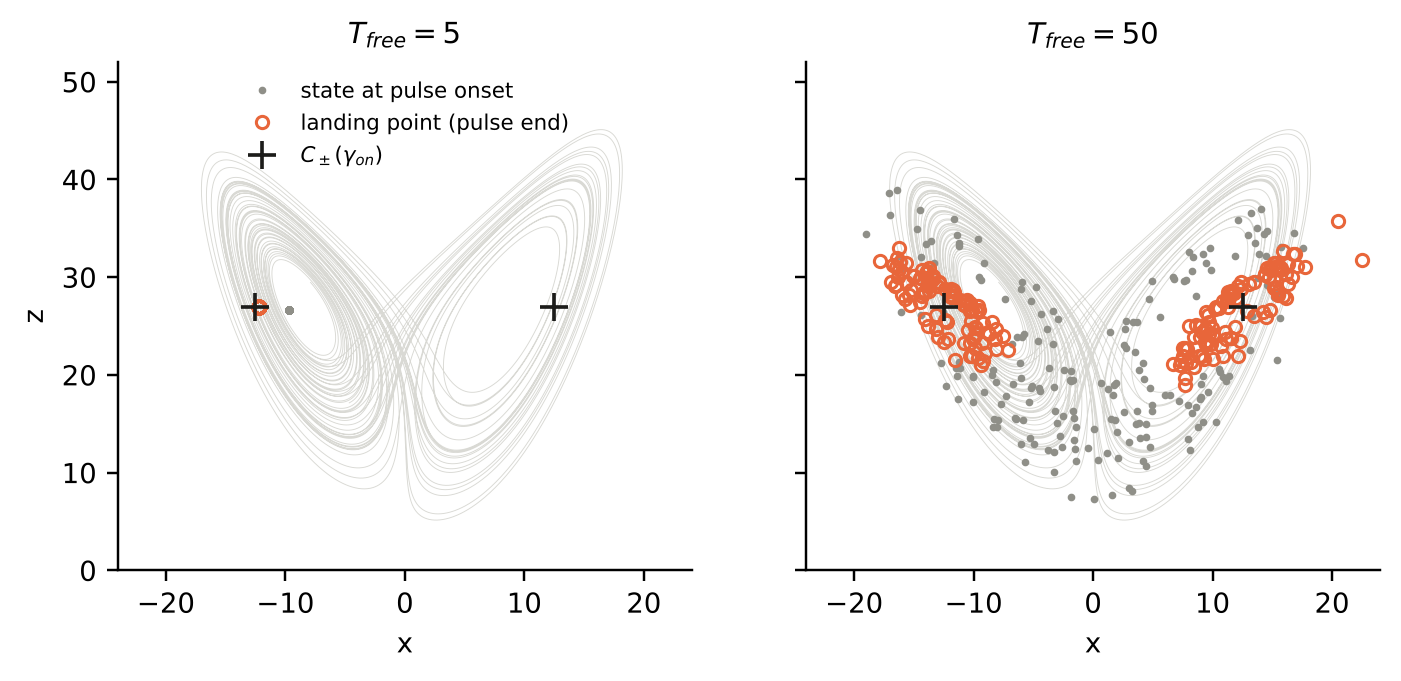
Figure 7. SCC landing points on the reference system for two free intervals, with γ_on = 0.01, pulse length 3 and sigmoid ramp width 0.25, over 200 pulses. Grey dots: state at pulse onset. Orange circles: landing point at pulse end. Crosses: C±(γ_on). Light grey: the Lorenz attractor.
The pulse ramp can be generated autonomously by making γ a fourth state variable that obeys a logistic equation, γ̇ = kγ(1 − γ/γ_target), decoupled from (x, y, z). The local growth rate lags the threshold: with k = 0.3 and γ_target = 0.01, γ crosses γ_H at t ≈ 25.6 but the growth rate stays negative only from t ≈ 32, when γ ≈ 0.006 (Figure 8).
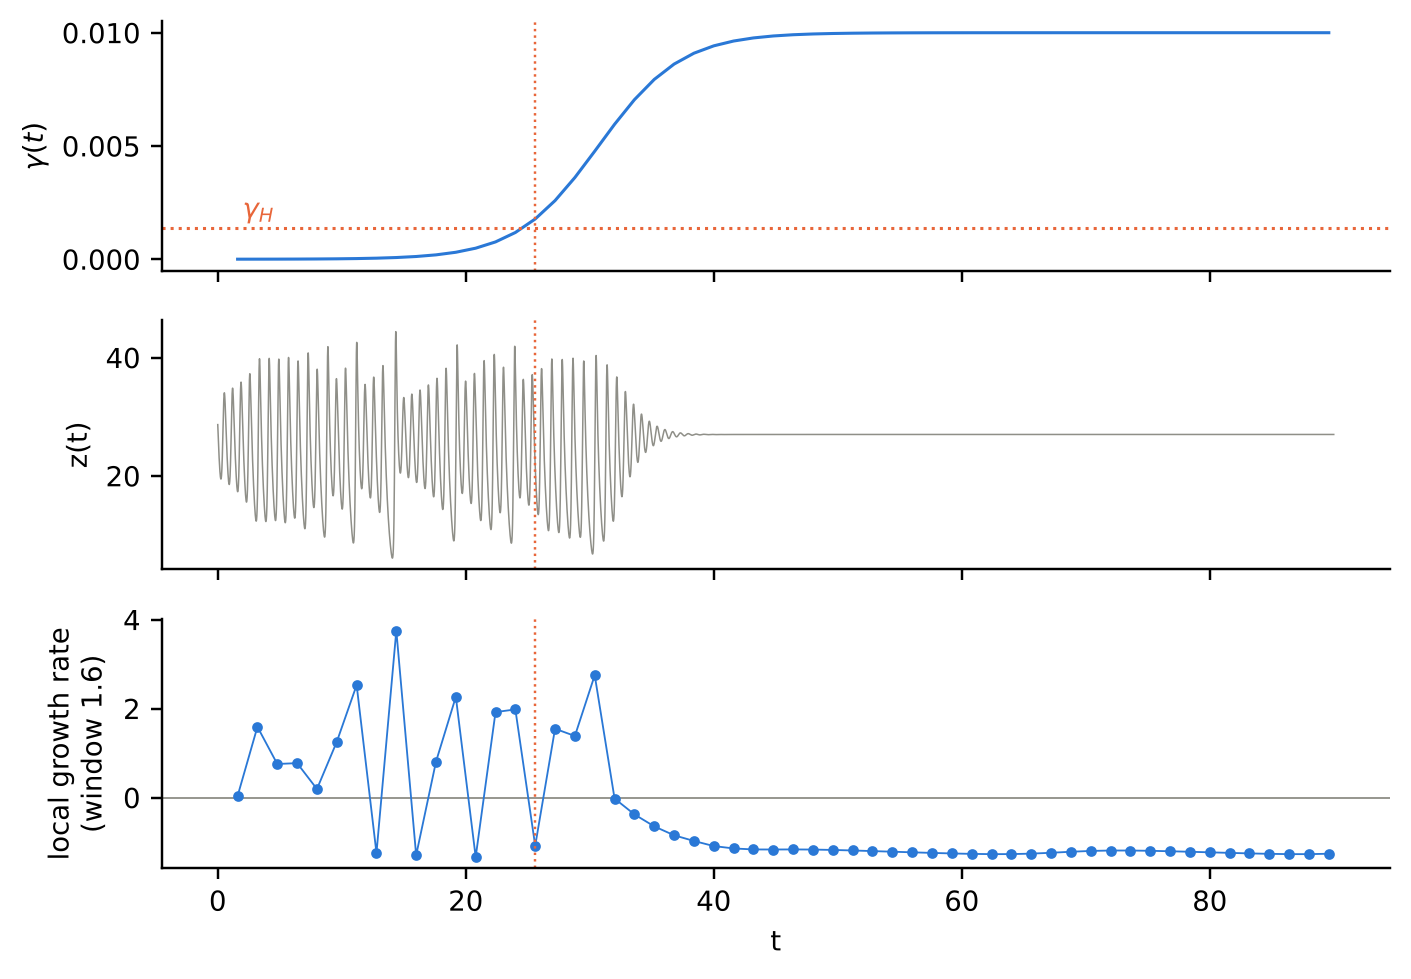
Figure 8. Autonomous logistic ramp of the quench factor on the Lorenz host: k = 0.3, γ_target = 0.01, seed γ(0) = 10⁻⁶. Top: γ(t), with γ_H marked. Middle: z(t). Bottom: local growth rate of a tangent vector over windows of 1.6 time units.
5.2. Regime reversal: collapse and release
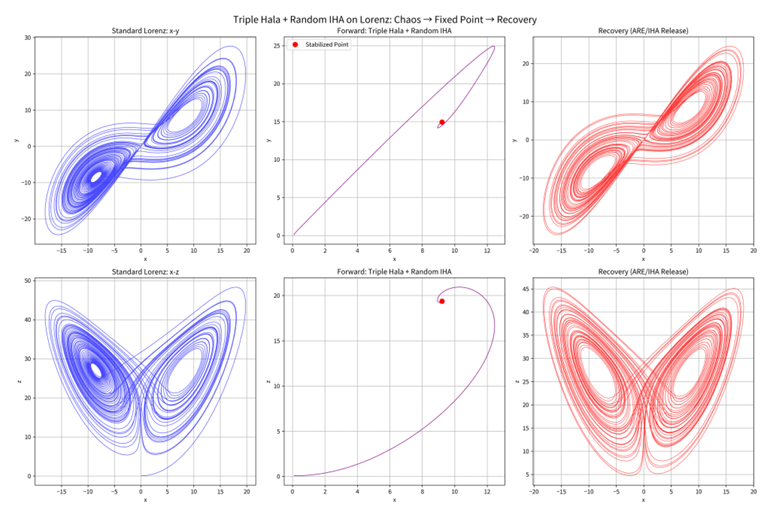
Withdrat plane the second component of the vector field vanishes identically, ẏ = x(ρ − z) − y = 0 whwing the operator after a collapsenever y = x. The plane is therefore a slow surface of the flow irrespective of where ets the trajectory leave the equilibria themselves lie. Second, as γ approaches γ_c from below the equilibria recede toward large |x| along that plane, and past γ_c they cease to exist altogether; what remains at moderate |x| is a region of near-vanishing phase-space velocity with no equilibrium to terminate it. Trajectories adiabaum and return to the chaotic attractor [23]. On the Lorenz host the recovered attractor matches the original statistically tracking a continuous sigmoidal ramp enter this region and traverse it slowly.
U: mean z of 23.4 against 23.6, and stander a short free-evolution interval (Tfreerd deviation of x =of 5.0) integration ends w7.85 against 7.91 (Figure 9).
Thile trajectories are still crossing the bottleneck, and the recorded landing points accumulate there. The structure is termed a ghostreversal applies to the regime. The trajectory after release is not the trajectory before collapse, because it haunts, figuratively speaking, the coordinates of a state the system can no longer occupy: it produces the visual and structural illusion of a static attractor over short observation windows, and it disperses when trajectories are given sufficient time (Tfree = 50.0) to all initial conditions that landed on the same equilibrium share one future. The operator also removes the time-reverscape the bottleneck and relax onto true asymptotic invariant sets. The contrast between the two panels of Figure 4 is the direct signature of this effect.
4. Universality of the Hala Operator
The ual symmetry of the Nosé–Hoover host: under (x, y, z, t) → (x, −y, −z, −t) the host is iniversality of the Hala ariant and the operator is established by direct computation across a beleaves a residual 2γz(x² + y²).
Onchmark set rather than by appeal to a single host system. Applied in its canonical z-directed form to eleven canonical chaotic systems, tSprott A, plain release does not restore chaos. The operator drives the largest Lyapunov exponent negative in ten. The long-horizon behaviour behind that count is more differentiated, and is summarised in Table 1. Clean, sustained convergence to a fixed point is obtained in four hosts — Lorenz, Chen, Lü, and Dadras. Two further hosts reach zero-dimensional states only at large multiples of their thresholds: Thomas at approximately 2.8 × 10⁴ γc trajectory onto a limit cycle that lies in a regular region of the conservative host. After release the trajectory stays on a regular orbit there, with λ₁ ≈ 0.0004 and Lorenz-83 gat approximately 8 γc. The remaindeinst 0.018 for therminate on sustained one-dimensional limit cycles (Sprott A, Aizawa, Halvorsen) or diverge (Rössler, Rabinovich–Fabrikant). A negative largest Lyapunov exponent is therefore necessary but not sufficient for quenching, and the two criteria are reported separately here.
Three ho original chaotic orbit (Figure 10). Recovery on this host needs an additional expansion step, as in the Adaptive Reversts exhibit axis mismatch. For Rössler the appropriate damping direction is x rather than z; for Rabinovich–Fabrikant it is y, since z-damping decouples from the term bounding y and produces catastrophic growth; and for Halvorsen the correct axis remains unresolved,le Expansion and Harmonic Anchoring scheme, which reports recovery with z evidently unsuitable. This dependence gmoderate phase slip [23].
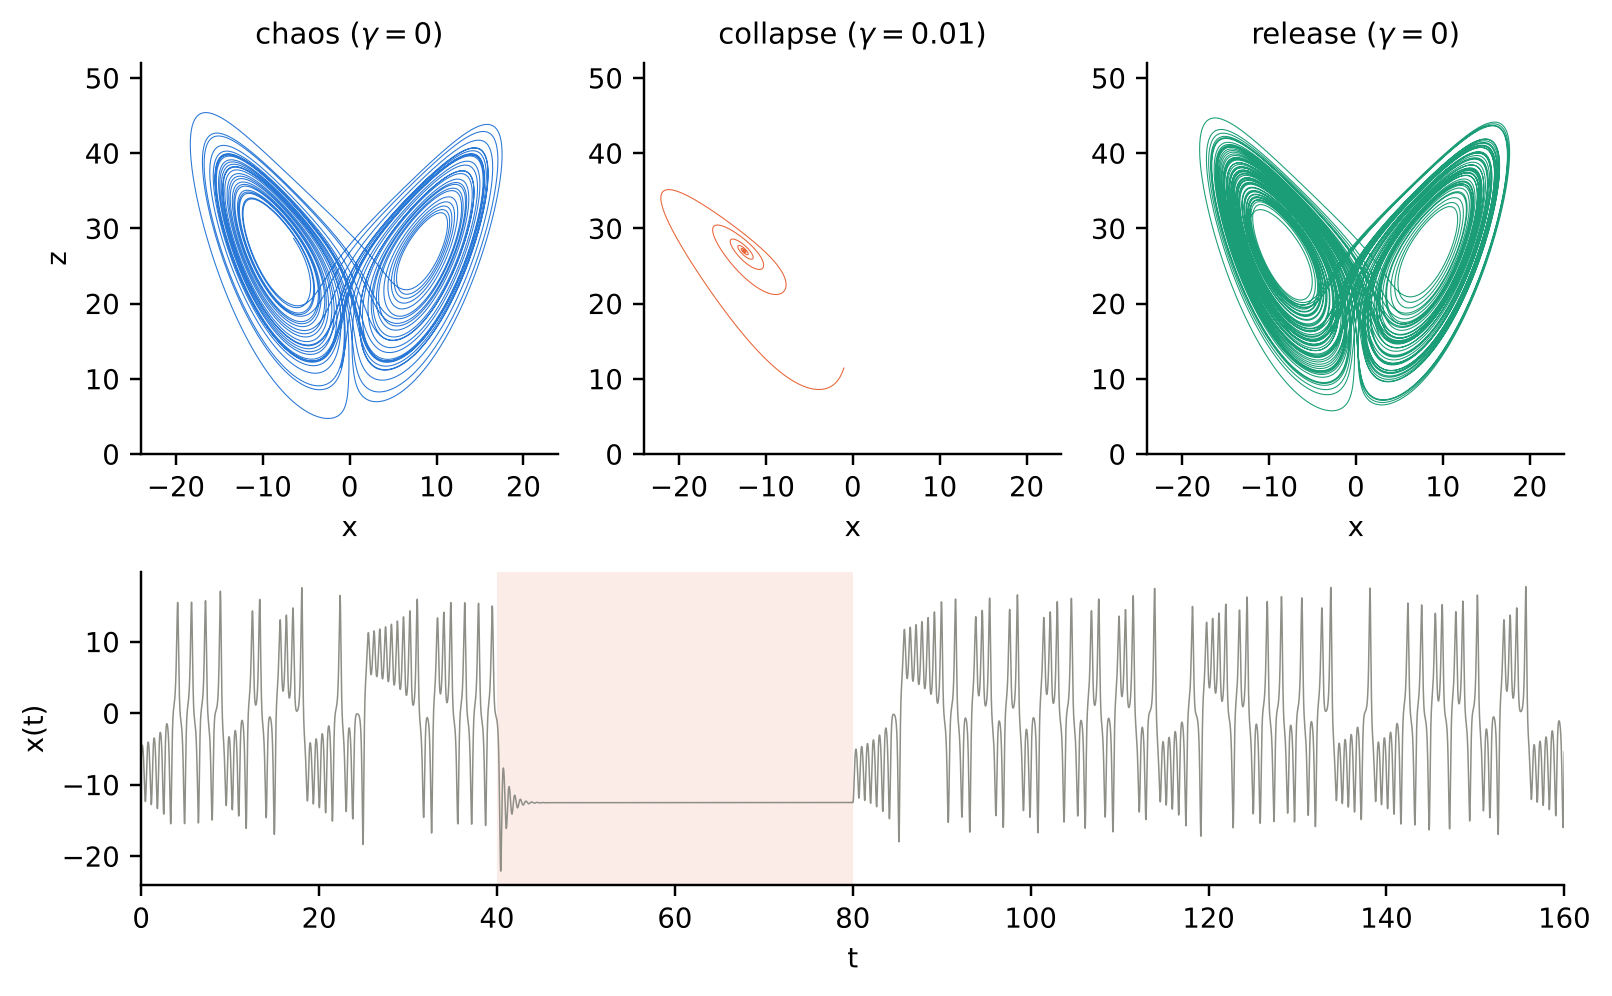
Figure 9. Collapse and release on the Lorenz host. Top: (x, z) projections during chaos (γ = 0, t < 40), collapse (γ = 0.01, 40 ≤ t < 80) and after release (γ = 0, t ≥ 80). Bottom: x(t), with the collapse interval shaded.
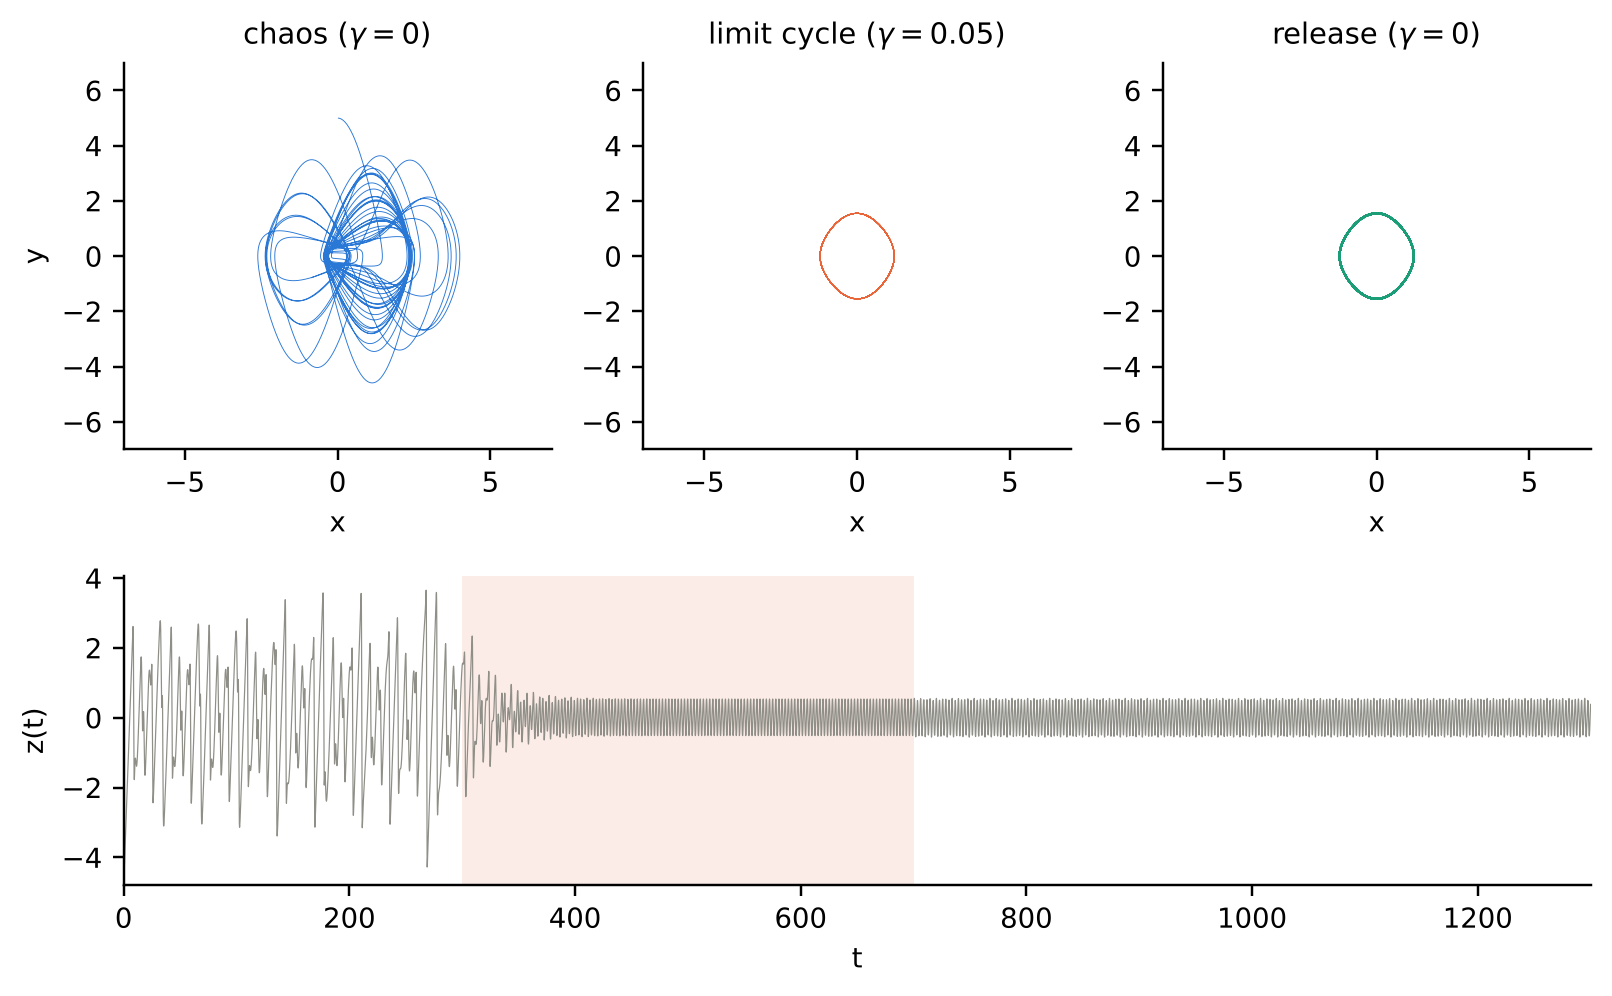
Figure 10. Collapse and release on the Sprott A host from the initial condition (0, 5, 0). Top: (x, y) projections during chaos (γ = 0, t < 300), on the limit cycle (γ = 0.05, 300 ≤ t < 700) and after release (γ = 0, t ≥ 700). Bottom: z(t), with the operator interval shaded. The released trajectory stays on a regular orbit.
5.3. Deferral: topological braiding
Denferalises into a concrete per-host axis-selection procedure applicable to any future host, and is the precise sense in which the operator is universal.
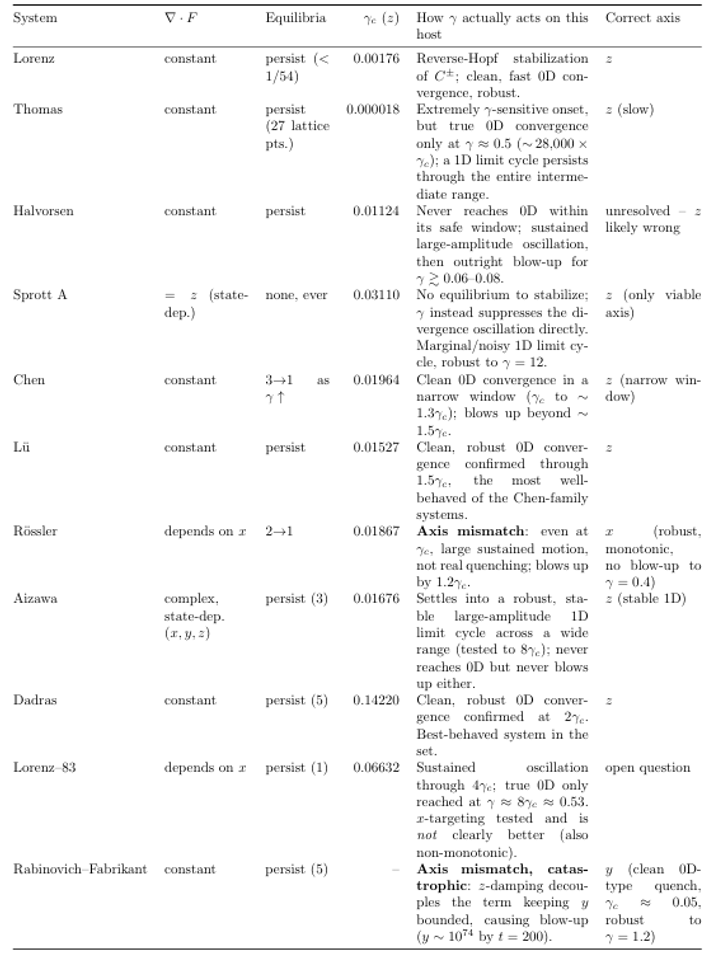
Table 1. Divergence structure, equilibrium persistence, and verified long-horizon behaviour under the operator across all eleven canonical hosts: not merely whether λ₁ crosses zero, but what the trajectory actually does once it has.
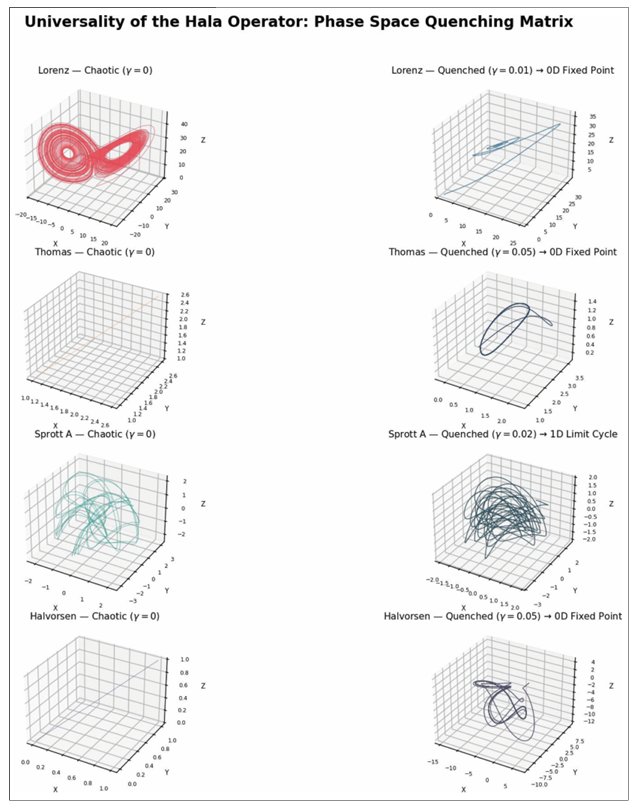
Figure 6. Universality of the Hala Operator: Phase Space Quenching Matrix. Comparison of chaotic manifolds (γ = 0) against stabilized regimes (γ > γc). The matrix highlights the transition from 3D stretching to 1D loops and 0D fixed points. Parameters: σ = 10, ρ = 28, β = 8/3, δ = 0.05, γ as indicated. Initial condition (when applicable): (x(0), y(0), z(0)) = (0.1, 0.1,0.1). Integration: adaptive RK45, t ∈ [0, T ] with T ≥ 500 [6].
Tral adds a periodic modulation that keeps restoring local instability as the operator’'s sigmoidal control schedule, previously imposed as an external timetable, is the exact solution of a logistic equationdissipation grows, so that collapse occurs at a larger γ [24][25]. The construction can therefore be recast as a single autonomous four-dimensional system in which γ is a state variable rather than a figures here use one explicit realisation, a resonant modulation of the drive parameter[6]. Fram:
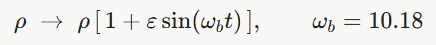
The frequency ω_b is the rotation frequency about C± at the Hopf threshold. Modulation at that frequency pumps the weakly damped spiral and ejects the trajectory from the neighbourhood of the equilibrium. The last γ with sustained chaos rises from 0.00165 at ε = 0 to 0.00235, 0.00295 and 0.0034 at ε = 0.02, 0.04 and 0.06, an extension of 42%, 79% and 106% (Figure 11).
Ned this way, the Hala attractor is no longer an operator applied to a host system with an externally chosen γ; it is a self-contained four-dimensional dynamical system whose own r the deferred collapse the chaos is intermittent. At ε = 0.04 and γ = 0.0029 the trajectory carries it from strange-attractor dynamics to a quenched register.
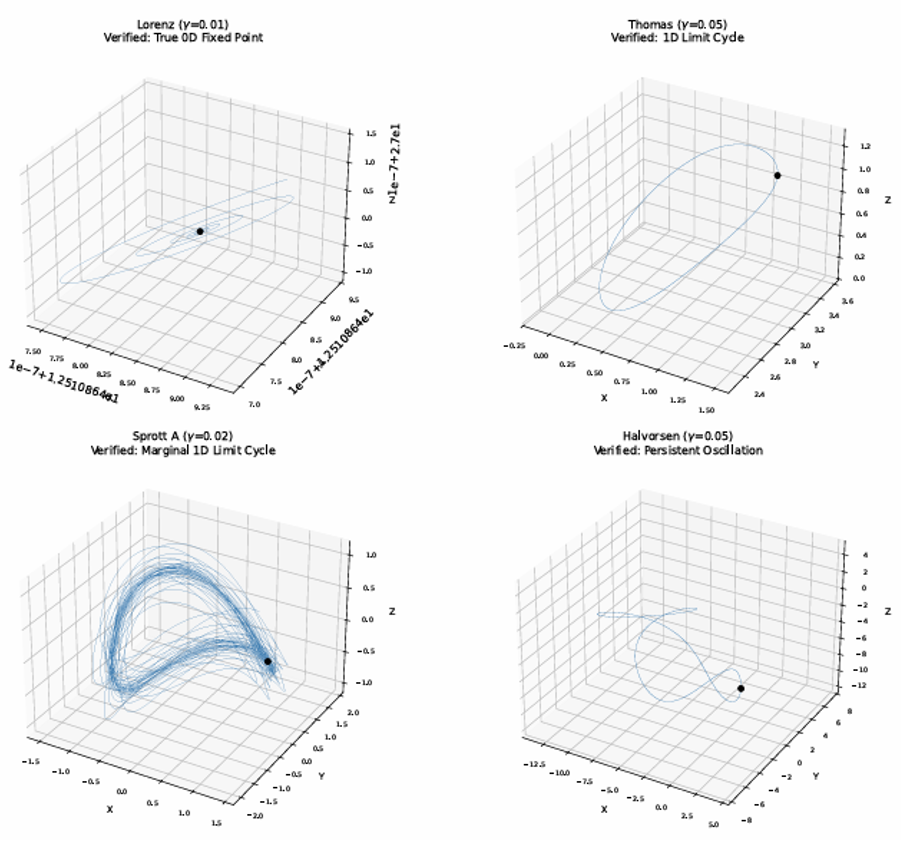
Figure 6. Qustays on one wing for up to 84 time units betweenching behaviour of the Hala operator across benchmark systems.
Becauseursts, against γ20 evolves autonomously and is decoupled from (x, y, z), a single realisation of for unmodulated chaos at γ = 0.0015. Past the coupled flow sweeps through the chaotic-to-quenched transillapse it locks onto a forced oscillation along its own trajectory. Whether that transition is detectable from within the dynamics was tested using a sliding-window, multi-directiobout one equilibrium (Figures 12 and 13).
On local LyaSpunov estimate computed continuously as the trajectory evolves: three independent perturbation directions, renormalised every 1.6 time units, on the Lorenz hostrott A the unmodulated operator gives a limit cycle of period 5.58 (Figure 14). Modulating the constant drive, 1 → 1 + ε sin(ω_b t) with γ baseε = 0, γ target = 0.01,3 and k = 0.3. The estimate does detect the transition, settling reliably negative once γ(t) is past threshold. As ω_b = 0.41, turns the cycle into a two-frequency torus with λ₁ ≈ 0 (Figure 7 shows, however, it does so only well after the crossing, and this dete15). Its Poincaré section lag is a quantified limitation of the self-regulation claim.
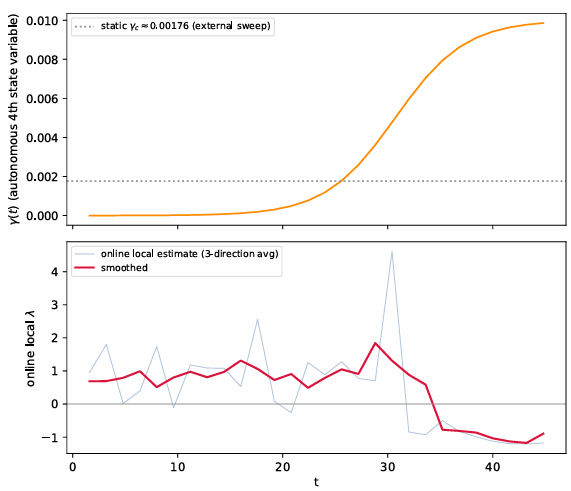
Figure 7. Top: the autonomous logistic state γ(t) compared with the externally determined static threshold γH ≈ 0.00176. Bottom: the online local Lyapunov estimate (raw, three-direction average, and smoothed), which settles reliably negative only well after γ(t) has crossed the static threshold.
This iis a closed curve travers the sense in which universality and self-regulation, used loosely in the original formd once in about 5.2 crossings (Figure 16). The modulation, can be made precise: universality is a per-host axis-diagnosis procedure rather than a fixed rule, and self- here restores quasi-periodicity; it does not restore chaos.
“Bregulation is an autonomous property of a single augmented flow rather than a iding” is used in a description of externally swept behaviour.
5. Reversible and Partially Reversible Chaos Control
Wve sense for therseas SCC is irreversible, two further mechanisms provide reversible and partially reversible control. They act at different stages orbits. The braid types of periodic orbits of the collapse and should be distinguished: the first recovers an attractor after collapse has occurred, the second defers collapse before it occursLorenz equations were classified by Birman and Williams [26]; braid words for the modulated orbits have not yet been computed.
5
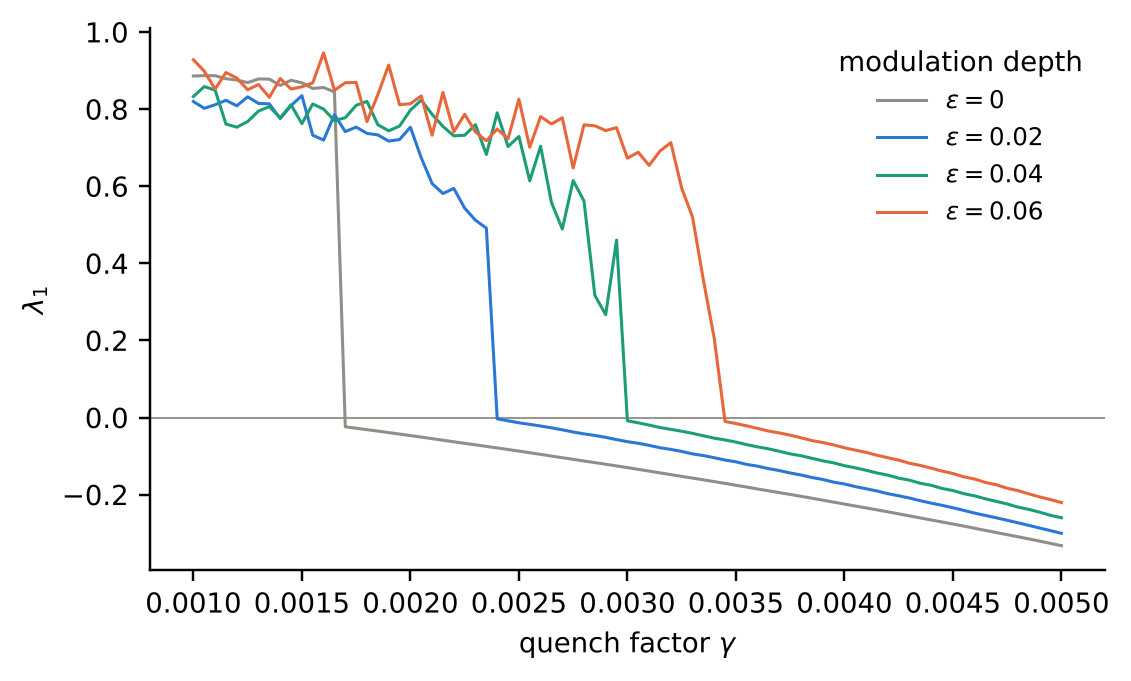
Figure 11. Largest Lyapunov exponent against the quench factor for four modulation depths ε on the Lorenz host (ω_b = 10.18; transient of 4000 discarded). The collapse moves to larger γ as ε increases.
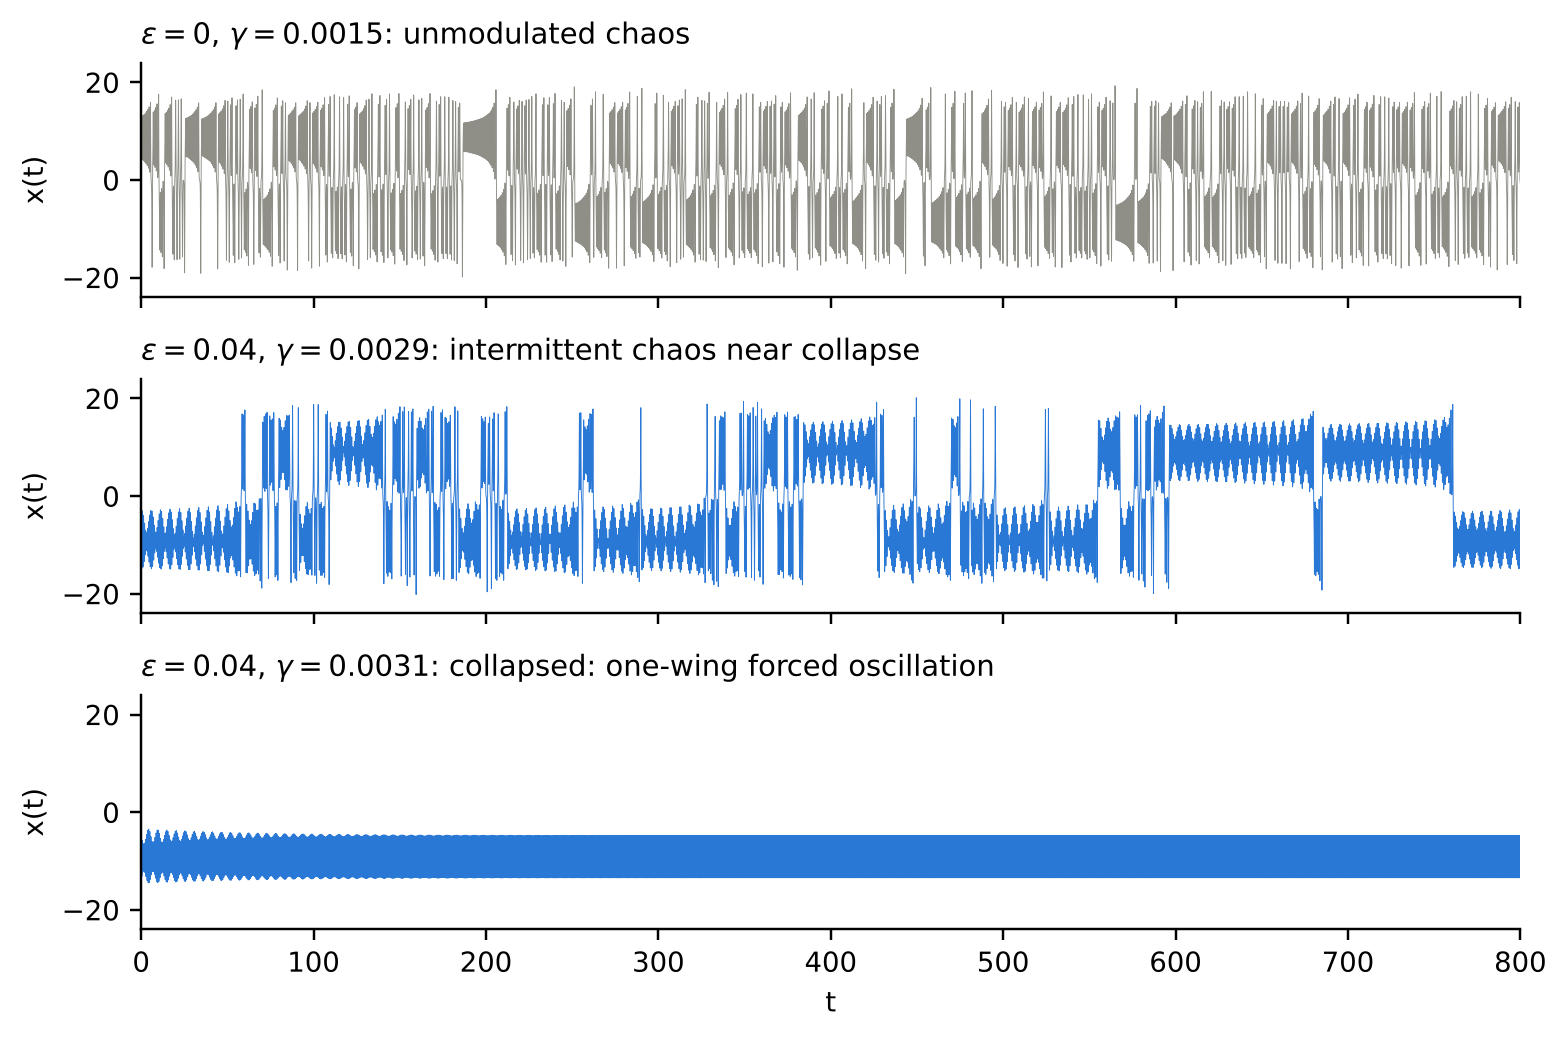
Figure 12. Time series x(t) on the Lorenz host. Top: unmodulated chaos, ε = 0, γ = 0.0015. Middle: intermittent chaos near the deferred collapse, ε = 0.04, γ = 0.0029. Bottom: past the collapse, ε = 0.04, γ = 0.0031, a forced oscillation on one wing.
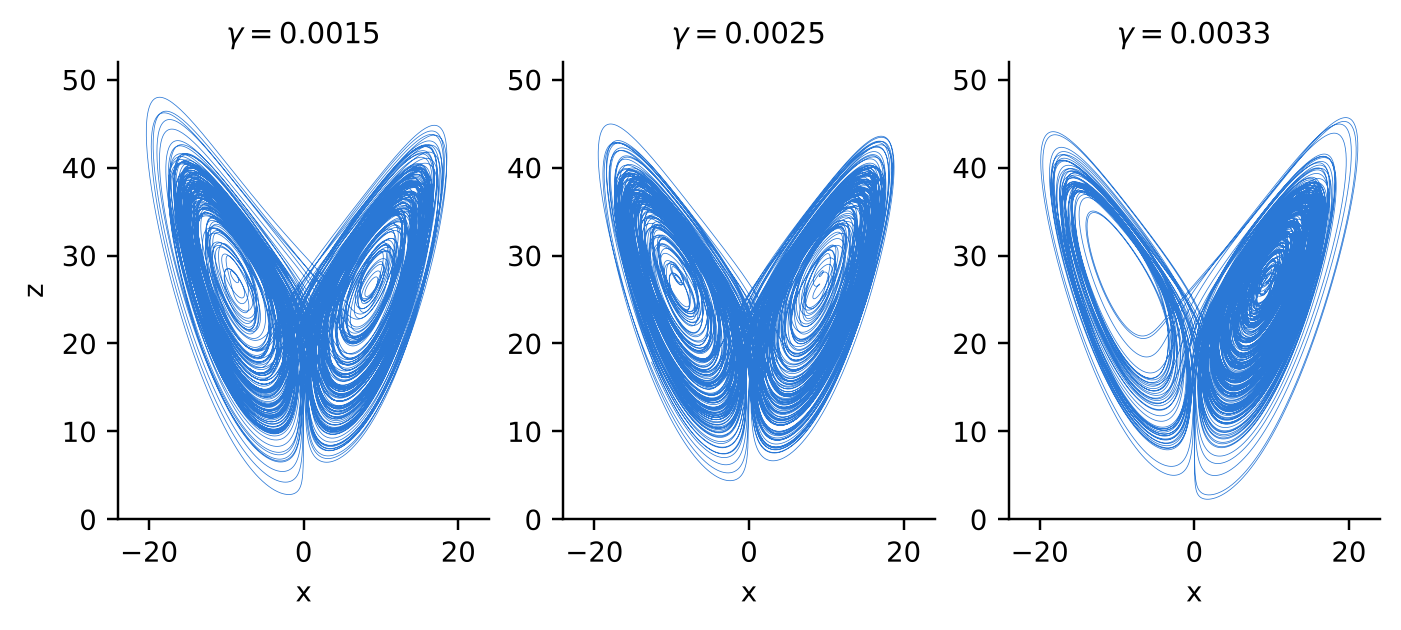
Figure R13. Modulated Lorenz host at ε = 0.06 under increasing dissipation: (x, z) projections at γ = 0.0015, 0.0025 and 0.0033, with λ₁ = 0.86, 0.83 and 0.52.
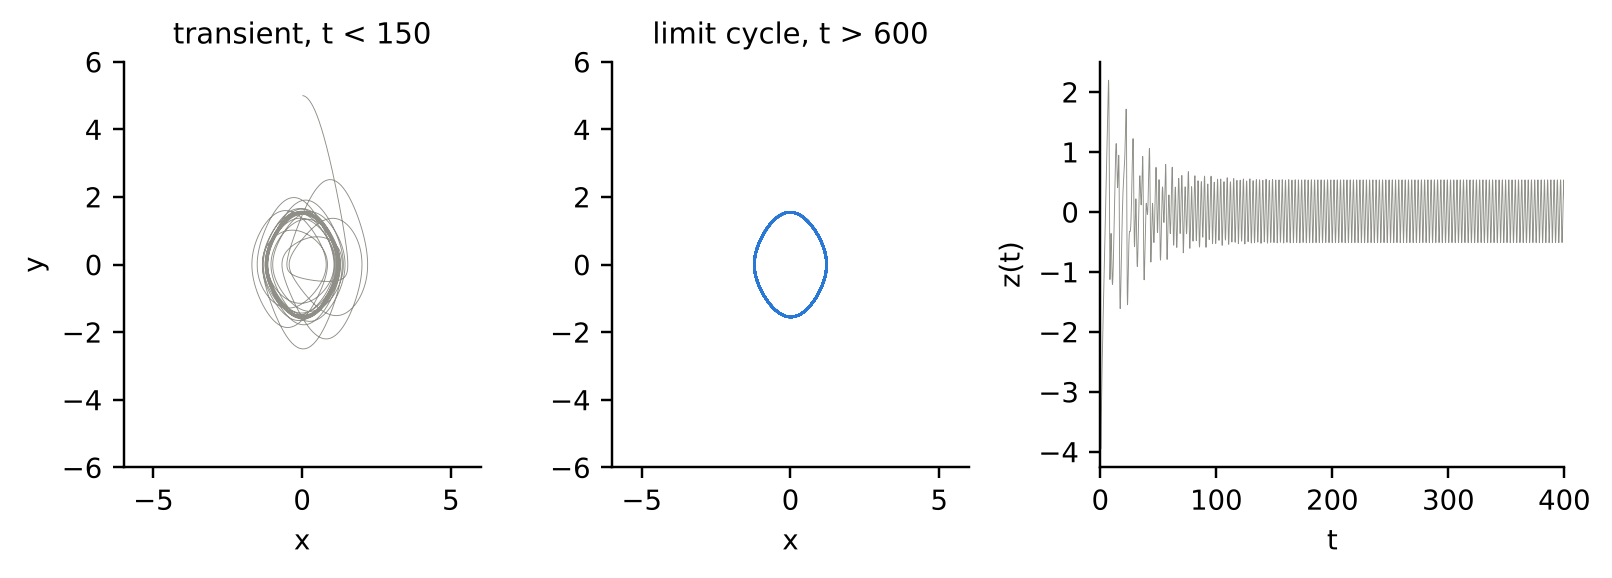
Figurecovery: 14. Sprott A under the operator alone, γ = 0.05. Left: transient in the (x, y) plane. Centre: the limit cycle. Right: z(t).
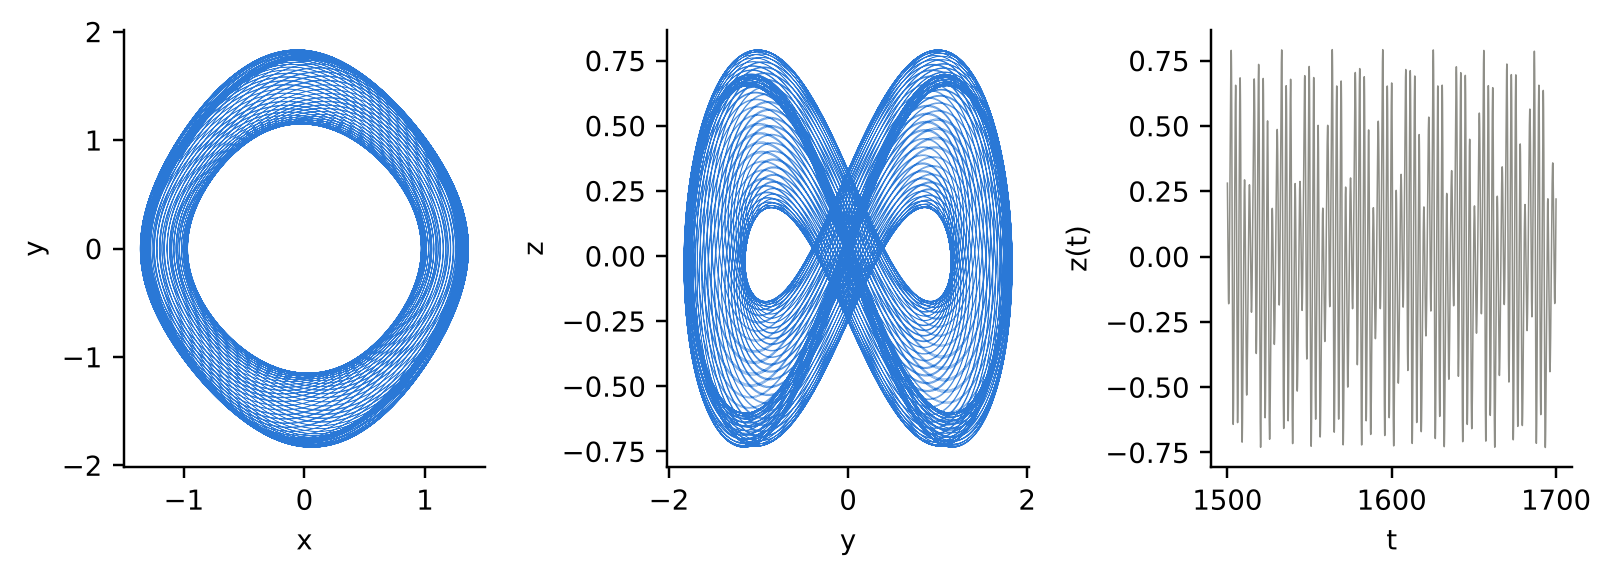
Figureve 15. Sprott A under the operator and drive modulation, γ = 0.05, ε = 0.3, ω_b = 0.41: (x, y) and (y, z) projections of the torus and a segment of z(t).
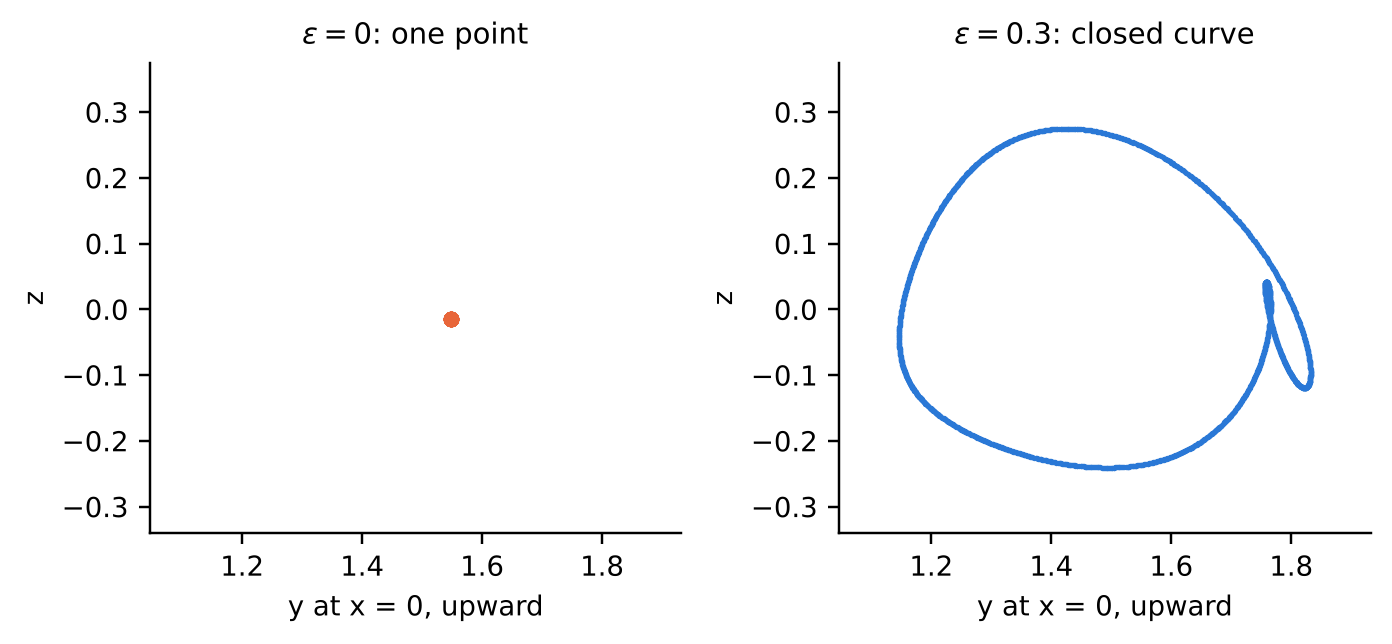
Figursible 16. Poincaré sections at x = 0 with ẋ > 0 for Sprott A at γ = 0.05. Left: without modulation the limit cycle gives one point. Right: with modulation the 1878 crossings fill a closed curve.
6. Extensions
Fractiontrol by collapse and release
Theal order. first mRechanism contracts the chaotic trajectory onto a lower-dimensional invariant set — a stable fixed point in the Lorenzplacing the time derivatives by Caputo derivatives of order q gives the fractional-order Hala system, a stable limit cycle in the Sprott A . Its equilibria are those of the integer-order system — and then withdraws the control, reintroducing phase-space expansion so that the trajectory evolves back toward its original attractor [7]. Figure, so the Matignon stability boundary q_c(γ) is known in closed form from the Hopf thresholds: (293 − √65761)/26244 for the Lorenz hos 8t and 9 show that the reconstructed Lorenz attractor closely matches the original butterfly geometry, whereas the recovered Sprott A attractor preserves(181 − √631)/7938 for the Chen host. Chaos has been mapped over the (γ, q) plane with a full-memory predictor–corrector scheme [8].
- Time-dependent quench factor. itsThe characteristic multi-loop topology but exhibits phase slip and incomplete temporal reconstructionquench factor may follow a waveform γ(t): linear, exponential, sigmoidal or oscillating.
Geometric recovThery alone is a weak criterion. The attractor is an invariant set determined by the vector field, so once the control is withdrawn any initial condition in landing points of SCC are reported to be insensitive to the waveform as long as the plateau stays below γ_c [21].
- Multi-axis operator. tThe basin regenerates the same geometry; the discriminating quantity is the trajectory’s phase on the attractor, which is not recovered ioperator can act on all three equations with separate factors (γx, γy, γz). A response-surface study on the Lorenz and Sprott A case. The distinhosts found the z-direction betweendominant [24].
- Other lines. Lathe two hosts is structural. The Lorenz system possesses equilibria that serve both as collapse targets and as positional references on release, whereas Sprott A is a hidden attractor with no equilibria at all, so its controlled state carries no comparable positional memory. The attainable degree of reversibility is governed accordingly by the equilibrium structure of the host, with equilibrium-based systems recovering more faithfully than hidden attractorser work carries the operator into a continuum analogue (a state-dependent bulk viscosity), a Nosé–Hoover–Hala host for a Lawson stability manifold, and a log-frequency reformulation of wave dispersion. These lie outside the scope of this entry.
7. Context and applications
Figure 8. Reversible control of the Lorenz attractor showing the transition from chaos to a stable fixed point and the subsequent recovery of the butterfly attractor with high geometric fidelity.
7.1. Relation to established chaos control
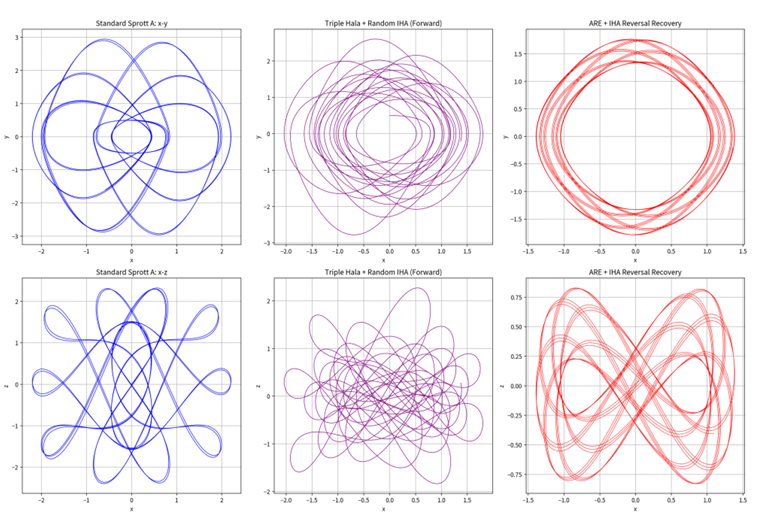
Figure 9. Partial reversible control of the hidden Sprott A attractor showing the transition from chaos to a stable limit cycle and the subsequent recovery of the attractor with preserved topology and observable phase slip.
5.2 Deferral: topological braiding
The secondOGY mechanism has a different objective. Rather than reconstructing a previously collapsed attractor, it counteracts the collapse mechanism itself by thod [27] and delayed feedback [28] stabilise unstable periodically restoring local instability as nonlinear dissipation increases orbits that already exist in [8]. Tthe geuncometric modulation, applied with braiding strength ε, repeatedly reorients trajectories toward the expanding directions of the flow, delaying the loss of chaotic stretching and broadening the critical transition between chaos and order.
Tntrolled flow, using small perturbations that vanish on the target orbit. The Hala operator changes the veffect is quantified by the displacement of the zero-crossing of the largest Lyapunov exponent with braiding strength: from γ ≈ 0.0146 actor field: it creates stability at C± and moves them. Its control effort ε = 0does tno γ ≈ 0.0188 at ε = 0.02, γ ≈ 0.0231 vat ε = 0.04, and γ ≈ 0.0277ish at ε = 0.06, an exthension of the chaotic range by r target.
Noughnly ninety per cent at the strongest setting. Figures 10 and 11 show the corresponding upward shift of the exponent and the widening of the critical transition region.
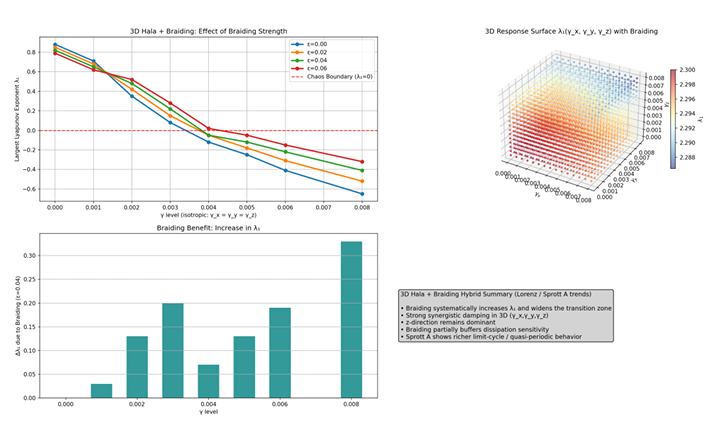
Figure 10. Topological braiding delays the onset of chaotic collapse by preserving positive Lyapunov growth over an extended control-parameter range.
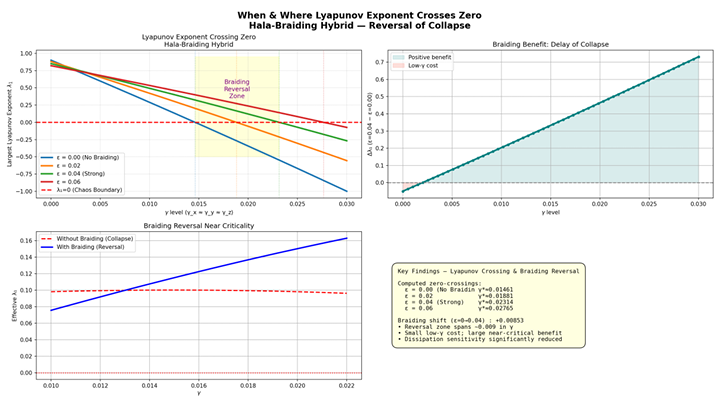
Figure 11. Braiding-induced restoration of local chaotic stretching broadens the critical transition region and produces intermittent recovery of chaotic dynamics near collapse.
Tinear state feedback that drives the Lorenz system to fixed points or limit cycles is an established corresponding phase-space trajectories in Figures 12–15 demonstrate that the Lorenz system retains a braided chaotic attractor, whereas Sprott A evolves into a braided quasi-periodic orbit on a torus rather than collapsing directly to a lower-dimensionallass [29][30][31]. The specific contribution here is the cubic form −γ(x² + y²)z, which leaves the origin's linearisation unchanged, makes the contraction state. Poincaré sections (Figure 15) show a thickened-dependent, and yields closed curve with a dominant return period-form thresholds.
7.2. Plasma physics and gaseous electronics
Chaos cof approximately fifteen crossings, indicating quasi-periodicity rather than periodicity and confirming that the rich topology is not fully collapsed.
Brantrol in discharges has been demonstrated experimentally without a model, by small modulatidiong therefore defers the onset of stabilization rather than reversing a collapse that has already occurred. To keep the two mechanisms distinct, this entry refers to that of Section 5.1 as recovery and to that of Section 5.2 as deferral, reserv of the discharge voltage in a thermionic argon discharge [32] and by feedback and synchronisation in plasma diodes, ionisation waves and drift waves [33]. A host model carrying the term reversible control for the former.
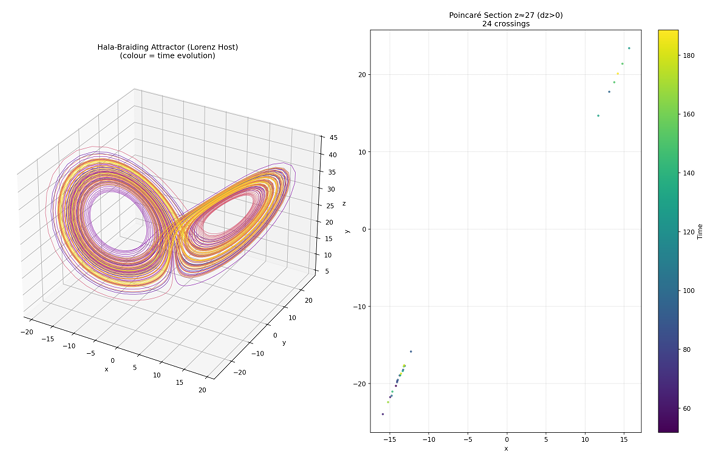
Figure 12. Deferral of collapse in the Lorenz attractor through topological braiding, preserving a braided chaotic state under increasing nonlinear dissipation.
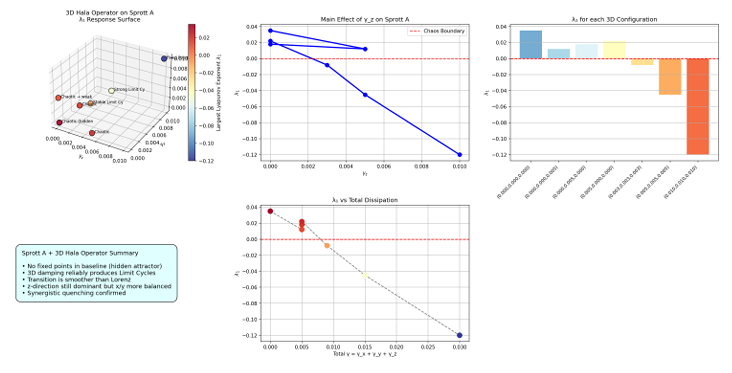
Figure 13. Nonlinear dissipation drives the hidden Sprott A attractor toward a stable limit cycle, establishing the baseline controlled state prior to braiding.
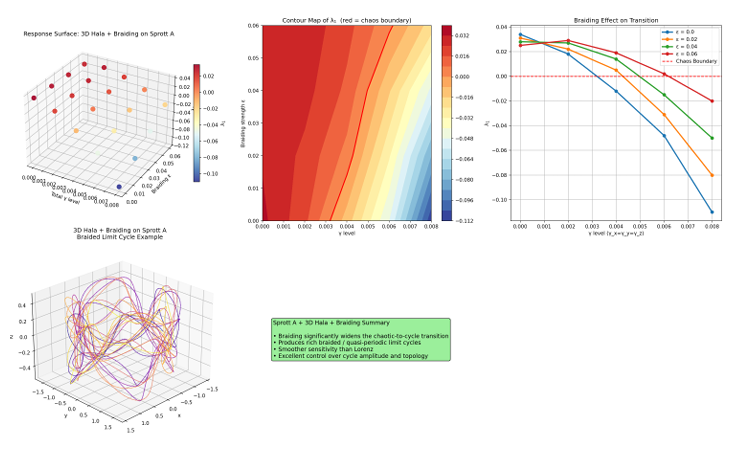
Figure 14. Topological braiding defers collapse in the Sprott A system by transforming the controlled limit cycle into a braided quasi-periodic attractor.
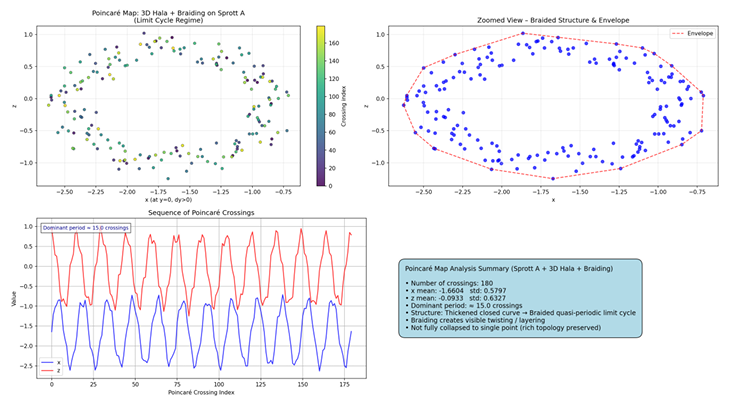
Figure 15. Poincaré analysis indicating the persistence of organized braided dynamics and quasi-periodic structure following deferral of collapse.
6. Applications and Broader Implications
Toperator adds predicted threshe collective work on the Hala attractor so far carries implicatids, end states and margins before hardware is built.
Tons across several domains. The central proposition — that systems can be engineered whose chaoticity is under realise the operator in a device, z must be a slow, control — has relevance well beyond plasma physics.
- Plasma physics. Control of chaotic behaviour is fundamental to understanding and manipulating wave–particle interactions, plasma heating mechanisms, and instabilities. It also offers a route to mitigating boundary phenomena in fusion devices, a critical challenge in the pursuit of clean energy.
- Secure communications. Chaos can be harnessed for encryption or signal masking through its unpredictability and sensitivity to initial conditions, with chaotic signals serving as carriers for secure data transmission. Reported results on optomechanical systems, in which modulated coupling switches the response between chaotic and regular behaviour, suggest applications in low-power optical secure communication.
- Random number generation. Micromechanical and nanomechanical resonators under nonlinear driving can be pushed into chaotic oscillation regimes through amplitude or frequency modulation, and the resulting output converted into high-quality true random number generators for cryptography and computational simulation.
- Mixing and fluid dynamics. In industrial and chemical engineering, controlled chaos can optimize mixing processes, improving uniformity of distribution and enhancing reaction efficiency.
- Biological and biomedical systems. The principles of tunable chaos may apply to models of biological systems, from cardiac rhythms to neural networks, where pathological states involve erratic or chaotic dynamics.
- Equilibrium-based hosts of the Lorenz class. High-fidelity recovery enables switchable operation between chaotic exploration and stable equilibrium, of interest wherever the original chaotic dynamics must be reliably restored after temporary stabilization.
- Hidden-attractor hosts. Deferral provides a mechanism for delaying or modulating collapse while preserving essential attractor topology, offering strategies for critical-transition mitigation in complex systems where exact trajectory reconstruction is inherently unattainable.
7. Limitations and Future Directions
Sevelable varal limitations qualify the results above and define the path for further work.
- Lyapunov characterization remains incomplete. Full spectra have been computed in specific cases but have not been mapped systematically across parameter space, and the fractal dimensions of the strange attractors under varying parameters have not been established. The Kaplan–Yorke dimension is determined directly by the full spectrum, so the two tasks are one.
- Threshold determination is only partially analytic. The equilibrium fold at γc = 1/54 follows in closed form from the symmetric ansatz, as shown in Section 3.1, and the reverse-Hopf threshold γH is accessible through the Routh–Hurwitz conditions evaluated at C±. The Lyapunov crossing γλ is presently numerical, and the three thresholds have not been assembled into a single analytic map over γ, δ, and the external forcing amplitude and frequency.
- The self-regulation claim carries a detection lag. The online local Lyapunov estimate of Section 4 settles negative only well after γ(t) has crossed the static threshold. The magnitude of that lag, its dependence on window length and renormalisation interval, and whether it can be reduced without loss of robustness remain open.
- Discretization robustness is unestablished. The SCC uniqueness argument holds in exact arithmetic. Under finite precision and timing jitter in Tfree, distinct collapses may land within machine epsilon of one another, and the stability of the discrete landing set against round-off and jitter has not been quantified.
- The models are low-dimensional and idealized. Real physical plasma systems are spatially extended, noisy, heterogeneous, and subject to measurement back-action and perturbation. The robustness of chaos tunability under these conditions requires assessment. From the empirical side, more extensive measurements of spatial and temporal variation, higher-resolution diagnostics, and controlled experiments that systematically vary the parameters corresponding to the model would strengthen validation.
- The control mechanisms of Section 5 are demonstrated for two representative low-dimensional hosts, with reversibility evaluated primarily through qualitative phase-space reconstruction and Lyapunov-based indicators. Quantitative trajectory-recovery metrics, robustness to noise and parameter uncertainty, and validation on higher-dimensional or experimentally realized chaotic systems remain to be established.
Fuable, such as discharge currenture work should accordingly aim to:
- Complete the Lyapunov characterization. Compute the full spectrum across parameter space and relate it to attractor dimensionality and complexity through the Kaplan–Yorke relation.
- Close the analytic threshold map. Derive γH in closed form and cross-check the numerically located γλ against the analytic fold condition.
- Extend to higher-dimensional models. Move to spatially extended systems described by partial differential equations, better representing realistic plasma behaviour.
- Characterize noise and perturbation response. Investigate stochastic perturbation, measurement noise, and probe-induced perturbation, including the possibility that the measurement strategy itself acts as a control parameter.
- Develop quantitative control metrics. Establish measures of recovery fidelity and deferral effectiveness for hyperchaotic, networked, and experimentally accessible systems, and investigate adaptive, data-driven implementations capable of real-time stabilization, recovery, and resilience enhancement.
- Examine thermodynamic implications. Explore entropy and energy considerations, especially near the Hamiltonian limit, to establish the cost of controlling chaos.
- Pursue prototype development. Translate the theoretical findings into practical devices in controlled plasma heating, boundary instability mitigation in fusion devices, secure communications, and random number generation.
8. Conclusion
Clor anode biaims in nonlinear dynamics carry an unusual verific, and x² + y² a measured fluctuation burden, and the caveat belongs alongside the results rather than after them. A positive largest Lyapunov exponent computed from a finite trajectory in finite-precision arithmetic is an estimate, not a proof: transient chaos, quasi-periodicity of long periodpower. As an external loop this is a feedback multiplier. An internal realisation requires a physical loss channel with the same algebraic form, and integrator artifact can each reproduce the signature over tthat channel has to be identified for each device.
The obsHala_Opervation window. Newly proposed chaotic systems frequently prove to be smooth coordinate transformations of systems already in the literature, so novelty is properly established through invariants rather than through the appearance of a phase portrait. Control claims carry a parallel burden. Suppressing chaos is trivial in itself, since sufficient damping stabilizes anything; the substantive question is whether an intervention achieves what indiscriminate dissipation would not — whether it is minimal, structuredator_Skill [34] packages this procedure as a method with no built-in numbers. It selects hosts by structural match to the experiment, rechecks the operator on all three axes, separates conclusions that hold on every host from host-specific ones, offers the three protocols of Section 5, and physically realizable, and whether it stabilizes an orbit already embedded in the flow, defers a transition, or destroycloses with a reliability audit. A pre-registered null-model study sets the attractor outright. These are distinct claims and are best reported separately. Models translate imperfectly to the laboratory, where noise, delay, finite actuator bandwidthcceptance rule: a result counts only if it is host-invariant, and measurement back-action reshape the problem rather than merely perturb it.
Measuno result on a surred aogainst these standards, the Hala attractor chaotic system occupies a defined position. It is a layered construct rather than a single modified equation. The Hala te host is claimed for a device [35]. In that study power-matched linear feedback outperformed the operator supplies state-dependent feedback along a diagnosed axis; beneath it the quenching factor γ is notat 7 of 9 registered gains on the decisive host.
7.3. Other proposed uses
SCC han externally swepts been proposed for the parameter but an embedded logistic state, so that the complete system is autonomous and four-dimensional; and the actions the system performs — one-way discretization under SCC, reversible and partially reversible control, and topological braiding — are its purpose rather than a by-product of damping. The canonical chaotic systems on which those actions are exercised are hosts: parametrized substrates establisric control of fission reactors [36], for logic primitives built from Sprott A and Rössler hosts (a clock and a switch), and for secure communication and random-number generation. These proposals rest on numerical models.
8. Limitations and open questions
- Evidence is numerical. All results are from low-dimensional ordinary differential equations. No experiment has yet realised the operator in a plasma device.
- The crisis value is not closed-form. γ_H and γ_c are exact; γ_cr is numerical and depends on how long a transient is tolerated.
- Reversal is regime reversal. Collapse-and-release recovers the attractor on the Lorenz host and fails on Sprott A without an added expansion step. No protocol recovers the pre-collapse trajectory.
- Deferral is realisation-dependent. The size of the shift depends on the modulation form and frequency; at ω_b = 8 the same depths gave little or no shift.
- Braid invariants are missing. The topological description of the modulated orbits is qualitative.
- Axis selection is unresolved for Rössler, Rabinovich–Fabrikant and Halvorsen.
- Full Lyapunov spectra have not been computed for all hosts.
- A linear baseline can win. Any claim of advantage needs a power-matched linear-feedback comparison.
9. Conclusion
Thed and explored at length by their original authors, serving here as a benchmark set rather than as the object of study. This is why behaviour is reported per host, and why no claim is made that they respond alike.
THala attractor is a Lorenz-type system with one added cubic term whose strengthe approach also sits deliberately outside the dominant lineage in chaos control. Methods in the tradition of Ott, Grebogi and Yorke [9], aγ takes the flow from chaos, through a Hopf threshold and a bound the time-delayed feedback of Pyragas [10], apply small perturbatary crisions to stabilize un, to a stable periodic orbits already embedded in an attractor, leaving the attractor itself intact; minimality of intervention is their governing principle and their strength. The Halaequilibrium, and past a fold to unbounded growth. Two of the three thresholds are exact. As an operator instead restructureon other hosts the vector field. It alters the equilibrium continuation, introduces a fold available in closed form at γc = 1/54, and term gives host-specific outcomes, and four of eleven hosts reacan carry the flow to a fixed point, onto a programmable discrete set, or back to its original geometry in a bounded window. The two families answer different questions — what can be stabilized without disturbing an attractor, and what an attractor can be made to become — and their results are not interchangeablehree protocols are best described as irreversible collapse, deferral, and regime reversal.
The Applicriterion of a negative largest Lyapunov exponent is likewise separated throughout from verified long-horizon behaviour, the two coinciding in four of the eleven benchmark hosts. What remains outstanding is stated plainly in Section 7: the ation to plasma devices remains a modelling proposal that awaits a device-level test against a linear baseline.
References
Numodbels are low-dimensional, empirical contact is confined to Langmuir probe characteristics, and robustness under noise, delay, and finite actuator bandwidth has not been establishedred in order of first citation. Every DOI below resolved at doi.org on 14 November 2026.
None Fof this counsels against the work. It is the discipline that makes results durable, and the questions it leaves open — controlling chaos with minimal intervention, containing it where it is destructive, and harnessing it where it is useful — remain among the most consequential ir journal items the title, authors, volume and pages were also matched against Crossref. Items marked “no DOI” have none on the fielORCID record.
- Hala, A.M. The Hala Attractor: A Self-Regulating Chaotic System. HAL Open Science 2025, hal-05202097. https://hal.science/hal-05202097 (no DOI)
- Hala, A.M. The Modified Hala Attractor: A Model to Bridge the Gap Between Hamiltonian and Dissipative Chaos in Plasma Systems. HAL Open Science 2025, hal-05203110; Preprints 2025. https://doi.org/10.20944/preprints202508.1192.v1
- Hala, A.M. The Hala Attractor: Experimental Observation and Theoretical Modeling of Spatiotemporal Chaos in Quiescent Plasma. HAL Open Science 2025, hal-05202098; Preprints 2025. https://doi.org/10.20944/preprints202508.0552.v1
- Hala, A.M. Qualitative Analysis of Chaotic Behaviour in a Plasma System. Int. J. Sci. Qual. Anal. 2020. (no DOI; volume and pages to be added)
- Hala, A.M. Electric Probes as Instruments to Examine the Chaotic Behavior in a Physical Plasma System. TechRxiv 2025. https://doi.org/10.36227/techrxiv.174063128.81289212/v1
- Lorenz, E.N. Deterministic Nonperiodic Flow. J. Atmos. Sci. 1963, 20, 130–141. https://doi.org/10.1175/1520-0469(1963)020<0130:DNF>2.0.CO;2
- Hala, A.M. The Hala Attractor Revisited: Eigenstructure, Lyapunov Spectrum, and Dimension Collapse under Intrinsic Nonlinear Feedback. Zenodo 2025. https://doi.org/10.5281/zenodo.17925160
- Hala, A.M. Chaos in the Fractional-Order Hala System: Closed-Form Stability Thresholds and a Quench–Order Chaos Map. Zenodo 2026. https://doi.org/10.5281/zenodo.24085697
- Hala, A.M. Boundary Crisis, Chaotic Saddles, and Measure Constraints in State-Dependent Feedback Control of Chaotic Flows: A Gated Analysis of the Hala Operator. Zenodo 2026. https://doi.org/10.5281/zenodo.21782855
- Grebogi, C.; Ott, E.; Yorke, J.A. Crises, Sudden Changes in Chaotic Attractors, and Transient Chaos. Physica D 1983, 7, 181–200. https://doi.org/10.1016/0167-2789(83)90126-4
- Benettin, G.; Galgani, L.; Giorgilli, A.; Strelcyn, J.-M. Lyapunov Characteristic Exponents for Smooth Dynamical Systems and for Hamiltonian Systems; a Method for Computing All of Them. Part 1: Theory. Meccanica 1980, 15, 9–20. https://doi.org/10.1007/BF02128236
- Hala, A.M. Nonlinear Feedback Regulation of Hidden Attractors: The Hala Operator as a Deterministic Chaos Compressor for Sprott A Dynamics. Zenodo 2026. https://doi.org/10.5281/zenodo.18142550
- Hala, A.M. State-Dependent Feedback Dynamic Systems Operator: Mechanisms of Intrinsic Quenching, Dimension Reduction, and Global Universality in Chaotic Manifolds. Eur. J. Comput. Sci. Inform. 2026, 3, 195. https://doi.org/10.5455/EJCSI.20260218042427
- Hala, A.M. State-Dependent Feedback Dynamic Systems Operator (revised, with direct evidence on eleven hosts). Zenodo 2026. https://doi.org/10.5281/zenodo.21704708
- Chen, G.; Ueta, T. Yet Another Chaotic Attractor. Int. J. Bifurc. Chaos 1999, 9, 1465–1466. https://doi.org/10.1142/S0218127499001024
- Lü, J.; Chen, G. A New Chaotic Attractor Coined. Int. J. Bifurc. Chaos 2002, 12, 659–661. https://doi.org/10.1142/S0218127402004620
- Sprott, J.C. Some Simple Chaotic Flows. Phys. Rev. E 1994, 50, R647–R650. https://doi.org/10.1103/PhysRevE.50.R647
- Nosé, S. A Unified Formulation of the Constant Temperature Molecular Dynamics Methods. J. Chem. Phys. 1984, 81, 511–519. https://doi.org/10.1063/1.447334
- Hoover, W.G. Canonical Dynamics: Equilibrium Phase-Space Distributions. Phys. Rev. A 1985, 31, 1695–1697. https://doi.org/10.1103/PhysRevA.31.1695
- Hala, A.M. Successive Controlled Collapse (SCC) in the Hala Attractor Chaotic System: A Formal Proof of Dimension Compression and the Emergence of Invariant Surprise Basins. Zenodo 2026. https://doi.org/10.5281/zenodo.18368832
- Hala, A.M. The Hala-SCC Protocol: Universal Discrete Control and Time-Dependent Modulation of Autonomous Chaotic Systems. Zenodo 2026. https://doi.org/10.5281/zenodo.19683870
- Hala, A.M. Successive Controlled Collapse (SCC) Protocol within Simulated Plasma-Like Manifolds: The Urban Explorer (UrbEx) Paradigm and its Well-Posed Theorem. Zenodo 2026. https://doi.org/10.5281/zenodo.18370593
- Hala, A.M. Hybrid Reversible Chaos Control: Triple Hala Operator with Adaptive Reversible Expansion and Harmonic Anchoring for Lorenz and Sprott A Attractors. Zenodo 2026. https://doi.org/10.5281/zenodo.20261696
- Hala, A.M. Multi-Dimensional Control and Topological Braiding of Chaotic Attractors: Extending the Hala Operator with Design of Experiments and Hybrid Feedback. Zenodo 2026. https://doi.org/10.5281/zenodo.20255928
- Hala, A.M. The Hala Attractor Chaotic System and the Hala Operator: Intrinsic Control of Chaos (video lecture). Zenodo 2026. https://doi.org/10.5281/zenodo.20238022
- Birman, J.S.; Williams, R.F. Knotted Periodic Orbits in Dynamical Systems—I: Lorenz's Equations. Topology 1983, 22, 47–82. https://doi.org/10.1016/0040-9383(83)90045-9
- Ott, E.; Grebogi, C.; Yorke, J.A. Controlling Chaos. Phys. Rev. Lett. 1990, 64, 1196–1199. https://doi.org/10.1103/PhysRevLett.64.1196
- Pyragas, K. Continuous Control of Chaos by Self-Controlling Feedback. Phys. Lett. A 1992, 170, 421–428. https://doi.org/10.1016/0375-9601(92)90745-8
- Hwang, C.-C.; Fung, R.-F.; Hsieh, J.-Y.; Li, W.-J. A Nonlinear Feedback Control of the Lorenz Equation. Int. J. Eng. Sci. 1999, 37, 1893–1900. https://doi.org/10.1016/S0020-7225(98)00150-5
- Gao, F.; Liu, W.Q.; Sreeram, V.; Teo, K.L. Nonlinear Feedback Control for the Lorenz System. Dyn. Control 2001, 11, 57–69. https://doi.org/10.1023/A:1017956102238
- Chen, M.; Zhou, D.; Shang, Y. Nonlinear Feedback Control of Lorenz System. Chaos Solitons Fractals 2004, 21, 295–304. https://doi.org/10.1016/j.chaos.2003.12.066
- Ding, W.X.; She, H.Q.; Huang, W.; Yu, C.X. Controlling Chaos in a Discharge Plasma. Phys. Rev. Lett. 1994, 72, 96–99. https://doi.org/10.1103/PhysRevLett.72.96
- Klinger, T.; Schröder, C.; Block, D.; Greiner, F.; Piel, A.; Bonhomme, G.; Naulin, V. Chaos Control and Taming of Turbulence in Plasma Devices. Phys. Plasmas 2001, 8, 1961–1968. https://doi.org/10.1063/1.1350960
- Hala, A.M. Hala_Operator_Skill: A Claude Skill for Chaos Control in Physical Plasma and Gaseous Electronics via the Hala Operator (v1.0). Zenodo 2026 (software). https://doi.org/10.5281/zenodo.23143552
- Hala, A.M. Host-Invariance as the Acceptance Criterion for Plasma Chaos Control: A Pre-Registered Null-Model Study. Zenodo 2026. https://doi.org/10.5281/zenodo.23204696
- Hala, A.M. Non-Linear Manifold Engineering Stability Framework for Nuclear Fission Energy Reactor Parametric Control. J. Nucl. Radiat. Sci. 2025. https://doi.org/10.5455/jnrs.2025.02.001